KeylessUniversal
--[[
	WARNING: Heads up! This script has not been verified by ScriptBlox. Use at your own risk!
]]
local Library = loadstring(game:HttpGet("https://raw.githubusercontent.com/WarpProjectByMe/Abuzet/refs/heads/main/NEVERMISS"))()
local ZixyESP = loadstring(game:HttpGet('https://raw.githubusercontent.com/zixypy/zixyx/refs/heads/main/zixyesp.txt'))()
local esp = ZixyESP.new()

local UI = Library.new()
UI:load()

local plrs = game:GetService("Players")
local lp = plrs.LocalPlayer
local rs = game:GetService("RunService")
local uis = game:GetService("UserInputService")
local cam = workspace.CurrentCamera

-- Aimbot settings
local aimbotEnabled = false
local fovSize = 200
local fovColor = Color3.fromRGB(208, 240, 253)
local aimbotTeamCheck = true
local wallCheck = true
local usePrediction = true
local predictionValue = 0

-- Drawing for FOV circle
local fovCircle = Drawing.new("Circle")
fovCircle.Visible = false
fovCircle.Thickness = 1
fovCircle.NumSides = 100
fovCircle.Radius = fovSize
fovCircle.Color = fovColor
fovCircle.Filled = false

-- Function to get screen position
local function getScreenPos(part)
    local vector, onScreen = cam:WorldToViewportPoint(part.Position)
    return Vector2.new(vector.X, vector.Y), onScreen
end

-- Function to check if player is valid
local function isValidTarget(plr)
    if plr == lp or not plr.Character or not plr.Character:FindFirstChild("Humanoid") or plr.Character.Humanoid.Health <= 0 then
        return false
    end
    if aimbotTeamCheck and plr.Team == lp.Team then
        return false
    end
    if wallCheck then
        local ray = Ray.new(cam.CFrame.Position, (plr.Character.Head.Position - cam.CFrame.Position).Unit * 500)
        local hit, pos = workspace:FindPartOnRayWithIgnoreList(ray, {lp.Character})
        if hit and hit:IsDescendantOf(plr.Character) then
            return true
        end
        return false
    end
    return true
end

-- Function to find closest player in FOV
local function findClosestInFOV()
    local closest = nil
    local minDist = fovSize
    local fovPos
    if uis.TouchEnabled then
        -- Mobile: Center of the screen
        local viewportSize = cam.ViewportSize
        fovPos = Vector2.new(viewportSize.X / 2, viewportSize.Y / 2)
    else
        -- PC: Follow mouse
        fovPos = uis:GetMouseLocation()
    end

    for _, plr in pairs(plrs:GetPlayers()) do
        if isValidTarget(plr) then
            local head = plr.Character.Head
            local pos, onScreen = getScreenPos(head)
            if onScreen then
                local dist = (pos - mousePos).Magnitude
                if dist < minDist then
                    minDist = dist
                    closest = plr
                end
            end
        end
    end
    return closest
end

local function findClosestInFOV()
    local closest = nil
    local minDist = fovSize
    local fovPos
    if uis.TouchEnabled then
        -- Mobile: Center of the screen
        local viewportSize = cam.ViewportSize
        fovPos = Vector2.new(viewportSize.X / 2, viewportSize.Y / 2)
    else
        -- PC: Follow mouse
        fovPos = uis:GetMouseLocation()
    end

    for _, plr in pairs(plrs:GetPlayers()) do
        if isValidTarget(plr) then
            local head = plr.Character.Head
            local pos, onScreen = getScreenPos(head)
            if onScreen then
                local dist = (pos - fovPos).Magnitude
                if dist < minDist then
                    minDist = dist
                    closest = plr
                end
            end
        end
    end
    return closest, fovPos
end

-- Aimbot logic
rs.RenderStepped:Connect(function()
    if aimbotEnabled then
        fovCircle.Visible = true
        fovCircle.Position = uis:GetMouseLocation()
        fovCircle.Radius = fovSize
        fovCircle.Color = fovColor

        local target = findClosestInFOV()
        if target then
            local headPos = target.Character.Head.Position
            if usePrediction then
                headPos = headPos + (target.Character.HumanoidRootPart.Velocity * predictionValue)
            end
            cam.CFrame = CFrame.lookAt(cam.CFrame.Position, headPos)
        end
    else
        fovCircle.Visible = false
    end
end)

-- GUI
local MainTab = UI:create_tab("Aimbot & ESP", "rbxassetid://90319103293063")

-- Aimbot Module
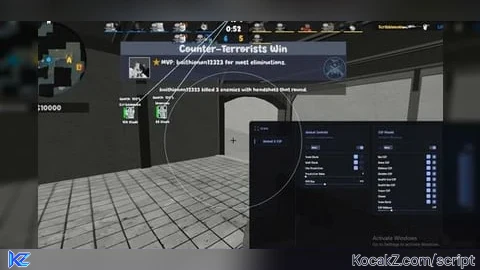
local AimbotModule = MainTab:create_module({
    title = "Aimbot Controls",
    description = "Configure aimbot settings",
    section = "left",
    flag = "aimbot_module",
    callback = function(state)
        aimbotEnabled = state
        print("Aimbot:", state and "Enabled" or "Disabled")
    end
})

-- Aimbot Team Check
AimbotModule:create_checkbox({
    title = "Team Check",
    flag = "aimbot_team_check",
    value = false,
    callback = function(value)
        aimbotTeamCheck = value
        print("Aimbot Team Check:", value)
    end
})

-- Wall Check
AimbotModule:create_checkbox({
    title = "Wall Check",
    flag = "wall_check",
    value = false,
    callback = function(value)
        wallCheck = value
        print("Wall Check:", value)
    end
})

-- Use Prediction
AimbotModule:create_checkbox({
    title = "Use Prediction",
    flag = "use_prediction",
    value = false,
    callback = function(value)
        usePrediction = value
        print("Use Prediction:", value)
    end
})

-- Prediction Value
AimbotModule:create_slider({
    title = "Prediction Value",
    flag = "prediction_value",
    minimum_value = 0,
    maximum_value = 1,
    value = 0,
    round_number = false,
    callback = function(value)
        predictionValue = value
        print("Prediction Value:", value)
    end
})

-- FOV Size
AimbotModule:create_slider({
    title = "FOV Size",
    flag = "fov_size",
    minimum_value = 50,
    maximum_value = 600,
    value = 200,
    round_number = true,
    callback = function(value)
        fovSize = value
        print("FOV Size:", value)
    end
})

-- ESP Module
local ESPModule = MainTab:create_module({
    title = "ESP Visuals",
    description = "Configure ESP settings",
    section = "right",
    flag = "esp_module",
    callback = function(state)
        print("ESP Module:", state and "Enabled" or "Disabled")
    end
})

-- Box ESP
ESPModule:create_checkbox({
    title = "Box ESP",
    flag = "box_esp",
    value = false,
    callback = function(value)
        if value then
            esp:InitiateBox(Color3.fromRGB(208, 240, 253))
        else
            esp.State.BoxEnabled = false
        end
        print("Box ESP:", value)
    end
})

-- Name ESP
ESPModule:create_checkbox({
    title = "Name ESP",
    flag = "name_esp",
    value = false,
    callback = function(value)
        esp:InitiateName(value)
        print("Name ESP:", value)
    end
})

-- Distance ESP
ESPModule:create_checkbox({
    title = "Distance ESP",
    flag = "distance_esp",
    value = false,
    callback = function(value)
        esp:InitiateDistance(value)
        print("Distance ESP:", value)
    end
})

-- Skeleton ESP
ESPModule:create_checkbox({
    title = "Skeleton ESP",
    flag = "skeleton_esp",
    value = false,
    callback = function(value)
        if value then
            esp:InitiateSkeleton(Color3.fromRGB(208, 240, 253))
        else
            esp.State.SkeletonEnabled = false
        end
        print("Skeleton ESP:", value)
    end
})

-- Health Text ESP
ESPModule:create_checkbox({
    title = "Health Text ESP",
    flag = "health_text_esp",
    value = false,
    callback = function(value)
        esp:InitiateHealthText(value)
        print("Health Text ESP:", value)
    end
})

-- Health Bar ESP
ESPModule:create_checkbox({
    title = "Health Bar ESP",
    flag = "health_bar_esp",
    value = false,
    callback = function(value)
        esp:InitiateHealthBar(value)
        print("Health Bar ESP:", value)
    end
})

-- Tracer ESP
ESPModule:create_checkbox({
    title = "Tracer ESP",
    flag = "tracer_esp",
    value = false,
    callback = function(value)
        if value then
            esp:InitiateTracer(Color3.fromRGB(208, 240, 253), "Top Screen")
        else
            esp.State.TracerEnabled = false
        end
        print("Tracer ESP:", value)
    end
})

-- Chams
ESPModule:create_checkbox({
    title = "Chams",
    flag = "chams",
    value = false,
    callback = function(value)
        if value then
            esp:InitiateChams(Color3.fromRGB(208, 240, 253))
        else
            esp.State.ChamsEnabled = false
        end
        print("Chams:", value)
    end
})

-- ESP Team Check
ESPModule:create_checkbox({
    title = "Team Check",
    flag = "esp_team_check",
    value = false,
    callback = function(value)
        esp:TeamCheck(value)
        print("ESP Team Check:", value)
    end
})

-- ESP Distance
ESPModule:create_slider({
    title = "ESP Distance",
    flag = "esp_distance",
    minimum_value = 100,
    maximum_value = 1000,
    value = 325,
    round_number = true,
    callback = function(value)
        esp:SetDistance(value)
        print("ESP Distance:", value)
    end
})

-- Initialize ESP
esp:Initialize()
ai made
report this ai aimbot that doesnt even work
sorry i will fix
@chuuryyy187 is it fixed?
Its fixed
@Sir_Goose sorry it is not fixed yet
it just error because teamcheck is enabled
@chuuryyy187 can u open src matrix mini?
@K1KK sure
@K1KK can you fix some bugs for it?
@chuuryyy187 What bugs do u have?
@chuuryyy187 it is, I tried