KeylessUniversal
local OrionLib = loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/jensonhirst/Orion/main/source'
)
)()
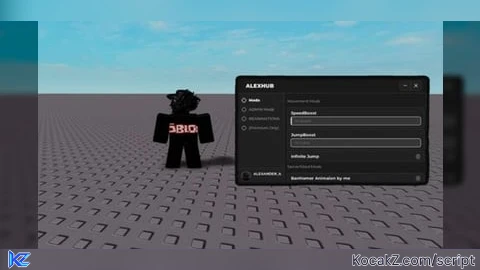
local Window = OrionLib:MakeWindow({
Name = 'ALEXHUB',
HidePremium = false,
SaveConfig = true,
ConfigFolder = 'OrionTest',
})
-- player tab
local PlayerTab = Window:MakeTab({
Name = 'Mods',
Icon = 'rbxassetid://4483345998',
PremiumOnly = false,
})
local Section = PlayerTab:AddSection({
Name = 'Movement Mods',
})
PlayerTab:AddSlider({
Name = 'SpeedBoost',
Min = 10,
Max = 1000,
Default = 16,
Color = Color3.fromRGB(255, 255, 255),
Increment = 1,
ValueName = 'Speed',
Callback = function(Value)
game.Players.LocalPlayer.Character.Humanoid.WalkSpeed = Value
end,
})
PlayerTab:AddSlider({
Name = 'JumpBoost',
Min = 10,
Max = 1000,
Default = 5,
Color = Color3.fromRGB(255, 255, 255),
Increment = 1,
ValueName = 'Jump',
Callback = function(Value)
game.Players.LocalPlayer.Character.Humanoid.JumpPower = Value
end,
})
PlayerTab:AddButton({
Name = 'Infinite Jump',
Callback = function()
local InfiniteJumpEnabled = true
game:GetService('UserInputService').JumpRequest:connect(function()
if InfiniteJumpEnabled then
game
:GetService('Players').LocalPlayer.Character
:FindFirstChildOfClass('Humanoid')
:ChangeState('Jumping')
end
end)
end,
})
local Section = PlayerTab:AddSection({
Name = 'ServerSited Mods',
})
PlayerTab:AddButton({
Name = 'BanHamer Animaion by me',
Callback = function()
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/ShutUpJamesTheLoser/Banhammer/refs/heads/main/ban',
true
)
)()
end,
})
PlayerTab:AddButton({
Name = 'FE Sound Spammer GUI',
Callback = function()
local ScreenGui = Instance.new('ScreenGui')
local Draggable = Instance.new('Frame')
local Frame = Instance.new('Frame')
local Frame_2 = Instance.new('Frame')
local Time = Instance.new('TextLabel')
local _1E = Instance.new('TextButton')
local UICorner = Instance.new('UICorner')
local _3E = Instance.new('TextButton')
local UICorner_2 = Instance.new('UICorner')
local SE = Instance.new('TextButton')
local UICorner_3 = Instance.new('UICorner')
local Path = Instance.new('TextLabel')
local Top = Instance.new('Frame')
local Top_2 = Instance.new('Frame')
local ImageLabel = Instance.new('ImageLabel')
local TextLabel = Instance.new('TextLabel')
local Exit = Instance.new('TextButton')
local Minizum = Instance.new('TextButton')
local Stop = Instance.new('TextButton')
local UICorner_4 = Instance.new('UICorner')
local IY = Instance.new('TextButton')
local UICorner_5 = Instance.new('UICorner')
local TextLabel_2 = Instance.new('TextLabel')
local Wait = Instance.new('TextBox')
--Properties:
ScreenGui.Name =
'. Ǥ҉̷҉̵҉̸҉̷҉̵҉̸҉̡҉̡҉̼҉̱҉͎҉͎҉̞҉̼҉̱҉͎҉͎҉̞҉ͤ҉ͬ҉̅҉ͤ҉ͬ'
ScreenGui.Parent = game:GetService('CoreGui')
ScreenGui.ZIndexBehavior = Enum.ZIndexBehavior.Sibling
ScreenGui.ResetOnSpawn = false
Draggable.Name =
'Ǥ҉̷҉̵҉̸҉̷҉̵҉̸҉̡҉̡҉̼҉̱҉͎҉͎҉̞҉̼҉̱҉͎҉͎҉̞҉ͤ҉ͬ҉̅҉ͤ҉ͬ.'
Draggable.Parent = ScreenGui
Draggable.BackgroundColor3 = Color3.fromRGB(255, 255, 255)
Draggable.BackgroundTransparency = 1.000
Draggable.BorderSizePixel = 0
Draggable.Position = UDim2.new(0.35026139, 0, 0.296158612, 0)
Draggable.Size = UDim2.new(0, 438, 0, 277)
Frame.Name =
'. . Ǥ҉̷҉̵҉̸҉̷҉̵҉̸҉̡҉̡҉̼҉̱҉͎҉͎҉̞҉̼҉̱҉͎҉͎҉̞҉ͤ҉ͬ҉̅҉ͤ҉ͬ. '
Frame.Parent = Draggable
Frame.BackgroundColor3 = Color3.fromRGB(255, 255, 255)
Frame.BackgroundTransparency = 1.000
Frame.BorderColor3 = Color3.fromRGB(27, 42, 53)
Frame.BorderSizePixel = 0
Frame.Position = UDim2.new(-0.00133678317, 0, -0.00348037481, 0)
Frame.Size = UDim2.new(0, 438, 0, 277)
Frame_2.Name =
' . Ǥ҉̷҉̵҉̸҉̷҉̵҉̸҉̡҉̡҉̼҉̱҉͎҉͎҉̞҉̼҉̱҉͎҉͎҉̞҉ͤ҉ͬ҉̅҉ͤ҉ͬ. '
Frame_2.Parent = Frame
Frame_2.BackgroundColor3 = Color3.fromRGB(30, 30, 30)
Frame_2.BorderColor3 = Color3.fromRGB(27, 42, 53)
Frame_2.BorderSizePixel = 0
Frame_2.Position = UDim2.new(-0.00133678142, 0, -0.0179207586, 0)
Frame_2.Size = UDim2.new(0, 438, 0, 238)
Frame_2.Active = true
Frame_2.Draggable = true
Time.Name = 'Time'
Time.Parent = Frame_2
Time.BackgroundColor3 = Color3.fromRGB(255, 255, 255)
Time.BackgroundTransparency = 1.000
Time.Position = UDim2.new(0, 0, 0.0126050422, 0)
Time.Size = UDim2.new(0, 437, 0, 31)
Time.Font = Enum.Font.GothamSemibold
Time.Text = 'RespectFilteringEnabled(RFE) : nil'
Time.TextColor3 = Color3.fromRGB(255, 255, 255)
Time.TextScaled = true
Time.TextSize = 14.000
Time.TextWrapped = true
_1E.Name = '1E'
_1E.Parent = Frame_2
_1E.BackgroundColor3 = Color3.fromRGB(45, 45, 45)
_1E.BorderSizePixel = 0
_1E.Position = UDim2.new(0.0182648394, 0, 0.676470578, 0)
_1E.Size = UDim2.new(0, 208, 0, 33)
_1E.Font = Enum.Font.SourceSans
_1E.Text = 'Mute Game'
_1E.TextColor3 = Color3.fromRGB(255, 255, 255)
_1E.TextScaled = true
_1E.TextSize = 30.000
_1E.TextWrapped = true
UICorner.Parent = _1E
_3E.Name = '3E'
_3E.Parent = Frame_2
_3E.BackgroundColor3 = Color3.fromRGB(45, 45, 45)
_3E.BorderSizePixel = 0
_3E.Position = UDim2.new(0.0159817357, 0, 0.142857149, 0)
_3E.Size = UDim2.new(0, 209, 0, 33)
_3E.Font = Enum.Font.SourceSans
_3E.Text = 'Annoying Sound'
_3E.TextColor3 = Color3.fromRGB(255, 255, 255)
_3E.TextSize = 30.000
_3E.TextWrapped = true
UICorner_2.Parent = _3E
SE.Name = 'SE'
SE.Parent = Frame_2
SE.BackgroundColor3 = Color3.fromRGB(45, 45, 45)
SE.BorderSizePixel = 0
SE.Position = UDim2.new(0.509132445, 0, 0.142857149, 0)
SE.Size = UDim2.new(0, 209, 0, 33)
SE.Font = Enum.Font.SourceSans
SE.Text = 'Kill Sound Service'
SE.TextColor3 = Color3.fromRGB(255, 255, 255)
SE.TextSize = 30.000
SE.TextWrapped = true
UICorner_3.Parent = SE
Path.Name = 'Path'
Path.Parent = Frame_2
Path.BackgroundColor3 = Color3.fromRGB(255, 0, 0)
Path.BackgroundTransparency = 1.000
Path.Position = UDim2.new(0.00684931502, 0, 0.815126061, 0)
Path.Size = UDim2.new(0, 435, 0, 44)
Path.Font = Enum.Font.GothamSemibold
Path.Text =
'Dev Note : This Script is FE and it only FE when RespectFilteringEnabled(RFE) is disabled , elseif RespectFilteringEnabled(RFE) is true then it only be client , mostly RespectFilteringEnabled(RFE) disabled game are classic game'
Path.TextColor3 = Color3.fromRGB(255, 0, 0)
Path.TextScaled = true
Path.TextSize = 14.000
Path.TextWrapped = true
Top.Name = 'Top'
Top.Parent = Frame_2
Top.BackgroundColor3 = Color3.fromRGB(41, 60, 157)
Top.BorderColor3 = Color3.fromRGB(27, 42, 53)
Top.BorderSizePixel = 0
Top.Position = UDim2.new(-0.00133678142, 0, -0.128059402, 0)
Top.Size = UDim2.new(0, 438, 0, 30)
Top_2.Name = 'Top'
Top_2.Parent = Top
Top_2.BackgroundColor3 = Color3.fromRGB(30, 45, 118)
Top_2.BorderColor3 = Color3.fromRGB(27, 42, 53)
Top_2.BorderSizePixel = 0
Top_2.Position = UDim2.new(0, 0, 0.967638671, 0)
Top_2.Size = UDim2.new(0, 438, 0, 5)
ImageLabel.Parent = Top
ImageLabel.BackgroundColor3 = Color3.fromRGB(255, 255, 255)
ImageLabel.BackgroundTransparency = 1.000
ImageLabel.Position = UDim2.new(0, 0, 0.0666666701, 0)
ImageLabel.Size = UDim2.new(0, 29, 0, 27)
ImageLabel.Image = 'http://www.roblox.com/asset/?id=8798286232'
TextLabel.Parent = ImageLabel
TextLabel.BackgroundColor3 = Color3.fromRGB(255, 255, 255)
TextLabel.BackgroundTransparency = 1.000
TextLabel.Position = UDim2.new(0.997245014, 0, 0, 0)
TextLabel.Size = UDim2.new(0, 397, 0, 30)
TextLabel.Font = Enum.Font.GothamSemibold
TextLabel.Text = 'FEAG'
TextLabel.TextColor3 = Color3.fromRGB(255, 255, 255)
TextLabel.TextScaled = true
TextLabel.TextSize = 14.000
TextLabel.TextStrokeColor3 = Color3.fromRGB(255, 255, 255)
TextLabel.TextWrapped = true
Exit.Name = 'Exit'
Exit.Parent = Top
Exit.BackgroundColor3 = Color3.fromRGB(255, 255, 255)
Exit.BackgroundTransparency = 1.000
Exit.Position = UDim2.new(0.924657524, 0, 0, 0)
Exit.Size = UDim2.new(0, 32, 0, 25)
Exit.Font = Enum.Font.GothamSemibold
Exit.Text = 'x'
Exit.TextColor3 = Color3.fromRGB(255, 255, 255)
Exit.TextScaled = true
Exit.TextSize = 14.000
Exit.TextWrapped = true
Minizum.Name = 'Minizum'
Minizum.Parent = Top
Minizum.BackgroundColor3 = Color3.fromRGB(255, 255, 255)
Minizum.BackgroundTransparency = 1.000
Minizum.Position = UDim2.new(0.851598203, 0, 0, 0)
Minizum.Size = UDim2.new(0, 32, 0, 23)
Minizum.Font = Enum.Font.GothamSemibold
Minizum.Text = '_'
Minizum.TextColor3 = Color3.fromRGB(255, 255, 255)
Minizum.TextScaled = true
Minizum.TextSize = 14.000
Minizum.TextWrapped = true
Stop.Name = 'Stop'
Stop.Parent = Frame_2
Stop.BackgroundColor3 = Color3.fromRGB(45, 45, 45)
Stop.BorderSizePixel = 0
Stop.Position = UDim2.new(0.0182648394, 0, 0.310924381, 0)
Stop.Size = UDim2.new(0, 424, 0, 33)
Stop.Font = Enum.Font.SourceSans
Stop.Text = 'Stop'
Stop.TextColor3 = Color3.fromRGB(255, 255, 255)
Stop.TextSize = 30.000
Stop.TextWrapped = true
UICorner_4.Parent = Stop
IY.Name = 'IY'
IY.Parent = Frame_2
IY.BackgroundColor3 = Color3.fromRGB(45, 45, 45)
IY.BorderSizePixel = 0
IY.Position = UDim2.new(0.509132445, 0, 0.676470578, 0)
IY.Size = UDim2.new(0, 209, 0, 33)
IY.Font = Enum.Font.SourceSans
IY.Text = 'Unmute Game'
IY.TextColor3 = Color3.fromRGB(255, 255, 255)
IY.TextScaled = true
IY.TextSize = 30.000
IY.TextWrapped = true
UICorner_5.Parent = IY
TextLabel_2.Parent = Frame_2
TextLabel_2.BackgroundColor3 = Color3.fromRGB(255, 255, 255)
TextLabel_2.BackgroundTransparency = 1.000
TextLabel_2.Position = UDim2.new(0.0182648394, 0, 0.466386557, 0)
TextLabel_2.Size = UDim2.new(0, 426, 0, 50)
TextLabel_2.Font = Enum.Font.GothamSemibold
TextLabel_2.Text = 'Wait Speed :'
TextLabel_2.TextColor3 = Color3.fromRGB(255, 255, 255)
TextLabel_2.TextSize = 30.000
TextLabel_2.TextWrapped = true
TextLabel_2.TextXAlignment = Enum.TextXAlignment.Left
Wait.Name = 'Wait()'
Wait.Parent = Frame_2
Wait.BackgroundColor3 = Color3.fromRGB(255, 255, 255)
Wait.BackgroundTransparency = 1.000
Wait.Position = UDim2.new(0.531963468, 0, 0.466386557, 0)
Wait.Size = UDim2.new(0, 199, 0, 50)
Wait.ZIndex = 99999
Wait.ClearTextOnFocus = false
Wait.Font = Enum.Font.GothamSemibold
Wait.Text = '0.5'
Wait.TextColor3 = Color3.fromRGB(255, 255, 255)
Wait.TextSize = 30.000
Wait.TextWrapped = true
--Sound Service:
local notification = Instance.new('Sound')
notification.Parent = game:GetService('SoundService')
notification.SoundId = 'rbxassetid://9086208751'
notification.Volume = 5
notification.Name =
'. Ǥ҉̷҉̵҉̸҉̷҉̵҉̸҉̡҉̡҉̼҉̱҉͎҉͎҉̞҉̼҉̱҉͎҉͎҉̞҉ͤ҉ͬ҉̅҉ͤ҉ͬ'
--funuction:
Exit.MouseButton1Click:Connect(function()
ScreenGui:Destroy()
end)
local Mute = false
IY.MouseButton1Click:Connect(function()
Mute = false
end)
_1E.MouseButton1Click:Connect(function()
Mute = true
while Mute == true do
wait()
for _, sound in next, workspace:GetDescendants() do
if sound:IsA('Sound') then
sound:Stop()
end
end
end
end)
_3E.MouseButton1Click:Connect(function()
for _, sound in next, workspace:GetDescendants() do
if sound:IsA('Sound') then
sound:Play()
end
end
end)
local Active = true
SE.MouseButton1Click:Connect(function()
Active = true
while Active == true do
local StringValue = Wait.Text
wait(StringValue)
for _, sound in next, workspace:GetDescendants() do
if sound:IsA('Sound') then
sound:Play()
end
end
end
end)
Stop.MouseButton1Click:Connect(function()
Active = false
end)
--Credit:
notification:Play()
game:GetService('StarterGui'):SetCore('SendNotification', {
Title = 'FEAG',
Text = 'FEAG Has Been Loaded , Made By Scripty#2063 (gamer14_123)',
Icon = '',
Duration = 10,
Button1 = 'Yes Sir',
})
--Check:
while true do
wait(0.5)
local setting =
game:GetService('SoundService').RespectFilteringEnabled
if setting == true then
Time.TextColor = BrickColor.new(255, 0, 0)
Time.Text = 'RespectFilteringEnabled(RFE) : true'
elseif setting == false then
Time.Text = 'RespectFilteringEnabled(RFE) : false'
Time.TextColor = BrickColor.new(0, 255, 0)
end
end
end,
})
PlayerTab:AddButton({
Name = 'AquaMatrix Animations (VERY OP)',
Callback = function()
--[[
WARNING: Heads up! This script has not been verified by ScriptBlox. Use at your own risk!
]]
--[[
- I really appreciate it if you join my discord server ^^
- https://discord.gg/GzQGE9rr26
- if you encounter any bugs or issue with AquaMatrix, please report it to our discord server.
- AquaMatrix might not work for some executors :(
]]
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/ExploitFin/AquaMatrix/refs/heads/AquaMatrix/AquaMatrix'
)
)()
end,
})
PlayerTab:AddButton({
Name = ' FE Animation GUI (R6, No Hats, Free)',
Callback = function()
loadstring(
game:HttpGet(
'https://gist.githubusercontent.com/MelonsStuff/f018928d2f010789a150b4924e279b16/raw/8de399eb9cbccbde430fcd37270cd4ff171f8b8e/AnimationGUI.txt'
)
)()
end,
})
PlayerTab:AddButton({
Name = 'No Animation for car script',
Callback = function()
loadstring(game:HttpGet('https://pastebin.com/raw/wN9bgjvD'))()
end,
})
--other tab
local OtherTab = Window:MakeTab({
Name = 'ADMIN Mods',
Icon = 'rbxassetid://4483345998',
PremiumOnly = false,
})
local Section = OtherTab:AddSection({
Name = '(ADMIN MOD MENUS)',
})
OtherTab:AddButton({
Name = 'Infinite Yield MOD MENU',
Callback = function()
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/EdgeIY/infiniteyield/master/source'
)
)()
end,
})
OtherTab:AddButton({
Name = 'NoName Admin MOD MENU',
Callback = function()
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/FilteringEnabled/NamelessAdmin/main/Source'
)
)()
end,
})
local OtherTab = Window:MakeTab({
Name = 'REANIMATIONS',
Icon = 'rbxassetid://4483345998',
PremiumOnly = false,
})
local Section = OtherTab:AddSection({
Name = '(GENESIS reanimations)',
})
OtherTab:AddButton({
Name = 'Krystal%20Dance',
Callback = function()
--[[
_________ _____ ___________________
__ ____/__________________________(_)_______ ___ ____/__ ____/
_ / __ _ _ \_ __ \ _ \_ ___/_ /__ ___/ __ /_ __ __/
/ /_/ / / __/ / / / __/(__ )_ / _(__ ) _ __/ _ /___
\____/ \___//_/ /_/\___//____/ /_/ /____/ /_/ /_____/
by rqz
https://discord.com/invite/aEZpBEHgMT
]]
--
--====================================--
-- FDless Options --
--====================================--
permadeath = true --adds permanent death (no respawning), see #supported-executors channel for executors that work with this
fling = true --toggle fling
allowshiftlock = true --adds shiftlock to patchma rig
ctrltp = true --adds control click tp
placeholders = true --adds transparent parts showing your hats when you don't have real ones
clickfling = true --adds click flinging regardless of attacks
highlightflingtargets = true --highlight fling
discharscripts = true --disable character scripts
flingchangestate = true --fling with whole body
hidedeatheffect = true --hides the red damage border when you die (respawn)
respawntp = 3 --respawn tp mode
-- 0 - stay at spawn
-- 1 - randomtp close
-- 2 - behind fake character
-- 3 - hide body
breakjointsmethod = 1 --breakjoints mode
-- 1 - health+breakjoints (the most support)
-- 2 - health or breakjoints
-- 3 - breakjoints
simrad = true --sets simulation radius
--==========================================================================================================================--
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/GenesisFE/Genesis/main/Obfuscations/Krystal%20Dance'
)
)()
--==========================================================================================================================--
end,
})
OtherTab:AddButton({
Name = 'Goner',
Callback = function()
--[[
_________ _____ ___________________
__ ____/__________________________(_)_______ ___ ____/__ ____/
_ / __ _ _ \_ __ \ _ \_ ___/_ /__ ___/ __ /_ __ __/
/ /_/ / / __/ / / / __/(__ )_ / _(__ ) _ __/ _ /___
\____/ \___//_/ /_/\___//____/ /_/ /____/ /_/ /_____/
by rqz
https://discord.com/invite/aEZpBEHgMT
]]
--
--====================================--
-- FDless Options --
--====================================--
permadeath = true --adds permanent death (no respawning), see #supported-executors channel for executors that work with this
fling = true --toggle fling
allowshiftlock = true --adds shiftlock to patchma rig
ctrltp = true --adds control click tp
placeholders = true --adds transparent parts showing your hats when you don't have real ones
clickfling = false --adds click flinging regardless of attacks
highlightflingtargets = true --highlight fling
discharscripts = true --disable character scripts
flingchangestate = true --fling with whole body
hidedeatheffect = true --hides the red damage border when you die (respawn)
respawntp = 3 --respawn tp mode
-- 0 - stay at spawn
-- 1 - randomtp close
-- 2 - behind fake character
-- 3 - hide body
breakjointsmethod = 1 --breakjoints mode
-- 1 - health+breakjoints (the most support)
-- 2 - health or breakjoints
-- 3 - breakjoints
simrad = true --sets simulation radius
--==========================================================================================================================--
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/GenesisFE/Genesis/main/Obfuscations/Goner'
)
)()
--==========================================================================================================================--
end,
})
OtherTab:AddButton({
Name = 'Neptunian%20V',
Callback = function()
--[[
_________ _____ ___________________
__ ____/__________________________(_)_______ ___ ____/__ ____/
_ / __ _ _ \_ __ \ _ \_ ___/_ /__ ___/ __ /_ __ __/
/ /_/ / / __/ / / / __/(__ )_ / _(__ ) _ __/ _ /___
\____/ \___//_/ /_/\___//____/ /_/ /____/ /_/ /_____/
by rqz
https://discord.com/invite/aEZpBEHgMT
]]
--
--====================================--
-- FDless Options --
--====================================--
permadeath = true --adds permanent death (no respawning), see #supported-executors channel for executors that work with this
fling = true --toggle fling
allowshiftlock = true --adds shiftlock to patchma rig
ctrltp = true --adds control click tp
placeholders = true --adds transparent parts showing your hats when you don't have real ones
clickfling = false --adds click flinging regardless of attacks
highlightflingtargets = true --highlight fling
discharscripts = true --disable character scripts
flingchangestate = true --fling with whole body
hidedeatheffect = true --hides the red damage border when you die (respawn)
respawntp = 3 --respawn tp mode
-- 0 - stay at spawn
-- 1 - randomtp close
-- 2 - behind fake character
-- 3 - hide body
breakjointsmethod = 1 --breakjoints mode
-- 1 - health+breakjoints (the most support)
-- 2 - health or breakjoints
-- 3 - breakjoints
simrad = true --sets simulation radius
--==========================================================================================================================--
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/GenesisFE/Genesis/main/Obfuscations/Neptunian%20V'
)
)()
--==========================================================================================================================--
end,
})
OtherTab:AddButton({
Name = 'Studio%20Dummy',
Callback = function()
--[[
_________ _____ ___________________
__ ____/__________________________(_)_______ ___ ____/__ ____/
_ / __ _ _ \_ __ \ _ \_ ___/_ /__ ___/ __ /_ __ __/
/ /_/ / / __/ / / / __/(__ )_ / _(__ ) _ __/ _ /___
\____/ \___//_/ /_/\___//____/ /_/ /____/ /_/ /_____/
by rqz
https://discord.com/invite/aEZpBEHgMT
]]
--
--====================================--
-- FDless Options --
--====================================--
permadeath = true --adds permanent death (no respawning), see #supported-executors channel for executors that work with this
fling = true --toggle fling
allowshiftlock = true --adds shiftlock to patchma rig
ctrltp = true --adds control click tp
placeholders = true --adds transparent parts showing your hats when you don't have real ones
clickfling = false --adds click flinging regardless of attacks
highlightflingtargets = true --highlight fling
discharscripts = true --disable character scripts
flingchangestate = true --fling with whole body
hidedeatheffect = true --hides the red damage border when you die (respawn)
respawntp = 3 --respawn tp mode
-- 0 - stay at spawn
-- 1 - randomtp close
-- 2 - behind fake character
-- 3 - hide body
breakjointsmethod = 1 --breakjoints mode
-- 1 - health+breakjoints (the most support)
-- 2 - health or breakjoints
-- 3 - breakjoints
simrad = true --sets simulation radius
--==========================================================================================================================--
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/GenesisFE/Genesis/main/Obfuscations/Studio%20Dummy'
)
)()
--==========================================================================================================================--
end,
})
OtherTab:AddButton({
Name = 'Gale%20Fighter',
Callback = function()
--[[
_________ _____ ___________________
__ ____/__________________________(_)_______ ___ ____/__ ____/
_ / __ _ _ \_ __ \ _ \_ ___/_ /__ ___/ __ /_ __ __/
/ /_/ / / __/ / / / __/(__ )_ / _(__ ) _ __/ _ /___
\____/ \___//_/ /_/\___//____/ /_/ /____/ /_/ /_____/
by rqz
https://discord.com/invite/aEZpBEHgMT
]]
--
--====================================--
-- FDless Options --
--====================================--
permadeath = true --adds permanent death (no respawning), see #supported-executors channel for executors that work with this
fling = true --toggle fling
allowshiftlock = true --adds shiftlock to patchma rig
ctrltp = true --adds control click tp
placeholders = true --adds transparent parts showing your hats when you don't have real ones
clickfling = false --adds click flinging regardless of attacks
highlightflingtargets = true --highlight fling
discharscripts = true --disable character scripts
flingchangestate = true --fling with whole body
hidedeatheffect = true --hides the red damage border when you die (respawn)
respawntp = 3 --respawn tp mode
-- 0 - stay at spawn
-- 1 - randomtp close
-- 2 - behind fake character
-- 3 - hide body
breakjointsmethod = 1 --breakjoints mode
-- 1 - health+breakjoints (the most support)
-- 2 - health or breakjoints
-- 3 - breakjoints
simrad = true --sets simulation radius
--==========================================================================================================================--
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/GenesisFE/Genesis/main/Obfuscations/Gale%20Fighter'
)
)()
--==========================================================================================================================--
end,
})
OtherTab:AddButton({
Name = 'Ban%20Hammer',
Callback = function()
--[[
_________ _____ ___________________
__ ____/__________________________(_)_______ ___ ____/__ ____/
_ / __ _ _ \_ __ \ _ \_ ___/_ /__ ___/ __ /_ __ __/
/ /_/ / / __/ / / / __/(__ )_ / _(__ ) _ __/ _ /___
\____/ \___//_/ /_/\___//____/ /_/ /____/ /_/ /_____/
by rqz
https://discord.com/invite/aEZpBEHgMT
]]
--
--====================================--
-- FDless Options --
--====================================--
permadeath = true --adds permanent death (no respawning), see #supported-executors channel for executors that work with this
fling = true --toggle fling
allowshiftlock = true --adds shiftlock to patchma rig
ctrltp = true --adds control click tp
placeholders = true --adds transparent parts showing your hats when you don't have real ones
clickfling = false --adds click flinging regardless of attacks
highlightflingtargets = true --highlight fling
discharscripts = true --disable character scripts
flingchangestate = true --fling with whole body
hidedeatheffect = true --hides the red damage border when you die (respawn)
respawntp = 3 --respawn tp mode
-- 0 - stay at spawn
-- 1 - randomtp close
-- 2 - behind fake character
-- 3 - hide body
breakjointsmethod = 1 --breakjoints mode
-- 1 - health+breakjoints (the most support)
-- 2 - health or breakjoints
-- 3 - breakjoints
simrad = true --sets simulation radius
--==========================================================================================================================--
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/GenesisFE/Genesis/main/Obfuscations/Ban%20Hammer'
)
)()
--==========================================================================================================================--
end,
})
OtherTab:AddButton({
Name = 'Puppet%20Master',
Callback = function()
--[[
_________ _____ ___________________
__ ____/__________________________(_)_______ ___ ____/__ ____/
_ / __ _ _ \_ __ \ _ \_ ___/_ /__ ___/ __ /_ __ __/
/ /_/ / / __/ / / / __/(__ )_ / _(__ ) _ __/ _ /___
\____/ \___//_/ /_/\___//____/ /_/ /____/ /_/ /_____/
by rqz
https://discord.com/invite/aEZpBEHgMT
]]
--
--===================================--
--= Script Options =--
--===================================--
DisableRedAnimatedText = false --disables the animated text that keeps popping up on screen, does not disable Kills, Target or Script Title
--====================================--
-- FDless Options --
--====================================--
permadeath = true --adds permanent death (no respawning), see #supported-executors channel for executors that work with this
fling = true --toggle fling
allowshiftlock = true --adds shiftlock to patchma rig
ctrltp = true --adds control click tp
placeholders = true --adds transparent parts showing your hats when you don't have real ones
clickfling = false --adds click flinging regardless of attacks
highlightflingtargets = true --highlight fling
discharscripts = true --disable character scripts
flingchangestate = true --fling with whole body
hidedeatheffect = true --hides the red damage border when you die (respawn)
respawntp = 3 --respawn tp mode
-- 0 - stay at spawn
-- 1 - randomtp close
-- 2 - behind fake character
-- 3 - hide body
breakjointsmethod = 1 --breakjoints mode
-- 1 - health+breakjoints (the most support)
-- 2 - health or breakjoints
-- 3 - breakjoints
simrad = true --sets simulation radius
--==========================================================================================================================--
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/GenesisFE/Genesis/main/Obfuscations/Puppet%20Master'
)
)()
--==========================================================================================================================--
end,
})
OtherTab:AddButton({
Name = 'Minigun',
Callback = function()
--[[
_________ _____ ___________________
__ ____/__________________________(_)_______ ___ ____/__ ____/
_ / __ _ _ \_ __ \ _ \_ ___/_ /__ ___/ __ /_ __ __/
/ /_/ / / __/ / / / __/(__ )_ / _(__ ) _ __/ _ /___
\____/ \___//_/ /_/\___//____/ /_/ /____/ /_/ /_____/
by rqz
https://discord.com/invite/aEZpBEHgMT
]]
--
--====================================--
-- FDless Options --
--====================================--
permadeath = true --adds permanent death (no respawning), see #supported-executors channel for executors that work with this
fling = true --toggle fling
allowshiftlock = true --adds shiftlock to patchma rig
ctrltp = true --adds control click tp
placeholders = true --adds transparent parts showing your hats when you don't have real ones
clickfling = false --adds click flinging regardless of attacks
highlightflingtargets = true --highlight fling
discharscripts = true --disable character scripts
flingchangestate = true --fling with whole body
hidedeatheffect = true --hides the red damage border when you die (respawn)
respawntp = 3 --respawn tp mode
-- 0 - stay at spawn
-- 1 - randomtp close
-- 2 - behind fake character
-- 3 - hide body
breakjointsmethod = 1 --breakjoints mode
-- 1 - health+breakjoints (the most support)
-- 2 - health or breakjoints
-- 3 - breakjoints
simrad = true --sets simulation radius
--==========================================================================================================================--
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/GenesisFE/Genesis/main/Obfuscations/Minigun'
)
)()
--==========================================================================================================================--
end,
})
OtherTab:AddButton({
Name = 'Sniper',
Callback = function()
--[[
_________ _____ ___________________
__ ____/__________________________(_)_______ ___ ____/__ ____/
_ / __ _ _ \_ __ \ _ \_ ___/_ /__ ___/ __ /_ __ __/
/ /_/ / / __/ / / / __/(__ )_ / _(__ ) _ __/ _ /___
\____/ \___//_/ /_/\___//____/ /_/ /____/ /_/ /_____/
by rqz
https://discord.com/invite/aEZpBEHgMT
]]
--
--====================================--
-- FDless Options --
--====================================--
permadeath = true --adds permanent death (no respawning), see #supported-executors channel for executors that work with this
fling = true --toggle fling
allowshiftlock = true --adds shiftlock to patchma rig
ctrltp = true --adds control click tp
placeholders = true --adds transparent parts showing your hats when you don't have real ones
clickfling = false --adds click flinging regardless of attacks
highlightflingtargets = true --highlight fling
discharscripts = true --disable character scripts
flingchangestate = true --fling with whole body
hidedeatheffect = true --hides the red damage border when you die (respawn)
respawntp = 3 --respawn tp mode
-- 0 - stay at spawn
-- 1 - randomtp close
-- 2 - behind fake character
-- 3 - hide body
breakjointsmethod = 1 --breakjoints mode
-- 1 - health+breakjoints (the most support)
-- 2 - health or breakjoints
-- 3 - breakjoints
simrad = true --sets simulation radius
--==========================================================================================================================--
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/GenesisFE/Genesis/main/Obfuscations/Sniper'
)
)()
--==========================================================================================================================--
end,
})
local Section = OtherTab:AddSection({
Name = '(MyWorld reanimations)',
})
OtherTab:AddButton({
Name = 'patchma hub v46',
Callback = function()
--[[
patchma hub by MyWorld
lets get the party started
IDs of paid accessories:
-for arms 11159410305,11263254795 or 14255556501,14255554762 or 12344545199,12344591101 or 13839976999,13831200263
-for legs 14768693948,14768701869 or 11159483910,12652786974 or 17401151565,17387616772
-for torso 14255528083 or 13421786478 or 14768678294
or anything else that covers ur torso. examples:
14532301415,13423624885,11502853991,14053485259,13779879140,14443132226,17163407577,16297156693,17180496303,17171230401
can be same stuff but different colors
there are 156 ways to make a rig with the ids above
IDs of free accessories:
3033910400,3409612660,3438342658,3398308134,4324158403,3822880197,4154538250,3443038622,4819740796
accessories for Immortality Lord:
head: 17375337078 or 17270164442 or 105058659622112
body: 121668589285446,80629770394501,127671621543010,76687571475377,120230112701079
or 132908702618809,122975605535029,115313441748457,127208207296576,131203955709755
or 17270178857,17270001635,17269952801,17269983359,17269998373
wings: 17270231731,17270225913
sword: 17326812233,17326800544
]]
--no need to get and index the library tables with function names every time the script uses them
local osclock = os.clock
local tspawn = task.spawn
local twait = task.wait
local schar = string.char
local ssub = string.sub
local sfind = string.find
local supper = string.upper
local mrandom = math.random
local sin = math.sin
local cos = math.cos
local abs = math.abs
local min = math.min
local clamp = math.clamp
local tinsert = table.insert
local tclear = table.clear
local tclone = table.clone
local tfind = table.find
--the script doesnt have to read global varaibles every time to get them
--why not have them saved in local varaibles for faster access times
local next = next
local pcall = pcall
local xpcall = xpcall
local type = type
local typeof = typeof
local game = game
local replicatesignal = replicatesignal
local i = Instance.new
local v2 = Vector2.new
local v3 = Vector3.new
local c3 = Color3.new
local cf = CFrame.new
local cfl = CFrame.lookAt
local angles = CFrame.fromEulerAngles --faster than .Angles
local u2 = UDim2.new
local e = Enum
local rp = RaycastParams.new
local cs = ColorSequence.new
local csk = ColorSequenceKeypoint.new
local sine = osclock()
local deltaTime = 0
local v3_0 = v3()
local v3_101 = v3(1, 0, 1)
local v3_010 = v3(0, 1, 0)
local cf_0 = cf()
local v3_xz = v3_101 * 10
local v3_xzL = v3_101 * 250.1
local v3_net = v3_010 * 25.01
local pdloadedtime = nil
--not "local function rs" to not assign debug names
local rs = function()
local s = ''
for i = 1, mrandom(8, 15) do
if mrandom(2) == 2 then
s = s .. schar(mrandom(65, 90))
else
s = s .. schar(mrandom(97, 122))
end
end
return s
end
--it runs even faster if u call __index and __newindex metamethods directly
local getMetamethodFromErrorStack = function(userdata, f, test)
local ret = nil
xpcall(f, function()
ret = debug.info(2, 'f')
end, userdata, nil, 0)
if (type(ret) ~= 'function') or not test(ret) then
return f
end
return ret
end
local insSet = getMetamethodFromErrorStack(game, function(a, b, c)
a[b] = c
end, function(f)
local a = i('Folder')
local b = rs()
f(a, 'Name', b)
return a.Name == b
end)
local insGet = getMetamethodFromErrorStack(game, function(a, b)
return a[b]
end, function(f)
local a = i('Folder')
local b = rs()
a.Name = b
return f(a, 'Name') == b
end)
local cfGet = getMetamethodFromErrorStack(cf_0, function(a, b)
return a[b]
end, function(f)
return f(cf(1, 2, 3), 'Position') == v3(1, 2, 3)
end)
local cfMul = getMetamethodFromErrorStack(cf_0, function(a, b)
return a * b
end, function(f)
return angles(1, 2, 3) * angles(1, 2, 3)
== f(angles(1, 2, 3), angles(1, 2, 3))
end)
local cfAdd = getMetamethodFromErrorStack(cf_0, function(a, b)
return a + b
end, function(f)
return cf(1, 2, 3) + v3(1, 2, 3) == f(cf(1, 2, 3), v3(1, 2, 3))
end)
local v3Get = getMetamethodFromErrorStack(v3_0, function(a, b)
return a[b]
end, function(f)
return v3(1, 2, 3).Unit == f(v3(1, 2, 3), 'Unit')
end)
--multiplying and adding vector3 is faster if you use the * and + operators
--no need to index instances every time to call their functions
local Clone = insGet(game, 'Clone')
local ClearAllChildren = insGet(game, 'ClearAllChildren')
local Destroy = insGet(game, 'Destroy')
local IsA = insGet(game, 'IsA')
local FindFirstChildOfClass = insGet(game, 'FindFirstChildOfClass')
local FindFirstChildWhichIsA = insGet(game, 'FindFirstChildWhichIsA')
local GetChildren = insGet(game, 'GetChildren')
local GetDescendants = insGet(game, 'GetDescendants')
local IsDescendantOf = insGet(game, 'IsDescendantOf')
local GetPropertyChangedSignal = insGet(
game,
'GetPropertyChangedSignal'
)
--findfirstchildofclass faster than getservice
local plrs = FindFirstChildOfClass(game, 'Players')
local rus = FindFirstChildOfClass(game, 'RunService')
local ws = FindFirstChildOfClass(game, 'Workspace')
local uis = FindFirstChildOfClass(game, 'UserInputService')
local gs = FindFirstChildOfClass(game, 'GuiService')
local sg = FindFirstChildOfClass(game, 'StarterGui')
local lp = insGet(plrs, 'LocalPlayer')
local pg = FindFirstChildOfClass(lp, 'PlayerGui')
local mouse = insGet(lp, 'GetMouse')(lp)
local cdsb = insGet(lp, 'ConnectDiedSignalBackend')
local rst = insGet(plrs, 'RespawnTime') + 0.07 --1/15
local preanimation = insGet(rus, 'PreAnimation')
local heartbeat = insGet(rus, 'Heartbeat')
local renderstepped = insGet(rus, 'RenderStepped')
local GetPlayers = insGet(plrs, 'GetPlayers')
local SetCoreGuiEnabled = insGet(sg, 'SetCoreGuiEnabled')
local GetCoreGuiEnabled = insGet(sg, 'GetCoreGuiEnabled')
local Raycast = insGet(ws, 'Raycast')
local Connect = heartbeat.Connect
local Disconnect = Connect(
GetPropertyChangedSignal(game, 'CreatorId'),
type
).Disconnect
local Wait = heartbeat.Wait
local GetMouseLocation = insGet(uis, 'GetMouseLocation')
local GetFocusedTextBox = insGet(uis, 'GetFocusedTextBox')
local GetMouseDelta = insGet(uis, 'GetMouseDelta')
local IsMouseButtonPressed = insGet(uis, 'IsMouseButtonPressed')
local IsKeyDown = insGet(uis, 'IsKeyDown')
local Inverse = cfGet(cf_0, 'Inverse')
local Lerp = cfGet(cf_0, 'Lerp')
local guiTheme = {
guiTitle = 'patchma hub',
windowTitleColor = c3(0, 0, 1),
windowTopColor = c3(0, 0, 0),
windowBottomColor = c3(0, 0, 0.584314),
windowMinimizedSize = { X = 220, Y = 22 },
windowRegularSize = { X = 220, Y = 290 },
buttonsTextColor = c3(0.0941177, 0.317647, 0.878431),
labelsTextColor = c3(0.560784, 0.560784, 0.560784),
listTopColor = c3(0, 0, 0),
listBottomColor = c3(0.0705882, 0.0705882, 0.0705882),
}
local accessorylimbs = {
{
meshid = '117287001096396',
textureid = '',
C0 = cf_0,
Name = 'Left Arm',
},
{
meshid = '117287001096396',
textureid = '',
C0 = cf_0,
Name = 'Right Arm',
},
{
meshid = '90736849096372',
textureid = '',
C0 = angles(0, 0, 1.5707963267948966),
Name = 'Left Arm',
},
{
meshid = '105141400603933',
textureid = '',
C0 = angles(0, 0, 1.5707963267948966),
Name = 'Right Arm',
},
{
meshid = '11263221350',
textureid = '11263219250',
C0 = angles(1.5707963267948966, 0, 1.5707963267948966),
Name = 'Left Arm',
},
{
meshid = '11159370334',
textureid = '11159284657',
C0 = angles(-1.5707963267948966, 0, 1.5707963267948966),
Name = 'Right Arm',
},
{
meshid = '14255522247',
textureid = '',
C0 = angles(1.5707963267948966, 0, 1.5707963267948966),
Name = 'Left Arm',
},
{
meshid = '14255522247',
textureid = '',
C0 = angles(-1.5707963267948966, 0, 1.5707963267948966),
Name = 'Right Arm',
},
{
meshid = '17374767929',
textureid = '',
C0 = angles(1.5707963267948966, 0, 1.5707963267948966),
Name = 'Left Arm',
},
{
meshid = '17374767929',
textureid = '',
C0 = angles(-1.5707963267948966, 0, 1.5707963267948966),
Name = 'Right Arm',
},
{
meshid = '12344207333',
textureid = '',
C0 = angles(2, 0, 0),
Name = 'Left Arm',
},
{
meshid = '12344206657',
textureid = '',
C0 = angles(2, 0, 0),
Name = 'Right Arm',
},
{
meshid = '13831073174',
textureid = '',
C0 = cf(0.017, 0, -0.23) * angles(
-1.4835298641951802,
-0.15707963267948966,
2.199114857512855
),
Name = 'Left Arm',
},
{
meshid = '13839903766',
textureid = '',
C0 = cf(0, -0.62, -0.01) * angles(
1.6580627893946132,
0.15707963267948966,
-2.199114857512855
),
Name = 'Right Arm',
},
{
meshid = '121304376791439',
textureid = '',
C0 = cf_0,
Name = 'Left Leg',
},
{
meshid = '121304376791439',
textureid = '',
C0 = cf_0,
Name = 'Right Leg',
},
{
meshid = '11159370334',
textureid = '11159285454',
C0 = angles(1.5707963267948966, 0, 1.5707963267948966),
Name = 'Left Leg',
},
{
meshid = '12652772399',
textureid = '12652775021',
C0 = cf(0, -0.125, 0),
Name = 'Right Leg',
},
{
meshid = '14768684979',
textureid = '',
C0 = angles(0, 0, 1.5707963267948966),
Name = 'Left Leg',
},
{
meshid = '14768684979',
textureid = '',
C0 = angles(0, 0, 1.5707963267948966),
Name = 'Right Leg',
},
{
meshid = '17387586286',
textureid = '',
C0 = angles(1.5707963267948966, 0, 1.5707963267948966),
Name = 'Left Leg',
},
{
meshid = '17387586286',
textureid = '',
C0 = angles(-1.5707963267948966, 0, 1.5707963267948966),
Name = 'Right Leg',
},
{
meshid = '14768666349',
textureid = '',
C0 = cf_0,
Name = 'Torso',
},
{
meshid = '14241018198',
textureid = '',
C0 = cf_0,
Name = 'Torso',
},
{
meshid = '13421774668',
textureid = '',
C0 = cf_0,
Name = 'Torso',
},
{
meshid = '110684113028749',
textureid = '',
C0 = cf_0,
Name = 'Torso',
},
{
meshid = '127552124837034',
textureid = '',
C0 = angles(0, 0, 1.5707963267948966),
Name = 'Torso',
},
{
meshid = '4324138105',
textureid = '4324138210',
C0 = angles(-1.6144295580947547, 1.5707963267948966, 0) * cf(
-0.125,
0.3,
0
),
Name = 'Left Arm',
},
{
meshid = '4154474745',
textureid = '4154474807',
C0 = angles(1.5271630954950384, -1.5707963267948966, 0) * cf(
-0.125,
-0.3,
0
),
Name = 'Left Arm',
},
{
meshid = '3030546036',
textureid = '3650191503',
C0 = angles(1.5271630954950384, 1.5707963267948966, 0) * cf(
0.125,
-0.3,
0
),
Name = 'Right Arm',
},
{
meshid = '3030546036',
textureid = '3443321249',
C0 = angles(-1.6144295580947547, -1.5707963267948966, 0) * cf(
0.125,
0.3,
0
),
Name = 'Right Arm',
},
{
meshid = '3030546036',
textureid = '3360974849',
C0 = angles(1.5271630954950384, 1.5707963267948966, 0) * cf(
-0.125,
-0.35,
0
),
Name = 'Left Leg',
},
{
meshid = '3030546036',
textureid = '3360978739',
C0 = angles(-1.6144295580947547, -1.5707963267948966, 0) * cf(
-0.125,
0.3,
0
),
Name = 'Left Leg',
},
{
meshid = '3030546036',
textureid = '3033898741',
C0 = angles(1.5271630954950384, -1.5707963267948966, 0) * cf(
0.125,
-0.35,
0
),
Name = 'Right Leg',
},
{
meshid = '3030546036',
textureid = '3409604993',
C0 = angles(-1.6144295580947547, 1.5707963267948966, 0) * cf(
0.125,
0.3,
0
),
Name = 'Right Leg',
},
{
meshid = '4819720316',
textureid = '4819722776',
C0 = angles(0, 0, 0.2617993877991494),
Name = 'Torso',
},
}
local gp = function(p, n, cl)
for i, v in next, GetChildren(p) do
if IsA(v, cl) and (insGet(v, 'Name') == n) then
return v
end
end
return nil
end
local timegp = function(p, n, c, t)
t = osclock() + t
while t > osclock() do
for i, v in next, GetChildren(p) do
if IsA(v, c) and (insGet(v, 'Name') == n) then
return v
end
end
Wait(preanimation)
end
return nil
end
local makeplaceholder = function(v)
if not insGet(v, 'Archivable') then
insSet(v, 'Archivable', true)
end
v = Clone(v)
for i, v in next, GetChildren(v) do
if IsA(v, 'SpecialMesh') then
insSet(v, 'Name', rs())
ClearAllChildren(v)
else
Destroy(v)
end
end
insSet(v, 'Name', rs())
insSet(v, 'Anchored', true)
insSet(v, 'CanCollide', false)
insSet(v, 'Transparency', 0.25)
return v
end
local emptyfunction = function() end
local i1 = i('Frame')
local i2 = i('Frame')
local i3 = i('Frame')
local i4 = i('ScrollingFrame')
local i5 = i('UIListLayout')
local i6 = i('UIGradient')
local i7 = i('TextBox')
local i8 = i('TextButton')
local i9 = i('UIGradient')
local i10 = i('ScreenGui')
insSet(i1, 'AnchorPoint', v2(0.5, 0))
insSet(i1, 'Active', true)
insSet(i1, 'BorderSizePixel', 0)
insSet(i1, 'ClipsDescendants', true)
insSet(
i1,
'Position',
u2(0.5, 0, 0.5, guiTheme.windowRegularSize.Y / -2)
)
insSet(
i1,
'Size',
u2(0, guiTheme.windowRegularSize.X, 0, guiTheme.windowRegularSize.Y)
)
insSet(i1, 'Name', rs())
insSet(i1, 'Parent', i10)
insSet(i2, 'BackgroundColor3', c3(1, 1, 1))
insSet(i2, 'BorderSizePixel', 0)
insSet(
i2,
'Size',
u2(0, guiTheme.windowRegularSize.X, 0, guiTheme.windowRegularSize.Y)
)
insSet(i2, 'Name', rs())
insSet(i2, 'Parent', i1)
insSet(i3, 'BackgroundColor3', c3(1, 1, 1))
insSet(i3, 'BorderSizePixel', 0)
insSet(i3, 'Position', u2(0, 5, 0, guiTheme.windowMinimizedSize.Y - 2))
insSet(
i3,
'Size',
u2(
1,
-10,
0,
guiTheme.windowRegularSize.Y
- guiTheme.windowMinimizedSize.Y
- 3
)
)
insSet(i3, 'Name', rs())
insSet(i3, 'Parent', i2)
insSet(i4, 'Active', true)
insSet(i4, 'BackgroundTransparency', 1)
insSet(i4, 'BorderSizePixel', 0)
insSet(i4, 'Size', u2(1, -3, 1, 0))
insSet(i4, 'AutomaticCanvasSize', e.AutomaticSize.Y)
insSet(i4, 'CanvasSize', u2(0, 0, 0, 0))
insSet(i4, 'ScrollBarThickness', 7)
insSet(i4, 'Name', rs())
insSet(i4, 'Parent', i3)
insSet(i5, 'Name', rs())
insSet(i5, 'Parent', i4)
insSet(i5, 'SortOrder', e.SortOrder.LayoutOrder)
insSet(i6, 'Name', rs())
insSet(i6, 'Parent', i3)
insSet(
i6,
'Color',
cs({
csk(0, guiTheme.listTopColor),
csk(1, guiTheme.listBottomColor),
})
)
insSet(i6, 'Rotation', 90)
insSet(i7, 'Font', e.Font.SourceSans)
insSet(i7, 'FontSize', e.FontSize.Size18)
insSet(i7, 'ClearTextOnFocus', false)
insSet(i7, 'Text', guiTheme.guiTitle)
insSet(i7, 'TextColor3', guiTheme.windowTitleColor)
insSet(i7, 'TextSize', 16)
insSet(i7, 'AnchorPoint', v2(0.5, 0))
insSet(i7, 'BackgroundTransparency', 1)
insSet(
i7,
'Position',
u2(0.5, 0, 0, guiTheme.windowMinimizedSize.Y / 2)
)
insSet(i7, 'Name', rs())
insSet(i7, 'Parent', i2)
insSet(i8, 'AnchorPoint', v2(1, 0))
insSet(i8, 'BackgroundTransparency', 1)
insSet(i8, 'Position', u2(1, 0, 0, 0))
insSet(i8, 'Size', u2(0, 40, 0, guiTheme.windowMinimizedSize.Y))
insSet(i8, 'Name', rs())
insSet(i8, 'Parent', i2)
insSet(i8, 'Font', e.Font.SourceSans)
insSet(i8, 'FontSize', e.FontSize.Size18)
insSet(i8, 'Text', '-')
insSet(i8, 'TextColor3', c3(1, 1, 1))
insSet(i8, 'TextSize', 16)
insSet(i9, 'Name', rs())
insSet(i9, 'Parent', i2)
insSet(
i9,
'Color',
cs({
csk(0, guiTheme.windowTopColor),
csk(1, guiTheme.windowBottomColor),
})
)
insSet(i9, 'Rotation', 90)
insSet(i10, 'ZIndexBehavior', e.ZIndexBehavior.Sibling)
insSet(i10, 'IgnoreGuiInset', true)
insSet(i10, 'ResetOnSpawn', false)
insSet(i10, 'DisplayOrder', 2147483647)
insSet(i10, 'Name', rs())
local guimin = false
local minloop = false
local i1X = guiTheme.windowRegularSize.X
local i1Y = guiTheme.windowRegularSize.Y
local i1Xdest = i1X
local i1Ydest = i1Y
Connect(insGet(i8, 'MouseButton1Click'), function()
guimin = not guimin
if guimin then
i1Xdest = guiTheme.windowMinimizedSize.X
i1Ydest = guiTheme.windowMinimizedSize.Y
else
i1Xdest = guiTheme.windowRegularSize.X
i1Ydest = guiTheme.windowRegularSize.Y
end
if minloop then
return
end
minloop = true
insSet(i3, 'Visible', true)
sine = osclock()
local lastsine = sine
while true do
sine = osclock()
local deltaTime = (sine - lastsine) * 10
lastsine = sine
local difX = i1Xdest - i1X
local difY = i1Ydest - i1Y
if (abs(difY) <= 1) and (abs(difX) <= 1) then
i1X = i1Xdest
i1Y = i1Ydest
insSet(i1, 'Size', u2(0, i1X, 0, i1Y))
break
end
i1X = i1X + difX * deltaTime
i1Y = i1Y + difY * deltaTime
insSet(i1, 'Size', u2(0, i1X, 0, i1Y))
twait()
end
insSet(i3, 'Visible', not guimin)
minloop = false
end)
local Draggable = function(window, obj)
local MB1enum = e.UserInputType.MouseButton1
local TOUCHenum = e.UserInputType.Touch
obj = obj or window
local activeEntered = 0
local mouseStart = nil
local dragStart = nil
local inputbegancon = nil
local rendersteppedcon = nil
local inputendedcon = nil
local inputendedf = function(a)
a = insGet(a, 'UserInputType')
if (a == MB1enum) or (a == TOUCHenum) then
Disconnect(rendersteppedcon)
Disconnect(inputendedcon)
end
end
local rendersteppedf = function()
local off = GetMouseLocation(uis) - mouseStart
insSet(window, 'Position', dragStart + u2(0, off.X, 0, off.Y))
end
local inputbeganf = function(a)
a = insGet(a, 'UserInputType')
if
((a == MB1enum) or (a == TOUCHenum))
and (activeEntered == 0)
and not GetFocusedTextBox(uis)
then
mouseStart = GetMouseLocation(uis)
dragStart = insGet(window, 'Position')
if rendersteppedcon then
Disconnect(rendersteppedcon)
end
rendersteppedcon = Connect(renderstepped, rendersteppedf)
if inputendedcon then
Disconnect(inputendedcon)
end
inputendedcon = Connect(
insGet(uis, 'InputEnded'),
inputendedf
)
end
end
Connect(insGet(obj, 'MouseEnter'), function()
if inputbegancon then
Disconnect(inputbegancon)
end
inputbegancon = Connect(insGet(uis, 'InputBegan'), inputbeganf)
end)
Connect(insGet(obj, 'MouseLeave'), function()
Disconnect(inputbegancon)
end)
local ondes = function(d)
if IsA(d, 'GuiObject') then
local thisEntered = false
local thisAdded = false
local con0 = Connect(insGet(d, 'MouseEnter'), function()
thisEntered = true
if not thisAdded and insGet(d, 'Active') then
activeEntered = activeEntered + 1
thisAdded = true
end
end)
local con1 = Connect(insGet(d, 'MouseLeave'), function()
thisEntered = false
if thisAdded then
activeEntered = activeEntered - 1
thisAdded = false
end
end)
local con2 = Connect(
GetPropertyChangedSignal(d, 'Active'),
function()
if thisEntered then
if thisAdded and not insGet(d, 'Active') then
activeEntered = activeEntered - 1
thisAdded = false
elseif
insGet(d, 'Active') and not thisAdded
then
activeEntered = activeEntered + 1
thisAdded = true
end
end
end
)
local con3 = nil
con3 = Connect(insGet(d, 'AncestryChanged'), function()
if not IsDescendantOf(d, window) then
if thisAdded then
activeEntered = activeEntered - 1
end
Disconnect(con0)
Disconnect(con1)
Disconnect(con2)
Disconnect(con3)
end
end)
end
end
Connect(insGet(window, 'DescendantAdded'), ondes)
for i, v in next, GetDescendants(window) do
ondes(v)
end
end
local btn = function(txt, f)
local i1 = i('TextBox')
local i2 = i('TextButton')
insSet(i1, 'Font', e.Font.SourceSans)
insSet(i1, 'FontSize', e.FontSize.Size14)
insSet(i1, 'Text', txt)
insSet(i1, 'ClearTextOnFocus', false)
insSet(i1, 'Position', u2(0.5, 0, 0.5, 0))
insSet(i1, 'TextColor3', guiTheme.buttonsTextColor)
insSet(i1, 'Name', rs())
insSet(i1, 'Parent', i2)
insSet(i2, 'BackgroundTransparency', 1)
insSet(i2, 'TextTransparency', 1)
insSet(i2, 'Size', u2(1, 0, 0, 14))
insSet(i2, 'Name', rs())
if f then
Connect(insGet(i2, 'MouseButton1Click'), f)
end
insSet(i2, 'Parent', i4)
return i1
end
local lbl = function(txt)
local i1 = i('TextBox')
local i2 = i('Frame')
insSet(i1, 'Font', e.Font.SourceSans)
insSet(i1, 'FontSize', e.FontSize.Size14)
insSet(i1, 'Text', txt)
insSet(i1, 'ClearTextOnFocus', false)
insSet(i1, 'TextColor3', guiTheme.labelsTextColor)
insSet(i1, 'Position', u2(0.5, 0, 0.5))
insSet(i1, 'BackgroundTransparency', 1)
insSet(i1, 'Name', rs())
insSet(i1, 'Parent', i2)
insSet(i2, 'Size', u2(1, 0, 0, 14))
insSet(i2, 'BackgroundTransparency', 1)
insSet(i2, 'Name', rs())
insSet(i2, 'Parent', i4)
return i1
end
Draggable(i1)
lbl('by MyWorld')
lbl('discord.gg/QMy5f6DrbH')
local allowshiftlock = nil
local ctrltp = nil
local placeholders = nil
local clickfling = nil
local highlightflingtargets = nil
local discharscripts = nil
local flingchangestate = nil
local respawntp = nil
local breakjointsmethod = nil
local simrad = false
local hidedeatheffect = nil
local c = nil
local stopreanimate = function()
if c then
c = nil
if replicatesignal then
replicatesignal(cdsb)
end
return true
end
return false
end
local reanimate = function()
--[[
FDless reanimate by MyWorld
optimize the optimized
]]
local novoid = true --prevents parts from going under workspace.FallenPartsDestroyHeight if you control them
local speedlimit = 3000 --makes your parts move slower if the magnitude of their velocity is higher than this
local retVelTime = 0.51 --time that claimed parts have velocity to reclaim in case u lose them
local walkSpeed = 16 --your walkspeed (can be changed at runtime)
local jumpPower = 50 --your jump power (can be changed at runtime)
local gravity = 196.2 --how fast the characters velocity decreases while falling (can be changed at runtime)
local ctrlclicktp = ctrltp --makes you teleport where u point ur mouse cursor at when click and hold ctrl down
local clickfling = clickfling --makes you fling the person you clicked when its available to do so
local flingvel = v3(15000, 16000, 15000) --the rotation velocity that ur character will have while flinging
if stopreanimate() then
return
end
c = insGet(lp, 'Character')
if not (c and IsDescendantOf(c, ws)) then
return
end
local rootpart = gp(c, 'HumanoidRootPart', 'BasePart')
or gp(c, 'Torso', 'BasePart')
or gp(c, 'UpperTorso', 'BasePart')
or timegp(
c,
'HumanoidRootPart',
'BasePart',
0.5
)
or FindFirstChildWhichIsA(c, 'BasePart')
if not rootpart then
return
end
local cam = nil
--theres a way to have ws.currentcamera nil on heartbeat and still have the game run normally
local refcam = function()
local newcam = insGet(ws, 'CurrentCamera')
while not newcam do
Wait(GetPropertyChangedSignal(ws, 'CurrentCamera'))
newcam = insGet(ws, 'CurrentCamera')
end
cam = newcam
end
refcam()
local camcf = insGet(cam, 'CFrame')
local enumCamS = e.CameraType.Scriptable
local camt = insGet(cam, 'CameraType')
local camcon0 = nil
local camcon1 = nil
local camcon2 = nil
local onnewcamera = function()
refcam()
if camcon0 then
Disconnect(camcon0)
Disconnect(camcon1)
camcon0 = nil
end
if not c then
if insGet(cam, 'CameraType') == enumCamS then
insSet(cam, 'CameraType', camt)
end
return Disconnect(camcon2)
end
camcon0 = Connect(
GetPropertyChangedSignal(cam, 'CFrame'),
function()
if insGet(cam, 'CFrame') ~= camcf then
insSet(cam, 'CFrame', camcf)
end
end
)
camcon1 = Connect(
GetPropertyChangedSignal(cam, 'CameraType'),
function()
if insGet(cam, 'CameraType') ~= enumCamS then
insSet(cam, 'CameraType', enumCamS)
end
end
)
if insGet(cam, 'CameraType') ~= enumCamS then
insSet(cam, 'CameraType', enumCamS)
end
if insGet(cam, 'CFrame') ~= camcf then
insSet(cam, 'CFrame', camcf)
end
end
camcon2 = Connect(
GetPropertyChangedSignal(ws, 'CurrentCamera'),
onnewcamera
)
onnewcamera()
local velYdelta = insGet(ws, 'Gravity') * 0.025
Connect(GetPropertyChangedSignal(ws, 'Gravity'), function()
velYdelta = insGet(ws, 'Gravity') * 0.025
end)
local fpdh = insGet(ws, 'FallenPartsDestroyHeight')
novoid = novoid and (fpdh + 1)
local Yvel = 0
local cfr = insGet(rootpart, 'CFrame')
local pos = cfGet(cfr, 'Position')
cfr = cfl(pos, pos + cfGet(cfr, 'LookVector') * v3_101)
local primarypart = nil
local shiftlock = false
local firstperson = false
local xzvel = v3_0
local v3_0150 = v3_010 * 1.5
local camcfLV = cfGet(camcf, 'LookVector')
local camrot = cfl(v3_0, camcfLV)
local camcfRV = cfGet(camrot, 'RightVector')
local cammag = -v3Get(
(cfGet(camcf, 'Position') - (pos + v3_0150)),
'Magnitude'
)
local R6parts = {
head = { Name = 'Head' },
torso = { Name = 'Torso' },
root = { Name = 'HumanoidRootPart' },
leftArm = { Name = 'Left Arm' },
rightArm = { Name = 'Right Arm' },
leftLeg = { Name = 'Left Leg' },
rightLeg = { Name = 'Right Leg' },
}
rootpart = R6parts.root
local cframes = {}
for i, v in next, R6parts do
cframes[v] = cfr
end
local joints = {
{
Name = 'Neck',
Part0 = R6parts.torso,
Part1 = R6parts.head,
C0 = cf(0, 1, 0, -1, 0, 0, 0, 0, 1, 0, 1, -0),
C1 = cf(0, -0.5, 0, -1, 0, 0, 0, 0, 1, 0, 1, -0),
},
{
Name = 'RootJoint',
Part0 = rootpart,
Part1 = R6parts.torso,
C0 = cf(0, 0, 0, -1, 0, 0, 0, 0, 1, 0, 1, -0),
C1 = cf(0, 0, 0, -1, 0, 0, 0, 0, 1, 0, 1, -0),
},
{
Name = 'Right Shoulder',
Part0 = R6parts.torso,
Part1 = R6parts.rightArm,
C0 = cf(1, 0.5, 0, 0, 0, 1, 0, 1, -0, -1, 0, 0),
C1 = cf(-0.5, 0.5, 0, 0, 0, 1, 0, 1, -0, -1, 0, 0),
},
{
Name = 'Left Shoulder',
Part0 = R6parts.torso,
Part1 = R6parts.leftArm,
C0 = cf(-1, 0.5, 0, 0, 0, -1, 0, 1, 0, 1, 0, 0),
C1 = cf(0.5, 0.5, 0, 0, 0, -1, 0, 1, 0, 1, 0, 0),
},
{
Name = 'Right Hip',
Part0 = R6parts.torso,
Part1 = R6parts.rightLeg,
C0 = cf(1, -1, 0, 0, 0, 1, 0, 1, -0, -1, 0, 0),
C1 = cf(0.5, 1, 0, 0, 0, 1, 0, 1, -0, -1, 0, 0),
},
{
Name = 'Left Hip',
Part0 = R6parts.torso,
Part1 = R6parts.leftLeg,
C0 = cf(-1, -1, 0, 0, 0, -1, 0, 1, 0, 1, 0, 0),
C1 = cf(-0.5, 1, 0, 0, 0, -1, 0, 1, 0, 1, 0, 0),
},
}
local refreshedjoints = {}
local refreshjointsI = nil
refreshjointsI = function(part)
tinsert(refreshedjoints, part)
for i, v in next, joints do
local part0 = v.Part0
local part1 = v.Part1
if part1 and (part0 == part) then
cframes[part1] = cfMul(
cframes[part],
cfMul(v.C0, Inverse(v.C1))
)
if not tfind(refreshedjoints, part1) then
refreshjointsI(part1)
end
elseif part0 and (part1 == part) then
cframes[part0] = cfMul(
cframes[part],
cfMul(v.C1, Inverse(v.C0))
)
if not tfind(refreshedjoints, part0) then
refreshjointsI(part0)
end
end
end
end
refreshjointsI(rootpart)
tclear(refreshedjoints)
local attachments = {
RightShoulderAttachment = {
R6parts.rightArm,
cf(0, 1, 0, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
RightGripAttachment = {
R6parts.rightArm,
cf(0, -1, 0, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
LeftFootAttachment = {
R6parts.leftLeg,
cf(0, -1, 0, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
LeftShoulderAttachment = {
R6parts.leftArm,
cf(0, 1, 0, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
LeftGripAttachment = {
R6parts.leftArm,
cf(0, -1, 0, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
RootAttachment = {
rootpart,
cf(0, 0, 0, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
RightFootAttachment = {
R6parts.rightLeg,
cf(0, -1, 0, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
NeckAttachment = {
R6parts.torso,
cf(0, 1, 0, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
BodyFrontAttachment = {
R6parts.torso,
cf(0, 0, -0.5, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
BodyBackAttachment = {
R6parts.torso,
cf(0, 0, 0.5, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
LeftCollarAttachment = {
R6parts.torso,
cf(-1, 1, 0, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
RightCollarAttachment = {
R6parts.torso,
cf(1, 1, 0, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
WaistFrontAttachment = {
R6parts.torso,
cf(0, -1, -0.5, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
WaistCenterAttachment = {
R6parts.torso,
cf(0, -1, 0, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
WaistBackAttachment = {
R6parts.torso,
cf(0, -1, 0.5, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
HairAttachment = {
R6parts.head,
cf(0, 0.6, 0, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
HatAttachment = {
R6parts.head,
cf(0, 0.6, 0, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
FaceFrontAttachment = {
R6parts.head,
cf(0, 0, -0.6, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
FaceCenterAttachment = {
R6parts.head,
cf(0, 0, 0, 1, 0, 0, 0, 1, 0, 0, 0, 1),
},
}
local getPart = function(name, blacklist)
if blacklist then
for i, v in next, cframes do
if (i.Name == name) and not tfind(blacklist, i) then
return i
end
end
else
for i, v in next, cframes do
if i.Name == name then
return i
end
end
end
return nil
end
local getJoint = function(name)
for i, v in next, joints do
if v.Name == name then
return v
end
end
return { C0 = cf_0, C1 = cf_0 }
end
local getPartFromMesh = function(m, t, blacklist)
if blacklist then
for v, _ in next, cframes do
if
v.m
and (not tfind(blacklist, v))
and sfind(v.m, m)
and sfind(v.t, t)
then
return v
end
end
else
for v, _ in next, cframes do
if v.m and sfind(v.m, m) and sfind(v.t, t) then
return v
end
end
end
local p = { m = m, t = t }
cframes[p] = cfr
local j = { C0 = cf_0, C1 = cf_0, Part0 = p }
p.j = j
return p
end
local getPartJoint = function(p)
if cframes[p] then
local j = p.j
if j then
return j
end
for i, v in next, joints do
if v.Part0 == p then
return v
end
end
for i, v in next, joints do
if v.Part1 == p then
return v
end
end
end
return nil
end
local getAccWeldFromMesh = function(m, t)
return getPartJoint(getPartFromMesh(m, t))
end
local raycastparams = rp()
raycastparams.FilterType = e.RaycastFilterType.Exclude
raycastparams.RespectCanCollide = true
local rayfilter = {}
local characters = {}
local refreshrayfilter = function()
tclear(rayfilter)
for i, v in next, characters do
tinsert(rayfilter, v)
end
raycastparams.FilterDescendantsInstances = rayfilter
end
local flingtable = {}
local rootparts = {}
for i, v in next, accessorylimbs do
v.p = getPart(v.Name)
end
local makePartCons = function(p, t)
if (t.p == p) and insGet(p, 'Anchored') then
t.p = nil
end
local con0 = Connect(
GetPropertyChangedSignal(p, 'Anchored'),
function()
if insGet(p, 'Anchored') then
if t.p == p then
t.c = nil
t.p = nil
end
elseif not t.p then
t.p = p
end
end
)
local con1 = nil
con1 = Connect(insGet(p, 'AncestryChanged'), function()
if not IsDescendantOf(p, ws) then
Disconnect(con0)
Disconnect(con1)
if t.p == p then
t.p = nil
end
end
end)
end
local ondes = nil
ondes = function(v)
if c and IsA(v, 'Attachment') and IsDescendantOf(c, ws) then
local v1 = attachments[insGet(v, 'Name')]
if v1 then
local p = insGet(v, 'Parent')
if insGet(p, 'Parent') ~= c then
local meshid = nil
local textureid = nil
if IsA(p, 'MeshPart') then
meshid = insGet(p, 'MeshId')
textureid = insGet(p, 'TextureID')
elseif IsA(p, 'BasePart') then
local sm = FindFirstChildOfClass(
p,
'SpecialMesh'
)
if sm then
meshid = insGet(sm, 'MeshId')
textureid = insGet(sm, 'TextureId')
else
return
end
else
return
end
for i, _ in next, cframes do
if (meshid == i.m) and (textureid == i.t) then
local p1 = i.p
if p1 and IsDescendantOf(p1, c) then
if p1 == p then
return
end
else
i.p = p
makePartCons(p, i)
return
end
else
local j = i.j
if
j
and sfind(meshid, i.m)
and sfind(textureid, i.t)
then
i.m = meshid
i.t = textureid
i.l = insGet(p, 'Position')
i.p = p
makePartCons(p, i)
i.j = nil
i.Name = insGet(p, 'Name')
j.C0 = insGet(v, 'CFrame')
j.C1 = v1[2]
j.Part1 = v1[1]
tinsert(joints, j)
return
end
end
end
for i, l in next, accessorylimbs do
if
l.p
and sfind(meshid, l.meshid)
and sfind(textureid, l.textureid)
then
local t = {
Name = insGet(p, 'Name'),
l = insGet(p, 'Position'),
m = meshid,
t = textureid,
p = p,
}
makePartCons(p, t)
if placeholders then
t.v = makeplaceholder(p)
t.b = false
end
cframes[t] = insGet(p, 'CFrame')
tinsert(joints, {
Part0 = t,
Part1 = l.p,
C0 = l.C0,
C1 = cf_0,
})
l.p = nil
return
end
end
local t = {
Name = insGet(p, 'Name'),
l = insGet(p, 'Position'),
m = meshid,
t = textureid,
p = p,
}
makePartCons(p, t)
if placeholders then
t.v = makeplaceholder(p)
t.b = false
end
cframes[t] = insGet(p, 'CFrame')
tinsert(joints, {
Part0 = t,
Part1 = v1[1],
C0 = insGet(v, 'CFrame'),
C1 = v1[2],
})
end
end
end
end
local simradv = 0
local charcons = {}
local enumH = e.CoreGuiType.Health
local onplayer = function(v)
simradv = simradv + 1000
local islp = v == lp
local lastc = nil
local oncharacter = function()
local newc = insGet(v, 'Character')
if c and newc and (newc ~= lastc) then
lastc = newc
characters[v] = newc
refreshrayfilter()
if islp then
if discharscripts then
Connect(
insGet(newc, 'DescendantAdded'),
discharscripts
)
for i, v in next, GetDescendants(newc) do
if IsA(v, 'Script') then
insSet(v, 'Disabled', true)
end
end
end
local hrp = timegp(
newc,
'HumanoidRootPart',
'BasePart',
10
)
if not (hrp and c and IsDescendantOf(newc, ws)) then
return
end
c = newc
local fi, fv = next(flingtable)
if fi then
if replicatesignal and not pdloadedtime then
replicatesignal(cdsb)
pdloadedtime = osclock() + rst
end
if flingchangestate == 3 then
local hum = FindFirstChildOfClass(
c,
'Humanoid'
)
if hum then
insGet(hum, 'ChangeState')(
hum,
e.HumanoidStateType.Physics
)
insGet(hum, 'SetStateEnabled')(
hum,
e.HumanoidStateType.Seated,
false
)
end
elseif flingchangestate == 1 then
local hum = FindFirstChildOfClass(
c,
'Humanoid'
)
if hum then
insGet(hum, 'ChangeState')(
hum,
e.HumanoidStateType.Physics
)
end
elseif flingchangestate == 2 then
local hum = FindFirstChildOfClass(
c,
'Humanoid'
)
if hum then
insGet(hum, 'SetStateEnabled')(
hum,
e.HumanoidStateType.Seated,
false
)
end
end
for i, v in next, tclone(flingtable) do
if not c then
return
end
local startpos = insGet(i, 'Position')
local stoptime = sine + 3
while true do
twait()
if sine > stoptime then
break
end
if
insGet(i, 'Anchored')
or not IsDescendantOf(i, ws)
then
break
end
if
v3Get(
(
startpos
- insGet(i, 'Position')
),
'Magnitude'
) > 200
then
break
end
local tcf = cfAdd(
insGet(i, 'CFrame'),
insGet(i, 'AssemblyLinearVelocity')
* (sin(sine * 15) + 1)
)
if
novoid
and (cfGet(tcf, 'Y') < novoid)
then
tcf = cfAdd(
tcf,
v3_010
* (novoid - cfGet(tcf, 'Y'))
)
end
insSet(hrp, 'CFrame', tcf)
insSet(
hrp,
'AssemblyLinearVelocity',
insGet(i, 'AssemblyLinearVelocity')
* v3_101
* 75
)
insSet(
hrp,
'AssemblyAngularVelocity',
flingvel
)
end
if v then
Destroy(v)
end
flingtable[i] = nil
end
insSet(hrp, 'AssemblyLinearVelocity', v3_0)
insSet(hrp, 'AssemblyAngularVelocity', v3_0)
insSet(hrp, 'CFrame', cfr)
twait(0.17)
end
if respawntp == 1 then
local startpos = pos
+ v3(mrandom(-32, 32), 0, mrandom(-32, 32))
local dir = nil
local poscheck = true
while poscheck do
poscheck = false
for i, v in next, rootparts do
local diff = (
startpos
- insGet(v, 'Position')
) * v3_101
if v3Get(diff, 'Magnitude') < 10 then
poscheck = true
dir = dir
or (v3Get(diff, 'Unit') * 3)
startpos = startpos + dir
end
end
local diff = (startpos - pos) * v3_101
if v3Get(diff, 'Magnitude') < 10 then
poscheck = true
dir = dir or (v3Get(diff, 'Unit') * 3)
startpos = startpos + dir
end
end
startpos = cfAdd(
cfGet(cfr, 'Rotation'),
startpos
)
insSet(hrp, 'CFrame', startpos)
insSet(hrp, 'AssemblyLinearVelocity', v3_0)
insSet(hrp, 'AssemblyAngularVelocity', v3_0)
twait(0.17)
elseif respawntp == 2 then
insSet(
hrp,
'CFrame',
cfAdd(
cfr,
cfGet(cfr, 'RightVector') * 3.5
- cfGet(cfr, 'LookVector') * 3.5
)
)
insSet(hrp, 'AssemblyLinearVelocity', v3_0)
insSet(hrp, 'AssemblyAngularVelocity', v3_0)
twait(0.17)
elseif respawntp == 3 then
local t = osclock() + 0.17
if pdloadedtime and pdloadedtime > t then
t = pdloadedtime
end
local startcf = cfAdd(
cfMul(
cfGet(cfr, 'Rotation'),
angles(1.5707963267948966, 0, 0)
),
pos * v3_101
+ v3_010
* min(
fpdh + 30,
v3Get(pos, 'Y') - 5
)
)
while twait() do
insSet(hrp, 'CFrame', startcf)
insSet(hrp, 'AssemblyLinearVelocity', v3_0)
insSet(hrp, 'AssemblyAngularVelocity', v3_0)
if osclock() > t then
break
end
end
end
if newc ~= c then
return
end
primarypart = insGet(newc, 'PrimaryPart') or hrp
if
hidedeatheffect
and GetCoreGuiEnabled(sg, enumH)
then
SetCoreGuiEnabled(sg, enumH, false)
end
if pdloadedtime then
if osclock() < pdloadedtime then
twait(pdloadedtime - osclock())
end
pdloadedtime = nil
end
if breakjointsmethod == 1 then
insGet(newc, 'BreakJoints')(newc)
local h = FindFirstChildOfClass(
newc,
'Humanoid'
)
if h then
insSet(h, 'Health', 0)
end
elseif breakjointsmethod == 2 then
local h = FindFirstChildOfClass(
newc,
'Humanoid'
)
if h then
insSet(h, 'Health', 0)
else
insGet(newc, 'BreakJoints')(newc)
end
else
insGet(newc, 'BreakJoints')(newc)
end
Connect(insGet(newc, 'DescendantAdded'), ondes)
for i, v in next, GetDescendants(newc) do
ondes(v)
end
else
local hrp = timegp(
newc,
'HumanoidRootPart',
'BasePart',
10
)
if hrp and c and IsDescendantOf(newc, ws) then
rootparts[v] = hrp
end
end
end
end
charcons[v] = Connect(
GetPropertyChangedSignal(v, 'Character'),
oncharacter
)
oncharacter()
end
Connect(insGet(plrs, 'PlayerRemoving'), function(v)
simradv = simradv - 1000
local charcon = charcons[v]
if charcon then
Disconnect(charcon)
end
characters[v] = nil
rootparts[v] = nil
end)
for i, v in next, GetPlayers(plrs) do
simradv = simradv + 1000
if v ~= lp then
tspawn(onplayer, v)
end
end
Connect(insGet(plrs, 'PlayerAdded'), onplayer)
onplayer(lp)
local setsimrad = emptyfunction
if simrad then
setsimrad = function()
local canset, _ = pcall(function()
insSet(lp, 'SimulationRadius', simradv)
end)
if canset then
setsimrad = function()
insSet(lp, 'SimulationRadius', simradv)
end
else
setsimrad = emptyfunction
end
end
end
local mradN05 = -0.008726646259971648
local KeyCode = e.KeyCode
local enumMB2 = e.UserInputType.MouseButton2
local enumMLCP = e.MouseBehavior.LockCurrentPosition
local enumMLC = (insGet(uis, 'TouchEnabled') and enumMLCP)
or e.MouseBehavior.LockCenter
local enumMD = e.MouseBehavior.Default
local enumMW = e.UserInputType.MouseWheel
local enumMM = e.UserInputType.MouseMovement
local mouseBehavior = nil
local lastMouseBehavior = insGet(uis, 'MouseBehavior')
Connect(GetPropertyChangedSignal(uis, 'MouseBehavior'), function()
if
mouseBehavior
and (insGet(uis, 'MouseBehavior') ~= mouseBehavior)
then
insSet(uis, 'MouseBehavior', mouseBehavior)
end
end)
local mode = 'default'
local defaultmode = {}
local modes = { default = defaultmode }
local lerpsIdle = emptyfunction
local lerpsWalk = emptyfunction
local lerpsJump = emptyfunction
local lerpsFall = emptyfunction
local addmode = function(key, mode)
if (type(key) ~= 'string') or (type(mode) ~= 'table') then
return
end
for i, v in next, mode do
if type(v) ~= 'function' then
mode[i] = nil
end
end
if key == 'default' then
defaultmode = mode
modes.default = mode
lerpsIdle = mode.idle or emptyfunction
lerpsWalk = mode.walk or emptyfunction
lerpsJump = mode.jump or emptyfunction
lerpsFall = mode.fall or emptyfunction
if mode.modeEntered then
mode.modeEntered()
end
elseif #key == 1 then
key = KeyCode[supper(ssub(key, 1, 1))]
modes[key] = mode
end
end
local keyW = KeyCode.W
local Wpressed = IsKeyDown(uis, keyW)
local keyA = KeyCode.A
local Apressed = IsKeyDown(uis, keyA)
local keyS = KeyCode.S
local Spressed = IsKeyDown(uis, keyS)
local keyD = KeyCode.D
local Dpressed = IsKeyDown(uis, keyD)
local keySpace = KeyCode.Space
local jumpingInput = IsKeyDown(uis, keySpace)
local FWmovement = 0
local RTmovement = 0
local isWalking = false
local refreshKeyboardMovement = function()
if Wpressed then
if Spressed then
if Dpressed then
if Apressed then
isWalking = false
else
FWmovement = 0
RTmovement = 1
isWalking = true
end
else
if Apressed then
FWmovement = 0
RTmovement = -1
isWalking = true
else
isWalking = false
end
end
else
FWmovement = 1
if Dpressed then
if Apressed then
RTmovement = 0
else
RTmovement = 1
end
else
if Apressed then
RTmovement = -1
else
RTmovement = 0
end
end
isWalking = true
end
else
if Spressed then
FWmovement = -1
if Dpressed then
if Apressed then
RTmovement = 0
else
RTmovement = 1
end
else
if Apressed then
RTmovement = -1
else
RTmovement = 0
end
end
isWalking = true
else
if Dpressed then
if Apressed then
isWalking = false
else
FWmovement = 0
RTmovement = 1
isWalking = true
end
else
if Apressed then
FWmovement = 0
RTmovement = -1
isWalking = true
else
isWalking = false
end
end
end
end
end
refreshKeyboardMovement()
local keyShift = KeyCode.LeftShift
Connect(insGet(uis, 'InputBegan'), function(a)
if insGet(gs, 'MenuIsOpen') or GetFocusedTextBox(uis) then
return
end
a = insGet(a, 'KeyCode')
if a == keyW then
Wpressed = true
refreshKeyboardMovement()
elseif a == keyA then
Apressed = true
refreshKeyboardMovement()
elseif a == keyS then
Spressed = true
refreshKeyboardMovement()
elseif a == keyD then
Dpressed = true
refreshKeyboardMovement()
elseif a == keySpace then
jumpingInput = true
elseif a == keyShift then
shiftlock = allowshiftlock and not shiftlock
elseif modes[a] then
if modes[mode].modeLeft then
modes[mode].modeLeft()
end
if mode == a then
mode = 'default'
else
mode = a
end
local modet = modes[mode]
lerpsIdle = modet.idle or defaultmode.idle or emptyfunction
lerpsWalk = modet.walk or defaultmode.walk or emptyfunction
lerpsJump = modet.jump or defaultmode.jump or emptyfunction
lerpsFall = modet.fall or defaultmode.fall or emptyfunction
if modes[mode].modeEntered then
modes[mode].modeEntered()
end
end
end)
Connect(insGet(uis, 'InputEnded'), function(a)
a = insGet(a, 'KeyCode')
if a == keyW then
Wpressed = false
refreshKeyboardMovement()
elseif a == keyA then
Apressed = false
refreshKeyboardMovement()
elseif a == keyS then
Spressed = false
refreshKeyboardMovement()
elseif a == keyD then
Dpressed = false
refreshKeyboardMovement()
elseif a == keySpace then
jumpingInput = false
end
end)
local thumbstickEndX = 0
local thumbstickStartY = 0
local thumbstickSizeMultiplier = 0
local jumpStartX = 0
local jumpStartY = 0
local jumpEndX = 0
local jumpEndY = 0
local thumbstickInputObject = nil
local jumpInputObject = nil
local cameraRotateInputObject = nil
local cameraZoomInputObject = nil
local thumbstickTouchStart = v3_0
local cameraZoomInputMagnitude = 0
Connect(insGet(uis, 'TouchStarted'), function(inputObject)
if insGet(gs, 'MenuIsOpen') or GetFocusedTextBox(uis) then
return
end
local touchPos = insGet(inputObject, 'Position')
local touchX = v3Get(touchPos, 'X')
local touchY = v3Get(touchPos, 'Y')
if
not thumbstickInputObject
and touchX < thumbstickEndX
and touchY > thumbstickStartY
then
thumbstickInputObject = inputObject
thumbstickTouchStart = insGet(inputObject, 'Position')
isWalking = false
elseif
not jumpInputObject
and touchY > jumpStartY
and touchX > jumpStartX
and touchX < jumpEndX
and touchY < jumpEndY
then
jumpInputObject = inputObject
jumpingInput = true
elseif not cameraRotateInputObject then
cameraRotateInputObject = inputObject
else
cameraZoomInputObject = inputObject
cameraZoomInputMagnitude = v3Get(
insGet(cameraRotateInputObject, 'Position')
- insGet(cameraZoomInputObject, 'Position'),
'Magnitude'
)
end
end)
Connect(insGet(uis, 'TouchMoved'), function(inputObject)
local touchPos = insGet(inputObject, 'Position')
local touchX = v3Get(touchPos, 'X')
local touchY = v3Get(touchPos, 'Y')
if inputObject == thumbstickInputObject then
local direction = insGet(inputObject, 'Position')
- thumbstickTouchStart
local directionMag = v3Get(direction, 'Magnitude')
/ thumbstickSizeMultiplier
if directionMag > 0.05 then
isWalking = true
direction = v3Get(direction, 'Unit')
* min(1, (directionMag - 0.05) / 0.95)
FWmovement = -v3Get(direction, 'Y')
RTmovement = v3Get(direction, 'X')
else
isWalking = false
end
elseif inputObject == jumpInputObject then
jumpingInput = touchY > jumpStartY
and touchX > jumpStartX
and touchX < jumpEndX
and touchY < jumpEndY
else
if cameraZoomInputObject then
local newMagnitude = v3Get(
insGet(cameraRotateInputObject, 'Position')
- insGet(cameraZoomInputObject, 'Position'),
'Magnitude'
)
cammag = cammag
+ (newMagnitude - cameraZoomInputMagnitude)
* 0.04
* (0.75 - cammag / 4)
cameraZoomInputMagnitude = newMagnitude
if cammag < 0 then
firstperson = false
else
cammag = 0
firstperson = true
end
elseif inputObject == cameraRotateInputObject then
local rotation = GetMouseDelta(uis) * mradN05
camcfLV = cfGet(
cfMul(camrot, angles(rotation.Y, rotation.X, 0)),
'LookVector'
)
camrot = cfl(v3_0, camcfLV)
camcfRV = cfGet(camrot, 'RightVector')
end
end
end)
Connect(insGet(uis, 'TouchEnded'), function(inputObject)
if inputObject == thumbstickInputObject then
thumbstickInputObject = nil
isWalking = false
elseif inputObject == jumpInputObject then
jumpInputObject = nil
jumpingInput = false
elseif inputObject == cameraRotateInputObject then
cameraRotateInputObject = nil
cameraZoomInputObject = nil
elseif inputObject == cameraZoomInputObject then
cameraZoomInputObject = nil
end
end)
local refreshTouchRegions = function()
local sX = insGet(mouse, 'ViewSizeX')
local sY = insGet(mouse, 'ViewSizeY')
local isSmallScreen = min(sX, sY) <= 500
sY = sY + insGet(gs, 'TopbarInset').Height
thumbstickEndX = sX * 0.4
thumbstickStartY = (sY + 0) * 0.333
if isSmallScreen then
thumbstickSizeMultiplier = 35
jumpStartX = sX - 95
jumpStartY = sY - 90
jumpEndX = jumpStartX + 70
jumpEndY = jumpStartY + 70
else
thumbstickSizeMultiplier = 60
jumpStartX = sX - 170
jumpStartY = sY - 210
jumpEndX = jumpStartX + 120
jumpEndY = jumpStartY + 120
end
end
Connect(
GetPropertyChangedSignal(mouse, 'ViewSizeX'),
refreshTouchRegions
)
Connect(
GetPropertyChangedSignal(mouse, 'ViewSizeY'),
refreshTouchRegions
)
Connect(
GetPropertyChangedSignal(gs, 'TopbarInset'),
refreshTouchRegions
)
refreshTouchRegions()
local mouseCameraMove = false
Connect(insGet(uis, 'InputChanged'), function(a, b)
if b then
return
end
local inputType = insGet(a, 'UserInputType')
if mouseCameraMove and inputType == enumMM then
local rotation = GetMouseDelta(uis) * mradN05
camcfLV = cfGet(
cfMul(camrot, angles(rotation.Y, rotation.X, 0)),
'LookVector'
)
camrot = cfl(v3_0, camcfLV)
camcfRV = cfGet(camrot, 'RightVector')
elseif inputType == enumMW then
cammag = cammag
+ v3Get(insGet(a, 'Position'), 'Z')
* (0.75 - cammag / 4)
if cammag < 0 then
firstperson = false
else
cammag = 0
firstperson = true
end
end
end)
local predictionfling = function(target)
if not c then
return false
end
if typeof(target) ~= 'Instance' then
target = insGet(mouse, 'Target')
if not target then
return false
end
end
if not IsDescendantOf(target, ws) then
return false
end
if IsA(target, 'BasePart') or IsA(target, 'Humanoid') then
target = insGet(target, 'Parent')
if IsA(target, 'Accessory') then
target = insGet(target, 'Parent')
end
end
if (not IsA(target, 'Model')) or (target == c) then
return false
end
local targetpart = gp(target, 'HumanoidRootPart', 'BasePart')
or gp(target, 'Torso', 'BasePart')
or gp(target, 'UpperTorso', 'BasePart')
if not targetpart or (flingtable[targetpart] ~= nil) then
return false
end
if replicatesignal then
replicatesignal(cdsb)
end
if highlightflingtargets then
local h = i('Highlight')
insSet(h, 'Name', rs())
insSet(h, 'Adornee', target)
insSet(h, 'FillColor', c3(1, 0, 0))
insSet(h, 'OutlineColor', c3(1, 0, 0))
insSet(h, 'FillTransparency', 0.5)
insSet(h, 'OutlineTransparency', 0)
insSet(h, 'Parent', i10)
flingtable[targetpart] = h
else
flingtable[targetpart] = false
end
return true
end
local clickConnection = nil
if ctrlclicktp then
ctrlclicktp = KeyCode.LeftControl
local tpoff = v3_010 * 3
if clickfling then
clickConnection = Connect(
insGet(mouse, 'Button1Down'),
function()
if insGet(mouse, 'Target') then
if IsKeyDown(uis, ctrlclicktp) then
pos = cfGet(
insGet(mouse, 'Hit'),
'Position'
) + tpoff
cfr = cfl(pos, pos + camcfLV * v3_101)
xzvel = v3_0
Yvel = 0
else
predictionfling()
end
end
end
)
else
clickConnection = Connect(
insGet(mouse, 'Button1Down'),
function()
if
insGet(mouse, 'Target')
and IsKeyDown(uis, ctrlclicktp)
then
pos = cfGet(insGet(mouse, 'Hit'), 'Position')
+ tpoff
cfr = cfl(pos, pos + camcfLV * v3_101)
xzvel = v3_0
Yvel = 0
end
end
)
end
elseif clickfling then
clickConnection = Connect(
insGet(mouse, 'Button1Down'),
predictionfling
)
end
local hhOff = 3
local hhOff1 = 3.01
local setHipHeight = function(n)
hhOff = n + 3
hhOff1 = n + 3.01
end
local noYvelTime = 1
local lastsine = sine
local con = nil
local mainFunction = function()
if not c then
for i, v in next, cframes do
local p = i.v
if p then
Destroy(p)
end
end
for i, v in next, flingtable do
if v then --it could be false
Destroy(v)
end
end
for i, v in next, charcons do
Disconnect(v)
end
if clickConnection then
Disconnect(clickConnection)
end
mouseBehavior = nil
insSet(uis, 'MouseBehavior', enumMD)
onnewcamera()
local c = insGet(lp, 'Character')
if c then
insSet(
cam,
'CameraSubject',
FindFirstChildOfClass(c, 'Humanoid')
)
end
return con and Disconnect(con)
end
sine = osclock()
local delta = sine - lastsine
deltaTime = min(delta * 10, 1)
lastsine = sine
if shiftlock then
if allowshiftlock then
mouseBehavior = enumMLC
mouseCameraMove = true
else
shiftlock = false
end
elseif firstperson then
mouseBehavior = enumMLC
mouseCameraMove = true
elseif IsMouseButtonPressed(uis, enumMB2) then
mouseBehavior = enumMLCP
mouseCameraMove = true
else
mouseBehavior = enumMD
mouseCameraMove = false
end
if lastMouseBehavior ~= mouseBehavior then
lastMouseBehavior = mouseBehavior
insSet(uis, 'MouseBehavior', mouseBehavior)
end
local raycastresult = Raycast(
ws,
pos,
v3_010 * (fpdh - v3Get(pos, 'Y')),
raycastparams
)
local onground = nil
if raycastresult then
raycastresult = v3Get(raycastresult.Position, 'Y')
onground = v3Get(pos, 'Y') - raycastresult < hhOff1
if onground then
Yvel = 0
pos = pos
+ v3_010
* (raycastresult + hhOff - v3Get(pos, 'Y'))
* min(delta * 20, 1)
if jumpingInput and (jumpPower > 0) then
Yvel = jumpPower
onground = false
end
else
Yvel = Yvel - gravity * delta
if v3Get(pos, 'Y') + Yvel * delta < raycastresult then
Yvel = 0
pos = pos
+ v3_010
* (raycastresult + hhOff - v3Get(pos, 'Y'))
end
end
else
Yvel = 0
onground = false
end
if firstperson then
if isWalking then
if walkSpeed == 0 then
xzvel = v3_0
if onground then
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(camrot, pos + v3_0150)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsIdle()
noYvelTime = min(noYvelTime + delta * 0.3, 1)
xzvel = xzvel * (1 - noYvelTime)
elseif Yvel > 0 then
pos = pos + v3_010 * Yvel * delta
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(camrot, pos + v3_0150)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsJump()
noYvelTime = 0
else
pos = pos + v3_010 * Yvel * delta
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(camrot, pos + v3_0150)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsFall()
noYvelTime = 0
end
else
xzvel = v3Get(
v3Get(camcfLV * v3_101, 'Unit') * FWmovement
+ v3Get(camcfRV * v3_101, 'Unit')
* RTmovement,
'Unit'
) * walkSpeed
if onground then
pos = pos + xzvel * delta
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(camrot, pos + v3_0150)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsWalk()
noYvelTime = min(noYvelTime + delta * 0.3, 1)
xzvel = xzvel * (1 - noYvelTime)
elseif Yvel > 0 then
pos = pos + (xzvel + v3_010 * Yvel) * delta
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(camrot, pos + v3_0150)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsJump()
noYvelTime = 0
else
pos = pos + (xzvel + v3_010 * Yvel) * delta
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(camrot, pos + v3_0150)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsFall()
noYvelTime = 0
end
end
else
xzvel = v3_0
if onground then
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(camrot, pos + v3_0150)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsIdle()
noYvelTime = min(noYvelTime + delta * 0.3, 1)
xzvel = xzvel * (1 - noYvelTime)
elseif Yvel > 0 then
pos = pos + v3_010 * Yvel * delta
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(camrot, pos + v3_0150)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsJump()
noYvelTime = 0
else
pos = pos + v3_010 * Yvel * delta
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(camrot, pos + v3_0150)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsFall()
noYvelTime = 0
end
end
elseif shiftlock then
if isWalking then
if walkSpeed == 0 then
xzvel = v3_0
if onground then
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(
camrot,
pos
+ v3_0150
+ camcfRV * 1.75
+ camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsIdle()
noYvelTime = min(noYvelTime + delta * 0.3, 1)
xzvel = xzvel * (1 - noYvelTime)
elseif Yvel > 0 then
pos = pos + v3_010 * Yvel * delta
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(
camrot,
pos
+ v3_0150
+ camcfRV * 1.75
+ camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsJump()
noYvelTime = 0
else
pos = pos + v3_010 * Yvel * delta
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(
camrot,
pos
+ v3_0150
+ camcfRV * 1.75
+ camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsFall()
noYvelTime = 0
end
else
xzvel = v3Get(
v3Get(camcfLV * v3_101, 'Unit') * FWmovement
+ v3Get(camcfRV * v3_101, 'Unit')
* RTmovement,
'Unit'
) * walkSpeed
if onground then
pos = pos + xzvel * delta
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(
camrot,
pos
+ v3_0150
+ camcfRV * 1.75
+ camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsWalk()
noYvelTime = min(noYvelTime + delta * 0.3, 1)
xzvel = xzvel * (1 - noYvelTime)
elseif Yvel > 0 then
pos = pos + (xzvel + v3_010 * Yvel) * delta
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(
camrot,
pos
+ v3_0150
+ camcfRV * 1.75
+ camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsJump()
noYvelTime = 0
else
pos = pos + (xzvel + v3_010 * Yvel) * delta
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(
camrot,
pos
+ v3_0150
+ camcfRV * 1.75
+ camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsFall()
noYvelTime = 0
end
end
else
xzvel = v3_0
if onground then
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(
camrot,
pos
+ v3_0150
+ camcfRV * 1.75
+ camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsIdle()
noYvelTime = min(noYvelTime + delta * 0.3, 1)
xzvel = xzvel * (1 - noYvelTime)
elseif Yvel > 0 then
pos = pos + v3_010 * Yvel * delta
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(
camrot,
pos
+ v3_0150
+ camcfRV * 1.75
+ camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsJump()
noYvelTime = 0
else
pos = pos + v3_010 * Yvel * delta
cfr = cfl(pos, pos + camcfLV * v3_101)
camcf = cfAdd(
camrot,
pos
+ v3_0150
+ camcfRV * 1.75
+ camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsFall()
noYvelTime = 0
end
end
else
if isWalking then
if walkSpeed == 0 then
xzvel = v3_0
if onground then
cfr = cfAdd(cfGet(cfr, 'Rotation'), pos)
camcf = cfAdd(
camrot,
pos + v3_0150 + camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsIdle()
noYvelTime = min(noYvelTime + delta * 0.3, 1)
xzvel = xzvel * (1 - noYvelTime)
elseif Yvel > 0 then
pos = pos + v3_010 * Yvel * delta
cfr = cfAdd(cfGet(cfr, 'Rotation'), pos)
camcf = cfAdd(
camrot,
pos + v3_0150 + camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsJump()
noYvelTime = 0
else
pos = pos + v3_010 * Yvel * delta
cfr = cfAdd(cfGet(cfr, 'Rotation'), pos)
camcf = cfAdd(
camrot,
pos + v3_0150 + camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsFall()
noYvelTime = 0
end
else
xzvel = v3Get(
v3Get(camcfLV * v3_101, 'Unit') * FWmovement
+ v3Get(camcfRV * v3_101, 'Unit')
* RTmovement,
'Unit'
) * walkSpeed
if onground then
pos = pos + xzvel * delta
cfr = cfAdd(
Lerp(
cfGet(cfr, 'Rotation'),
cfl(v3_0, xzvel),
deltaTime
),
pos
)
camcf = cfAdd(
camrot,
pos + v3_0150 + camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsWalk()
noYvelTime = min(noYvelTime + delta * 0.3, 1)
xzvel = xzvel * (1 - noYvelTime)
elseif Yvel > 0 then
pos = pos + (xzvel + (v3_010 * Yvel)) * delta
cfr = cfAdd(
Lerp(
cfGet(cfr, 'Rotation'),
cfl(v3_0, xzvel),
deltaTime
),
pos
)
camcf = cfAdd(
camrot,
pos + v3_0150 + camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsJump()
noYvelTime = 0
else
pos = pos + (xzvel + (v3_010 * Yvel)) * delta
cfr = cfAdd(
Lerp(
cfGet(cfr, 'Rotation'),
cfl(v3_0, xzvel),
deltaTime
),
pos
)
camcf = cfAdd(
camrot,
pos + v3_0150 + camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsFall()
noYvelTime = 0
end
end
else
xzvel = v3_0
if onground then
cfr = cfAdd(cfGet(cfr, 'Rotation'), pos)
camcf = cfAdd(
camrot,
pos + v3_0150 + camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsIdle()
noYvelTime = min(noYvelTime + delta * 0.3, 1)
xzvel = xzvel * (1 - noYvelTime)
elseif Yvel > 0 then
pos = pos + v3_010 * Yvel * delta
cfr = cfAdd(cfGet(cfr, 'Rotation'), pos)
camcf = cfAdd(
camrot,
pos + v3_0150 + camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsJump()
noYvelTime = 0
else
pos = pos + v3_010 * Yvel * delta
cfr = cfAdd(cfGet(cfr, 'Rotation'), pos)
camcf = cfAdd(
camrot,
pos + v3_0150 + camcfLV * cammag
)
cframes[rootpart] = cfr
insSet(cam, 'CFrame', camcf)
lerpsFall()
noYvelTime = 0
end
end
end
refreshjointsI(rootpart)
tclear(refreshedjoints)
local sine15 = sine * 15
local idlerv = v3(
sin(sine15),
sin(sine15 + 1.0471975511965976),
sin(sine15 + 2.0943951023931953)
)
local idleoff = idlerv * 0.003910064697265625 --0.0156402587890625/4
local claimpos = insGet(primarypart, 'Position')
local claimposY = v3Get(claimpos, 'Y')
for i, v in next, cframes do
local part = i.p
if part then
if insGet(part, 'ReceiveAge') == 0 then
local placeholder = i.v
local vpos = cfGet(v, 'Position')
if novoid and (v3Get(vpos, 'Y') < novoid) then
v = cfAdd(
v,
v3_010 * (novoid - v3Get(vpos, 'Y'))
)
end
local lastpos = i.l
local vel = (vpos - lastpos) / delta
local mag = v3Get(vel, 'Magnitude')
if mag < 0.11730194091796875 then --0.0156402587890625*15/2
if placeholder and i.b then
insSet(placeholder, 'Parent', nil)
i.b = false
end
i.l = cfGet(v, 'Position')
v = cfAdd(v, idleoff)
elseif mag > speedlimit then
if placeholder then
insSet(placeholder, 'CFrame', v)
if not i.b then
insSet(placeholder, 'Parent', ws)
i.b = true
end
end
vel = v3Get(vel, 'Unit') * speedlimit
local newpos = lastpos + vel * delta
v = cfAdd(cfGet(v, 'Rotation'), newpos)
i.l = newpos
else
if placeholder and i.b then
insSet(placeholder, 'Parent', nil)
i.b = false
end
i.l = cfGet(v, 'Position')
end
local claimtime = i.c
if claimtime then
if sine - claimtime < retVelTime then
local Ydiff = cfGet(v, 'Y') - claimposY
local velY = 25.01
local fallingTime = 0
while (Ydiff > 0) or (velY > 0) do
fallingTime = fallingTime + 0.025
if fallingTime > 0.6 then
break
end
velY = velY - velYdelta
Ydiff = Ydiff + (velY * 0.025)
end
insSet(
part,
'AssemblyLinearVelocity',
(claimpos - cfGet(v, 'Position'))
* v3_101
/ fallingTime
+ v3_net
)
else
local vel1 = vel * noYvelTime + xzvel
if v3Get(vel1, 'Magnitude') > 25.01 then
insSet(
part,
'AssemblyLinearVelocity',
v3Get(vel1, 'Unit') * v3_xzL
+ v3_net
)
else
insSet(
part,
'AssemblyLinearVelocity',
vel1 * v3_xz + v3_net
)
end
end
else
i.c = sine
local vel1 = vel * noYvelTime + xzvel
if v3Get(vel1, 'Magnitude') > 25.01 then
insSet(
part,
'AssemblyLinearVelocity',
v3Get(vel1, 'Unit') * v3_xzL + v3_net
)
else
insSet(
part,
'AssemblyLinearVelocity',
vel1 * v3_xz + v3_net
)
end
end
insSet(part, 'CFrame', v)
insSet(part, 'AssemblyAngularVelocity', idlerv)
else
i.c = nil
i.l = insGet(part, 'Position')
local placeholder = i.v
if placeholder then
insSet(placeholder, 'CFrame', v)
if not i.b then
insSet(placeholder, 'Parent', ws)
i.b = true
end
end
end
else
local placeholder = i.v
if placeholder then
insSet(placeholder, 'CFrame', v)
if not i.b then
insSet(placeholder, 'Parent', ws)
i.b = true
end
end
end
end
setsimrad()
end
sine = osclock()
lastsine = sine
con = Connect(heartbeat, mainFunction)
mainFunction()
local refreshjoints =
function(v) --use this on the main part if u have parts that
refreshjointsI(v) --are connected with each other but arent connected to rootpart
tclear(refreshedjoints)
end
local legcfR = cf(1, -1, 0)
local legcfL = cf(-1, -1, 0)
local raydir = v3_010 * -2
local raycastlegs =
function() --this returns 2 values: right leg raycast offset, left leg raycast offset
local rY = Raycast(
ws,
cfGet(cfMul(cfr, legcfR), 'Position'),
raydir,
raycastparams
)
local lY = Raycast(
ws,
cfGet(cfMul(cfr, legcfL), 'Position'),
raydir,
raycastparams
)
if rY then
if lY then
return v3Get(rY.Position, 'Y')
- (v3Get(pos, 'Y') - 3),
v3Get(lY.Position, 'Y') - (v3Get(pos, 'Y') - 3)
else
return v3Get(rY.Position, 'Y')
- (v3Get(pos, 'Y') - 3),
0
end
elseif lY then
return 0,
v3Get(lY.Position, 'Y') - (v3Get(pos, 'Y') - 3)
else
return 0, 0
end
end
local velbycfrvec =
function() --this returns 2 values: forward/backwards movement (from -1 to 1), right/left movement (from -1 to 1)
local fw = cfGet(cfr, 'LookVector') * xzvel / walkSpeed
local rt = cfGet(cfr, 'RightVector') * xzvel / walkSpeed
return v3Get(fw, 'X') + v3Get(fw, 'Z'),
v3Get(rt, 'X') + v3Get(rt, 'Z')
end
local lastvel = v3_0
local velchg1 = v3_0
local velchgbycfrvec =
function() --this returns 2 values: forward/backwards velocity change, right/left velocity change
velchg1 = velchg1 + (lastvel - xzvel) --i recommend setting velchg1 to v3_0 when u start using this function or it will look worse
lastvel = xzvel
velchg1 = velchg1 - velchg1 * (deltaTime / 2)
local fw = cfGet(cfr, 'LookVector') * velchg1 / 32
local rt = cfGet(cfr, 'RightVector') * velchg1 / 32
return v3Get(fw, 'X') + v3Get(fw, 'Z'),
v3Get(rt, 'X') + v3Get(rt, 'Z')
end
local lastYvel = 0
local velYchg1 = 0
local velYchg = function() --this returns Y axis velocity change
velYchg1 = clamp(velYchg1 + (lastYvel - Yvel), -50, 50) --i recommend setting velYchg1 to 0 when u start using this function or it will look worse
lastYvel = Yvel
velYchg1 = velYchg1 - velYchg1 * (deltaTime / 2)
return velYchg1
end
local rotToMouse =
function(alpha) --this rotates ur character towards your mouse hit position
local pos1 = pos * v3_010
+ cfGet(insGet(mouse, 'Hit'), 'Position') * v3_101
if pos ~= pos1 then --could make nan rotation
cfr = Lerp(cfr, cfl(pos, pos1), alpha or deltaTime)
end
end
local glitchJoint = function(
joint,
targetGlitchTime,
delayFrom,
delayTo,
radiansFrom,
radiansTo
)
if sine > targetGlitchTime then --example usage: local glitchtime=0 addMode("x",{idle=function() glitchtime=glitchJoint(joint,glitchtime,0.2,0.4,-0.1,0.1) end})
radiansFrom = radiansFrom * 100
radiansTo = radiansTo * 100
joint.C0 = cfMul(
joint.C0,
angles(
mrandom(radiansFrom, radiansTo) / 100,
mrandom(radiansFrom, radiansTo) / 100,
mrandom(radiansFrom, radiansTo) / 100
)
)
return sine + mrandom(delayFrom * 100, delayTo * 100) / 100
end
return targetGlitchTime
end
local setWalkSpeed = function(n)
if type(n) ~= 'number' then
n = 16
end
walkSpeed = n
end
local setJumpPower = function(n)
if type(n) ~= 'number' then
n = 50
end
jumpPower = n
end
local setGravity = function(n)
if type(n) ~= 'number' then
n = 196.2
end
gravity = n
end
local setCfr = function(v) --sets character cframe
if typeof(v) == 'CFrame' then
local newpos = cfGet(v, 'Position')
camcf = cfAdd(camcf, newpos - pos)
insSet(cam, 'CFrame', camcf)
cfr = v
pos = newpos
elseif typeof(v) == 'Vector3' then
camcf = cfAdd(camcf, v - pos)
insSet(cam, 'CFrame', camcf)
cfr = cfAdd(cfGet(cfr, 'Rotation'), v)
pos = v
end
end
local getVel = function() --returns character velocity
return xzvel + v3_010 * Yvel --important: use only in lerps or it might not work
end
local getCamCF = function() --returns camera cframe
return camcf
end
local isFirstPerson =
function() --returns true if user is in first person camera mode
return firstperson
end
return {
cframes = cframes,
joints = joints,
fling = predictionfling,
predictionfling = predictionfling,
refreshjoints = refreshjoints,
raycastlegs = raycastlegs,
velbycfrvec = velbycfrvec,
velchgbycfrvec = velchgbycfrvec,
velYchg = velYchg,
addmode = addmode,
getPart = getPart,
getPartFromMesh = getPartFromMesh,
getAccWeldFromMesh = getAccWeldFromMesh,
getJoint = getJoint,
getPartJoint = getPartJoint,
rotToMouse = rotToMouse,
glitchJoint = glitchJoint,
setWalkSpeed = setWalkSpeed,
setJumpPower = setJumpPower,
setGravity = setGravity,
setCfr = setCfr,
getVel = getVel,
getCamCF = getCamCF,
isFirstPerson = isFirstPerson,
setHipHeight = setHipHeight,
}
end
btn('creepy crawler', function()
local t = reanimate()
if type(t) ~= 'table' then
return
end
local getJoint = t.getJoint
local rootJoint = getJoint('RootJoint')
local rightShoulder = getJoint('Right Shoulder')
local leftShoulder = getJoint('Left Shoulder')
local rightHip = getJoint('Right Hip')
local leftHip = getJoint('Left Hip')
local neck = getJoint('Neck')
t.setWalkSpeed(10)
local jumplerp = function()
neck.C0 = Lerp(
neck.C0,
cfMul(cf(0, 0, 0.5), angles(0, 0, 3.141592653589793)),
deltaTime
)
rootJoint.C0 = Lerp(
rootJoint.C0,
cfMul(
cf(0, -1.4, 0),
angles(3.141592653589793, 0, -3.141592653589793)
),
deltaTime
)
leftShoulder.C0 = Lerp(
leftShoulder.C0,
cfMul(
cf(-1, 1.5, 0.3),
angles(1.7453292519943295, 0, -0.17453292519943295)
),
deltaTime
)
rightShoulder.C0 = Lerp(
rightShoulder.C0,
cfMul(
cf(1, 1.5, 0.3),
angles(1.7453292519943295, 0, 0.17453292519943295)
),
deltaTime
)
leftHip.C0 = Lerp(
leftHip.C0,
cfMul(
cf(-1, -1.5, 0.8),
angles(1.3962634015954636, 0, -0.17453292519943295)
),
deltaTime
)
rightHip.C0 = Lerp(
rightHip.C0,
cfMul(
cf(1, -1.5, 0.8),
angles(1.3962634015954636, 0, 0.17453292519943295)
),
deltaTime
)
end
t.addmode('default', {
idle = function()
local sine = sine * 60
neck.C0 = Lerp(
neck.C0,
cfMul(
cf(0, 0, 0.5),
angles(
0.08726646259971647 * sin((sine + 20) * 0.05),
0,
3.141592653589793
+ 0.3490658503988659
* sin((sine + -30) * 0.025)
)
),
deltaTime
)
rootJoint.C0 = Lerp(
rootJoint.C0,
cfMul(
cf(0, -1.5 + 0.1 * sin(sine * 0.05), 0),
angles(
3.141592653589793,
0,
-3.1590459461097367
+ 0.05235987755982989
* sin(sine * 0.025)
)
),
deltaTime
)
leftShoulder.C0 = Lerp(
leftShoulder.C0,
cfMul(
cf(-1, 1.5, -0.1 * sin(sine * 0.05)),
angles(
1.5707963267948966,
0,
0.08726646259971647 * sin(sine * 0.025)
)
),
deltaTime
)
rightShoulder.C0 = Lerp(
rightShoulder.C0,
cfMul(
cf(1, 1.5, -0.1 * sin(sine * 0.05)),
angles(
1.5707963267948966,
0,
0.08726646259971647 * sin(sine * 0.025)
)
),
deltaTime
)
leftHip.C0 = Lerp(
leftHip.C0,
cfMul(
cf(-1, -1.5, 0.5 + -0.1 * sin((sine + 10) * 0.05)),
angles(
1.5707963267948966,
0,
0.08726646259971647 * sin(sine * 0.025)
)
),
deltaTime
)
rightHip.C0 = Lerp(
rightHip.C0,
cfMul(
cf(1, -1.5, 0.5 + -0.1 * sin((sine + 10) * 0.05)),
angles(
1.5707963267948966,
0,
0.08726646259971647 * sin(sine * 0.025)
)
),
deltaTime
)
end,
walk = function()
local sine = sine * 60
neck.C0 = Lerp(
neck.C0,
cfMul(
cf(0, 0, 0.5),
angles(
0.17453292519943295,
0.03490658503988659 * sin((sine + 2.5) * 0.2),
3.141592653589793
+ -0.17453292519943295
* sin((sine + -10) * 0.2)
)
),
deltaTime
)
rootJoint.C0 = Lerp(
rootJoint.C0,
cfMul(
cf(0, -1.5, 0),
angles(
3.0543261909900767,
0.08726646259971647 * sin((sine + 7.5) * 0.2),
-3.1590459461097367
+ -0.08726646259971647 * sin(sine * 0.2)
)
),
deltaTime
)
leftShoulder.C0 = Lerp(
leftShoulder.C0,
cfMul(
cf(
-1,
1.5 + 0.5 * sin((sine + 10) * 0.2),
0.3 + 0.2 * sin((sine + -10) * 0.2)
),
angles(
1.6580627893946132
+ 0.17453292519943295
* sin((sine + 15) * 0.2),
0,
-0.08726646259971647 * sin(sine * 0.2)
)
),
deltaTime
)
rightShoulder.C0 = Lerp(
rightShoulder.C0,
cfMul(
cf(
1,
1.5 + 0.5 * sin((sine + -7.5) * 0.2),
0.3 + 0.2 * sin((sine + 5) * 0.2)
),
angles(
1.6580627893946132
+ 0.17453292519943295 * sin(sine * 0.2),
0,
-0.08726646259971647 * sin(sine * 0.2)
)
),
deltaTime
)
leftHip.C0 = Lerp(
leftHip.C0,
cfMul(
cf(
-1,
-1.5 + 0.5 * sin((sine + -7.5) * 0.2),
0.5 + 0.2 * sin((sine + 5) * 0.2)
),
angles(
1.6580627893946132
+ 0.17453292519943295 * sin(sine * 0.2),
0,
-0.08726646259971647 * sin(sine * 0.2)
)
),
deltaTime
)
rightHip.C0 = Lerp(
rightHip.C0,
cfMul(
cf(
1,
-1.5 + 0.5 * sin((sine + 10) * 0.2),
0.5 + 0.2 * sin((sine + -7.5) * 0.2)
),
angles(
1.6580627893946132
+ -0.17453292519943295 * sin(sine * 0.2),
0,
-0.08726646259971647 * sin(sine * 0.2)
)
),
deltaTime
)
end,
jump = jumplerp,
fall = jumplerp,
})
end)
btn('nameless animations V8', function()
local t = reanimate()
if type(t) ~= 'table' then
return
end
local raycastlegs = t.raycastlegs
local velbycfrvec = t.velbycfrvec
local addmode = t.addmode
local getJoint = t.getJoint
local velYchg = t.velYchg
local setWalkSpeed = t.setWalkSpeed
local RootJoint = getJoint('RootJoint')
local RightShoulder = getJoint('Right Shoulder')
local LeftShoulder = getJoint('Left Shoulder')
local RightHip = getJoint('Right Hip')
local LeftHip = getJoint('Left Hip')
local Neck = getJoint('Neck')
addmode('default', {
idle = function()
local rY, lY = raycastlegs()
local Ychg = velYchg() / 20
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
-1,
0.5 + 0.1 * sin((sine - 1) * 1.3),
0.05 * sin((sine - 0.3) * 1.3)
),
angles(
0.5235987755982988
+ 0.08726646259971647 * sin(sine * 1),
-1.4835298641951802
+ 0.10471975511965978 * sin(sine * 1.3),
0.5235987755982988
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
1,
0.5 + 0.1 * sin((sine - 1) * 1.3),
0.05 * sin((sine - 0.3) * 1.3)
),
angles(
0.5235987755982988
+ 0.08726646259971647 * sin(sine * 1),
1.4835298641951802
- 0.10471975511965978 * sin(sine * 1.3),
-0.5235987755982988
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-1.09 - 0.1 * sin(sine * 1.3) + lY - Ychg,
lY * -0.5
),
angles(
-0.026179938779914945 * sin(sine * 1.3),
-1.3962634015954636,
0
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-1.09 - 0.1 * sin(sine * 1.3) + rY - Ychg,
rY * -0.5
),
angles(
-0.026179938779914945 * sin(sine * 1.3),
1.3962634015954636,
0
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
0,
0.09 + 0.1 * sin(sine * 1.3) + Ychg,
0.025 * sin(sine * 1.3)
),
angles(
-1.5707963267948966
+ 0.026179938779914945 * sin(sine * 1.3),
0,
3.141592653589793
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.53588974175501
- 0.026179938779914945
* sin((sine + 1) * 1.3),
0.05235987755982989 * sin((sine - 0.6) * 0.65),
3.141592653589793
)
),
deltaTime
)
--MW_animatorProgressSave: LeftArm,-1,0,0,1,30,5,0,1,0.5,0.1,-1,1.3,-85,6,0,1.3,0,0.05,-0.3,1.3,30,0,0,1,RightArm,1,0,0,1,30,5,0,1,0.5,0.1,-1,1.3,85,-6,0,1.3,0,0.05,-0.3,1.3,-30,0,0,1,LeftLeg,-1,0,0,1,-0,-1.5,0,1.3,-1.09,-0.1,0,1.3,-80,0,0,1,0,0,0,1,0,0,0,1,CPlusPlusTextbook_Handle,8.658389560878277e-09,0,0,1,0,0,0,1,-0.25,0,0,1,0,0,0,1,-0.0002722442150115967,0,0,1,0,0,0,1,RightLeg,1,0,0,1,0,-1.5,0,1.3,-1.09,-0.1,0,1.3,80,0,0,1,0,0,0,1,0,0,0,1,Torso,0,0,0,1,-90,1.5,0,1.3,0.09,0.1,0,1.3,-0,0,0,1,0,0.025,0,1.3,180,0,0,1,Head,0,0,0,1,-88,-1.5,1,1.3,1,0,0,1,-0,3,-0.6,0.65,0,0,0,1,180,0,0,1
end,
walk = function()
local Vfw, Vrt = velbycfrvec()
local rY, lY = raycastlegs()
local Ychg = velYchg() / 20
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
-0.7853981633974483
* sin((sine + 0.07) * 8)
* Vfw,
-1.5707963267948966
+ 0.5235987755982988
* sin((sine + 0.15) * 8),
0
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
0.7853981633974483
* sin((sine + 0.07) * 8)
* Vfw,
1.5707963267948966
+ 0.5235987755982988
* sin((sine + 0.15) * 8),
0
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-1 + 0.3 * sin((sine - 0.15) * 8) + rY - Ychg,
rY * -0.5
),
angles(
1.5707963267948966
- 0.9599310885968813
* sin(sine * 8)
* Vfw,
1.5707963267948966
- 0.7853981633974483
* sin(sine * 8)
* Vrt,
-1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-1 + 0.3 * sin((sine + 0.15) * 8) + lY - Ychg,
lY * -0.5
),
angles(
1.5707963267948966
+ 0.9599310885968813
* sin(sine * 8)
* Vfw,
-1.5707963267948966
+ 0.7853981633974483
* sin(sine * 8)
* Vrt,
1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.08726646259971647 * sin(sine * 16),
0,
3.141592653589793
+ 0.08726646259971647 * sin(
(sine + 0.04) * 8
)
- Vrt
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, 0.2 * sin((sine + 0.1) * 16) + Ychg, 0),
angles(-1.5707963267948966, 0, 3.141592653589793)
),
deltaTime
)
--MW_animatorProgressSave: CPlusPlusTextbook_Handle,8.658389560878277e-09,0,0,8,0,0,0,8,-0.25,0,0,8,0,0,0,8,-0.0002722442150115967,0,0,8,0,0,0,8,LeftArm,-1,0,0,8,-0,-45,0.07,8,0.5,0,0,8,-90,30,0.15,8,0,0,0,8,0,0,0,8,RightArm,1,0,0,8,0,45,0.07,8,0.5,0,0,8,90,30,0.15,8,0,0,0,8,0,0,0,8,RightLeg,1,0,0,8,90,-55,0,8,-1,0.3,-0.15,8,90,-45,0,8,0,0,0,8,-90,0,0,8,LeftLeg,-1,0,0,8,90,55,0,8,-1,0.3,0.15,8,-90,45,0,8,0,0,0,8,90,0,0,8,Head,0,0,0,8,-90,5,0,16,1,0,0,8,-0,0,0,8,0,0,0,8,180,5,0.04,8,Torso,0,0,0,8,-90,0,0,8,0,0.2,0.1,16,-0,0,0,8,0,0,0,8,180,0,0,8
end,
jump = function()
velYchg()
local Vfw, Vrt = velbycfrvec()
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf_0,
angles(
-1.4835298641951802 + Vfw * 0.1,
Vrt * -0.05,
-3.141592653589793
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
4.014257279586958
- 0.08726646259971647
* sin((sine + 0.5) * 4),
1.7453292519943295
+ 0.08726646259971647
* sin((sine + 0.25) * 4),
-1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1, 0),
angles(
1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.5) * 4),
-1.6580627893946132
+ 0.06981317007977318
* sin((sine + 0.25) * 4),
1.5707963267948966
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
4.014257279586958
- 0.08726646259971647
* sin((sine + 0.5) * 4),
-1.7453292519943295
- 0.08726646259971647
* sin((sine + 0.25) * 4),
1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.3962634015954636,
0,
-3.141592653589793 - Vrt
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1, 0),
angles(
1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.5) * 4),
1.6580627893946132
- 0.06981317007977318
* sin((sine + 0.25) * 4),
-1.5707963267948966
)
),
deltaTime
)
--Torso,0,0,0,4,-85,0,0,4,0,0,0,4,0,0,0,4,0,0,0,4,-180,0,0,4,RightArm,1,0,0,4,230,-5,0.5,4,0.5,0,0,4,100,5,0.25,4,0,0,0,4,-90,0,0,4,LeftLeg,-1,0,0,4,90,-5,0.5,4,-1,0,0,4,-95,4,0.25,4,0,0,0,4,90,0,0,4,LeftArm,-1,0,0,4,230,-5,0.5,4,0.5,0,0,4,-100,-5,0.25,4,0,0,0,4,90,0,0,4,Head,0,0,0,4,-80,0,0.5,4,1,0,0,4,0,0,0.25,4,0,0,0,4,-180,0,0,4,RightLeg,1,0,0,4,90,-5,0.5,4,-1,0,0,4,95,-4,0.25,4,0,0,0,4,-90,0,0,4
end,
fall = function()
velYchg()
local Vfw, Vrt = velbycfrvec()
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf_0,
angles(
-1.6580627893946132 + Vfw * 0.1,
Vrt * -0.05,
-3.141592653589793
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
4.014257279586958
- 0.08726646259971647
* sin((sine + 0.5) * 4),
1.7453292519943295
+ 0.08726646259971647
* sin((sine + 0.25) * 4),
-1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1, 0),
angles(
1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.5) * 4),
-1.6580627893946132
+ 0.06981317007977318
* sin((sine + 0.25) * 4),
1.5707963267948966
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
4.014257279586958
- 0.08726646259971647
* sin((sine + 0.5) * 4),
-1.7453292519943295
- 0.08726646259971647
* sin((sine + 0.25) * 4),
1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.7453292519943295,
0,
-3.141592653589793 - Vrt
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1, 0),
angles(
1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.5) * 4),
1.6580627893946132
- 0.06981317007977318
* sin((sine + 0.25) * 4),
-1.5707963267948966
)
),
deltaTime
)
--Torso,0,0,0,4,-95,0,0,4,0,0,0,4,0,0,0,4,0,0,0,4,-180,0,0,4,RightArm,1,0,0,4,230,-5,0.5,4,0.5,0,0,4,100,5,0.25,4,0,0,0,4,-90,0,0,4,LeftLeg,-1,0,0,4,90,-5,0.5,4,-1,0,0,4,-95,4,0.25,4,0,0,0,4,90,0,0,4,LeftArm,-1,0,0,4,230,-5,0.5,4,0.5,0,0,4,-100,-5,0.25,4,0,0,0,4,90,0,0,4,Head,0,0,0,4,-100,0,0.5,4,1,0,0,4,0,0,0.25,4,0,0,0,4,-180,0,0,4,RightLeg,1,0,0,4,90,-5,0.5,4,-1,0,0,4,95,-4,0.25,4,0,0,0,4,-90,0,0,4
end,
})
addmode('q', {
idle = function()
velYchg()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.75, -0.2),
angles(
2.705260340591211
- 0.08726646259971647
* sin((sine + 0.1) * 2),
-2.792526803190927,
-0.6981317007977318
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.75, -0.2),
angles(
2.705260340591211
- 0.08726646259971647
* sin((sine + 0.1) * 2),
2.792526803190927,
0.6981317007977318
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.9198621771937625
- 0.10471975511965978
* sin((sine + 0.3) * 2),
0,
3.141592653589793
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, -2.45 - 0.05 * sin(sine * 2), 0),
angles(
0.03490658503988659 * sin(sine * 2),
0,
3.141592653589793
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1, 0),
angles(
1.3962634015954636
- 0.03490658503988659 * sin(sine * 2),
1.3089969389957472,
-0.9599310885968813
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1, 0),
angles(
1.5707963267948966
- 0.03490658503988659 * sin(sine * 2),
-1.3089969389957472,
1.5707963267948966
)
),
deltaTime
)
--LeftArm,-1,0,0,2,155,-5,0.1,2,0.75,0,0,2,-160,0,0,2,-0.2,0,0,2,-40,0,0,2,RightArm,1,0,0,2,155,-5,0.1,2,0.75,0,0,2,160,0,0,2,-0.2,0,0,2,40,0,0,2,Head,0,0,0,2,-110,-6,0.3,2,1,0,0,2,-0,0,0,2,0,0,0,2,180,0,0,2,Torso,0,0,0,2,0,2,0,2,-2.45,-0.05,0,2,-0,0,0,2,0,0,0,2,180,0,0,2,RightLeg,1,0,0,2,80,-2,0,2,-1,0,0,2,75,0,0,2,0,0,0,2,-55,0,0,2,LeftLeg,-1,0,0,2,90,-2,0,2,-1,0,0,2,-75,0,0,2,0,0,0,2,90,0,0,2
end,
})
addmode('e', {
idle = function()
velYchg()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
-0.9,
0.4 + 0.1 * sin(sine * 2),
0.3 - 0.15 * sin(sine * 2)
),
angles(
-1.0471975511965976
- 0.12217304763960307 * sin(sine * 2),
-1.3962634015954636,
-0.6981317007977318
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, -1.85 - 0.1 * sin((sine + 0.2) * 2), 0),
angles(
-1.3962634015954636
+ 0.03490658503988659 * sin(sine * 2),
-0.08726646259971647,
3.141592653589793
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
1,
0.4 + 0.1 * sin(sine * 2),
0.2 - 0.15 * sin(sine * 2)
),
angles(
0.6108652381980153
- 0.12217304763960307 * sin(sine * 2),
1.2217304763960306,
-0.7853981633974483
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.6580627893946132
- 0.03490658503988659
* sin((sine + 0.6) * 2),
0.10471975511965978
+ 0.06981317007977318 * sin(sine * 0.66),
3.141592653589793
+ 0.3490658503988659 * sin(sine * 0.66)
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
0.2 + 0.15 * sin((sine + 0.2) * 2),
-0.7 + 0.1 * sin(sine * 2)
),
angles(
1.4835298641951802
+ 0.03490658503988659 * sin(sine * 2),
1.4835298641951802,
-1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -0.75 + 0.1 * sin((sine + 0.2) * 2), -0.5),
angles(
1.3962634015954636
- 0.03490658503988659 * sin(sine * 2),
-1.6580627893946132,
0
)
),
deltaTime
)
--LeftArm,-0.9,0,0,2,-60,-7,0,2,0.4,0.1,0,2,-80,0,0,2,0.3,-0.15,0,2,-40,0,0,2,Torso,0,0,0,2,-80,2,0,2,-1.85,-0.1,0.2,2,-5,0,0,2,0,0,0,2,180,0,0,2,RightArm,1,0,0,2,35,-7,0,2,0.4,0.1,0,2,70,0,0,2,0.2,-0.15,0,2,-45,0,0,2,Head,0,0,0,2,-95,-2,0.6,2,1,0,0,2,6,4,0,0.66,0,0,0,2,180,20,0,0.66,RightLeg,1,0,0,2,85,2,0,2,0.2,0.15,0.2,2,85,0,0,2,-0.7,0.1,0,2,-90,0,0,2,LeftLeg,-1,0,0,2,80,-2,0,2,-0.75,0.1,0.2,2,-95,0,0,2,-0.5,0,0,2,0,0,0,2
end,
})
addmode('r', {
idle = function()
local Ychg = velYchg() / 20
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -0.9 - 0.2 * sin(sine * 2) - Ychg, 0),
angles(
1.5707963267948966,
1.6580627893946132
- 0.17453292519943295 * sin(sine + 0.8),
-1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
0.3 * sin(sine + 0.8),
-0.1 + 0.2 * sin(sine * 2) + Ychg,
0
),
angles(-1.5707963267948966, 0, -3.141592653589793)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.08726646259971647
* sin((sine - 0.5) * 2),
0.08726646259971647 * sin(sine - 1),
-3.141592653589793
+ 0.2617993877991494 * sin(sine * 5)
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
-1 + 0.1 * sin(sine * 7),
0.2 - 0.1 * sin(sine + 0.8),
-0.25
),
angles(
1.5707963267948966
+ 0.5235987755982988 * sin(sine * 7),
-0.6981317007977318,
0.3490658503988659 * sin(sine * 7)
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -0.9 - 0.2 * sin(sine * 2) - Ychg, 0),
angles(
1.5707963267948966,
-1.6580627893946132
- 0.17453292519943295 * sin(sine + 0.8),
1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
1 + 0.1 * sin(sine * 7),
0.2 + 0.1 * sin(sine + 0.8),
-0.25
),
angles(
1.5707963267948966
- 0.5235987755982988 * sin(sine * 7),
0.6981317007977318,
0.3490658503988659 * sin(sine * 7)
)
),
deltaTime
)
--RightLeg,1,0,0,1,90,0,0,1,-0.9,-0.2,0,2,95,-10,0.8,1,0,0,0,1,-90,0,0,1,Torso,0,0.3,0.8,1,-90,0,0,1,-0.1,0.2,0,2,0,0,0,1,0,0,0,1,-180,0,0,1,Head,0,0,0,1,-90,5,-0.5,2,1,0,0,1,0,5,-1,1,0,0,0,1,-180,15,0,5,Fedora_Handle,8.657480066176504e-09,0,0,1,-6,0,0,1,-0.15052366256713867,0,0,1,0,0,0,1,-0.010221302509307861,0,0,1,0,0,0,1,LeftArm,-1,0.1,0,7,90,30,0,7,0.2,-0.1,0.8,1,-40,0,0,1,-0.25,0,0,1,0,20,0,7,LeftLeg,-1,0,0,1,90,0,0,1,-0.9,-0.2,0,2,-95,-10,0.8,1,0,0,0,1,90,0,0,1,RightArm,1,0.1,0,7,90,-30,0,7,0.2,0.1,0.8,1,40,0,0,1,-0.25,0,0,1,-0,20,0,7
end,
})
addmode('t', {
idle = function()
local Ychg = velYchg() / 20
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
1.5707963267948966,
-1.6580627893946132
+ 0.08726646259971647
* sin((sine - 0.3) * 4),
1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1 + 0.15 * sin((sine - 0.4) * 4), 1.42, 0),
angles(
1.5707963267948966,
1.4835298641951802
- 0.3490658503988659
* sin((sine - 0.4) * 4),
1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.4835298641951802,
0.04363323129985824
- 0.08726646259971647
* sin((sine + 0.1) * 4),
-3.141592653589793
+ 0.04363323129985824 * sin(sine * 4)
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0.1 * sin(sine * 4), Ychg, 0),
angles(
-1.5707963267948966,
-0.08726646259971647
+ 0.08726646259971647 * sin(sine * 4),
-3.141592653589793
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1.1 + 0.1 * sin(sine * 4) - Ychg, 0),
angles(
1.5707963267948966,
1.5707963267948966
+ 0.08726646259971647 * sin(sine * 4),
-1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1 - 0.02 * sin(sine * 4),
-0.925 - 0.07 * sin(sine * 4) - Ychg,
0
),
angles(
1.5707963267948966,
-1.7453292519943295
+ 0.08726646259971647 * sin(sine * 4),
1.5707963267948966
)
),
deltaTime
)
--LeftArm,-1,0,0,4,90,0,0,4,0.5,0,0,4,-95,5,-0.3,4,0,0,0,4,90,0,0,4,RightArm,1,0.15,-0.4,4,90,0,0,4,1.42,0,0,4,85,-20,-0.4,4,0,0,0,4,90,0,0,4,Head,0,0,0,4,-85,0,0,4,1,0,0,4,2.5,-5,0.1,4,0,0,0,4,-180,2.5,0,4,Torso,0,0.1,0,4,-90,0,0,4,0,0,0,4,-5,5,0,4,0,0,0,4,-180,0,0,4,RightLeg,1,0,0,4,90,0,0,4,-1.1,0.1,0,4,90,5,0,4,0,0,0,4,-90,0,0,4,LeftLeg,-1,-0.02,0,4,90,0,0,4,-0.925,-0.07,0,4,-100,5,0,4,0,0,0,4,90,0,0,4
end,
})
addmode('y', {
idle = function()
local Ychg = velYchg() / 20
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1.5, 0.5, 0),
angles(
-1.7453292519943295,
0.17453292519943295
- 0.04363323129985824 * sin(sine * 2),
-1.4835298641951802
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-0.9000000953674316 - 0.1 * sin(sine * 2) - Ychg,
0
),
angles(
-1.3962634015954636,
1.3962634015954636,
1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-1.0000001192092896 - 0.1 * sin(sine * 2) - Ychg,
0
),
angles(
-1.5707963267948966,
-1.3962634015954636,
-1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-2.0943951023931953
+ 0.08726646259971647
* sin((sine - 1) * 2),
-0.08726646259971647,
2.792526803190927
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 1.2000000476837158, 0),
angles(
2.6179938779914944
+ 0.08726646259971647
* sin((sine - 1) * 2),
0.6981317007977318,
-1.3962634015954636
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, 0.1 * sin(sine * 2) + Ychg, 0),
angles(
-1.6580627893946132,
0.08726646259971647,
3.0543261909900767
)
),
deltaTime
)
--LeftArm,-1.5,0,0,2,-100,0,0,2,0.5,0,0,2,10,-2.5,0,2,0,0,0,2,-85,0,0,2,RightLeg,1,0,0,2,-80,0,0,2,-0.9000000953674316,-0.1,0,2,80,0,0,2,0,0,0,2,90,0,0,2,LeftLeg,-1,0,0,2,-90,0,0,2,-1.0000001192092896,-0.1,0,2,-80,0,0,2,0,0,0,2,-90,0,0,2,Fedora_Handle,8.657480066176504e-09,0,0,2,-6,0,0,2,-0.15052366256713867,0,0,2,0,0,0,2,-0.010221302509307861,0,0,2,0,0,0,2,Head,0,0,0,2,-120,5,-1,2,1,0,0,2,-5,0,0,2,0,0,0,2,160,0,0,2,RightArm,1,0,0,2,150,5,-1,2,1.2000000476837158,0,0,2,40,0,0,2,0,0,0,2,-80,0,0,2,Torso,0,0,0,2,-95,0,0,2,0,0.1,0,2,5,0,0,2,0,0,0,2,175,0,0,2
end,
})
addmode('u', {
idle = function()
velYchg()
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, 0.75 + 0.25 * sin(sine * 2), 0),
angles(-1.5707963267948966, 0, 3.141592653589793)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1.5 - 0.1 * sin((sine + 0.2) * 2), 0),
angles(
-1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.4) * 2),
0,
3.141592653589793
+ 0.3490658503988659 * sin(sine * 0.66)
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-0.5 - 1 * sin((sine + 0.2) * 2.2),
-0.75 - 0.25 * sin(sine * 2),
1 * sin((sine + 0.95) * 2.2)
),
angles(0, -1.5707963267948966, 0)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
0.5 + 1 * sin((sine + 0.2) * 2.2),
-0.75 - 0.25 * sin(sine * 2),
-1 * sin((sine + 0.95) * 2.2)
),
angles(0, 1.5707963267948966, 0)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
-0.5 - 1.85 * sin(sine * 2),
0.8 - 0.5 * sin(sine * 2),
-1.85 * sin((sine + 0.75) * 2)
),
angles(0, 1.5707963267948966, 0)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
0.5 + 1.85 * sin(sine * 2),
0.8 - 0.5 * sin(sine * 2),
1.85 * sin((sine + 0.75) * 2)
),
angles(0, -1.5707963267948966, 0)
),
deltaTime
)
--Torso,0,0,0,2,-90,0,0,2,0.75,0.25,0,2,-0,0,0,2,0,0,0,2,180,0,0,2,Fedora_Handle,8.657480066176504e-09,0,0,2,-6,0,0,2,-0.15052366256713867,0,0,2,0,0,0,2,-0.010221302509307861,0,0,2,0,0,0,2,Head,0,0,0,2,-90,-5,0.4,2,1.5,-0.1,0.2,2,-0,0,0,2,0,0,0,2,180,20,0,0.66,LeftLeg,-0.5,-1,0.2,2.2,-0,0,0,2,-0.75,-0.25,0,2,-90,0,0,2,0,1,0.95,2.2,0,0,0,2,RightLeg,0.5,1,0.2,2.2,0,0,0,2,-0.75,-0.25,0,2,90,0,0,2,0,-1,0.95,2.2,0,0,0,2,RightArm,-0.5,-1.85,0,2,0,0,0,2,0.8,-0.5,0,2,90,0,0,2,0,-1.85,0.75,2,0,0,0,2,LeftArm,0.5,1.85,0,2,-0,0,0,2,0.8,-0.5,0,2,-90,0,0,2,0,1.85,0.75,2,0,0,0,2
end,
})
addmode('i', {
idle = function()
local Ychg = velYchg() / 20
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
-0.5,
0.5 + 0.1 * sin((sine - 0.4444444444444444) * 9),
0
),
angles(
2.9670597283903604
+ 0.17453292519943295
* sin(
(sine - 0.17777777777777778) * 9
),
-0.5235987755982988,
1.5707963267948966
+ 0.17453292519943295 * sin(sine * 4.5)
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-0.5
+ 0.1 * sin(
(sine + 0.26666666666666666) * 4.5
)
- Ychg,
-0.5
),
angles(
1.7453292519943295
- 1.0471975511965976 * sin(sine * 4.5),
-1.5707963267948966
+ 0.03490658503988659 * sin(sine * 4.5),
1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
0,
-0.5
+ 0.5 * sin(
(sine + 0.17777777777777778) * 9
)
+ Ychg,
0
),
angles(
-1.3962634015954636
- 0.03490658503988659
* sin(
(sine + 0.17777777777777778) * 9
),
-0.05235987755982989 * sin(sine * 4.5),
3.141592653589793
+ 0.03490658503988659 * sin(sine * 4.5)
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1 + 0.2 * sin(sine * 9), 0),
angles(
-1.5707963267948966
+ 0.08726646259971647 * sin(sine * 9),
0.08726646259971647 * sin(sine * 4.5),
3.141592653589793
- 0.06981317007977318 * sin(sine * 4.5)
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
0.5,
0.5 + 0.1 * sin((sine - 0.4444444444444444) * 9),
0
),
angles(
2.9670597283903604
+ 0.17453292519943295
* sin(
(sine - 0.17777777777777778) * 9
),
0.5235987755982988,
-1.5707963267948966
+ 0.17453292519943295 * sin(sine * 4.5)
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-0.5
+ 0.1 * sin(
(sine - 0.26666666666666666) * 4.5
)
- Ychg,
-0.5
),
angles(
1.7453292519943295
+ 1.0471975511965976 * sin(sine * 4.5),
1.5707963267948966
+ 0.03490658503988659 * sin(sine * 4.5),
-1.5707963267948966
)
),
deltaTime
)
--LeftArm,-0.5,0,0,4.5,170,10,-0.17777777777777778,9,0.5,0.1,-0.4444444444444444,9,-30,0,0,4.5,0,0,0,4.5,90,10,0,4.5,LeftLeg,-1,0,0,4.5,100,-60,0,4.5,-0.5,0.1,0.26666666666666666,4.5,-90,2,0,4.5,-0.5,0,0,4.5,90,0,0,4.5,Torso,0,0,0,4.5,-80,-2,0.17777777777777778,9,-0.5,0.5,0.17777777777777778,9,-0,-3,0,4.5,0,0,0,4.5,180,2,0,4.5,Head,0,0,0,4.5,-90,5,0,9,1,0.2,0,9,-0,5,0,4.5,0,0,0,4.5,180,-4,0,4.5,RightArm,0.5,0,0,4.5,170,10,-0.17777777777777778,9,0.5,0.1,-0.4444444444444444,9,30,0,0,4.5,0,0,0,4.5,-90,10,0,4.5,RightLeg,1,0,0,4.5,100,60,0,4.5,-0.5,0.1,-0.26666666666666666,4.5,90,2,0,4.5,-0.5,0,0,4.5,-90,0,0,4.5
end,
})
addmode('o', {
idle = function()
local Ychg = velYchg() / 20
local rY, lY = raycastlegs()
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1 + lY - Ychg, lY * -0.5),
angles(
-1.8325957145940461
- 0.08726646259971647 * sin(sine * 2),
-1.4835298641951802,
-1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, Ychg, 0.09 * sin(sine * 2)),
angles(
-1.3962634015954636
+ 0.08726646259971647 * sin(sine * 2),
-0.08726646259971647,
3.141592653589793
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
2.9670597283903604
+ 0.08726646259971647 * sin(sine * 1),
-1.5707963267948966
+ 0.08726646259971647
* sin((sine + 0.6) * 1),
1.5707963267948966
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1.1 + rY - Ychg, rY * -0.5),
angles(
-1.7453292519943295
- 0.08726646259971647 * sin(sine * 2),
1.5707963267948966,
1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.2217304763960306
- 0.08726646259971647
* sin((sine + 0.3) * 2),
-0.2617993877991494
- 0.08726646259971647 * sin(sine * 2),
3.141592653589793
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
2.8797932657906435
+ 0.08726646259971647 * sin(sine * 1),
1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.6) * 1),
-1.5707963267948966
)
),
deltaTime
)
--LeftLeg,-1,0,0,2,-105,-5,0,2,-1,0,0,2,-85,0,0,2,0,0,0,2,-90,0,0.75,2,Torso,0,0,0,2,-80,5,0,2,0,0,0,2,-5,0,0,2,0,0.09,0,2,180,0,0,2,LeftArm,-1,0,0,2,170,5,0,1,0.5,0,0,2,-90,5,0.6,1,0,0,0,2,90,0,0,2,RightLeg,1,0,0,2,-100,-5,0,2,-1.1,0,0,2,90,0,0,2,0,0,0,2,90,0,0.75,2,Head,0,0,0,2,-70,-5,0.3,2,1,0,0,2,-15,-5,0,2,0,0,0,2,180,0,0,2,RightArm,1,0,0,2,165,5,0,1,0.5,0,0,2,90,-5,0.6,1,0,0,0,2,-90,0,0,2
end,
walk = function()
local Ychg = velYchg() / 20
local Vfw, Vrt = velbycfrvec()
local rY, lY = raycastlegs()
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.04363323129985824 * sin(sine * 16),
0,
3.141592653589793
+ 0.08726646259971647 * sin(sine * 8)
- Vrt
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-1 - 0.3 * sin((sine + 0.15) * 8) + rY - Ychg,
rY * -0.5
),
angles(
-1.5707963267948966
- 0.6981317007977318
* sin(sine * 8)
* Vfw,
1.5707963267948966
+ 0.6981317007977318
* sin(sine * 8)
* Vrt,
1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
0.08726646259971647 * sin((sine - 0.05) * 16),
1.5707963267948966
+ 0.08726646259971647 * sin(sine * 8)
- Vrt / 3,
1.5707963267948966
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
0.08726646259971647 * sin((sine - 0.05) * 16),
-1.5707963267948966
+ 0.08726646259971647 * sin(sine * 8)
- Vrt / 3,
-1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, 0.1 * sin((sine + 0.1) * 16) + Ychg, 0),
angles(
-1.5707963267948966,
0,
3.141592653589793
- 0.08726646259971647 * sin(sine * 8)
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-1 + 0.3 * sin((sine + 0.15) * 8) + lY - Ychg,
lY * -0.5
),
angles(
1.5707963267948966
+ 0.6981317007977318
* sin(sine * 8)
* Vfw,
-1.5707963267948966
+ 0.6981317007977318
* sin(sine * 8)
* Vrt,
1.5707963267948966
)
),
deltaTime
)
--Head,0,0,0,8,-90,2.5,0,16,1,0,0,8,-0,0,0,8,0,0,0,8,180,5,0,8,RightLeg,1,0,0,8,-90,-40,0,8,-1,-0.3,0.15,8,90,40,0,8,0,0,0,8,90,0,0,8,RightArm,1,0,0,8,0,5,-0.05,16,0.5,0,0,8,90,5,0,8,0,0,0,8,90,0,0,8,LeftArm,-1,0,0,8,0,5,-0.05,16,0.5,0,0,8,-90,5,0,8,0,0,0,8,-90,0,0,8,Torso,0,0,0,8,-90,0,0,8,0,0.1,0.1,16,-0,0,0,8,0,0,0,8,180,-5,0,8,LeftLeg,-1,0,0,8,90,40,0,8,-1,0.3,0.15,8,-90,40,0,8,0,0,0,8,90,0,0,8
end,
})
addmode('p', {
idle = function()
local Ychg = velYchg() / 20
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1.5, 0.5, 0),
angles(
1.5707963267948966,
3.141592653589793,
-1.5707963267948966
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1 - Ychg, 0),
angles(0, 1.5707963267948966, 0)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1.5, 0.5, 0),
angles(
1.5707963267948966,
3.141592653589793,
1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1 - Ychg, 0),
angles(0, -1.5707963267948966, 0)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(-1.5707963267948966, 0, -3.141592653589793)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, Ychg, 0),
angles(-1.5707963267948966, 0, -3.141592653589793)
),
deltaTime
)
--RightArm,1.5,0,0,1,90,0,0,1,0.5,0,0,1,180,0,0,1,0,0,0,1,-90,0,0,1,RightLeg,1,0,0,1,0,0,0,1,-1,0,0,1,90,0,0,1,0,0,0,1,0,0,0,1,Fedora_Handle,8.657480066176504e-09,0,0,1,-6,0,0,1,-0.15052366256713867,0,0,1,0,0,0,1,-0.010221302509307861,0,0,1,0,0,0,1,LeftArm,-1.5,0,0,1,90,0,0,1,0.5,0,0,1,180,0,0,1,0,0,0,1,90,0,0,1,LeftLeg,-1,0,0,1,-0,0,0,1,-1,0,0,1,-90,0,0,1,0,0,0,1,0,0,0,1,Head,0,0,0,1,-90,0,0,1,1,0,0,1,0,0,0,1,0,0,0,1,-180,0,0,1,Torso,0,0,0,1,-90,0,0,1,0,0,0,1,0,0,0,1,0,0,0,1,-180,0,0,1
end,
})
addmode('f', {
modeEntered = function()
setWalkSpeed(25)
end,
idle = function()
velYchg()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
-3.0543261909900767
- 0.17453292519943295
* sin((sine + 1.5) * 1),
-1.5707963267948966
+ 0.08726646259971647
* sin((sine + 0.6) * 1),
-1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
3.141592653589793
- 0.08726646259971647 * sin(sine * 1),
0.3490658503988659
+ 0.08726646259971647
* sin((sine + 0.3) * 1),
-1.9198621771937625
+ 0.08726646259971647
* sin((sine + 1) * 1)
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.3089969389957472
- 0.2617993877991494
* sin((sine + 1.2) * 1),
0.08726646259971647 * sin((sine + 0.2) * 0.5),
-2.9670597283903604
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
0,
5 - 0.5 * sin((sine - 0.2) * 1),
0.2 * sin((sine - 1.2) * 1)
),
angles(
-0.08726646259971647
+ 0.17453292519943295
* sin((sine + 1.2) * 1),
0.08726646259971647 * sin(sine * 0.5),
3.141592653589793
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1, 0),
angles(
1.3962634015954636
+ 0.12217304763960307
* sin((sine + 1.5) * 1),
-1.2217304763960306
+ 0.08726646259971647
* sin((sine + 0.2) * 0.5),
1.5707963267948966
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1, 0),
angles(
1.9198621771937625
+ 0.12217304763960307
* sin((sine + 1.5) * 1),
1.2217304763960306
+ 0.08726646259971647
* sin((sine + 0.2) * 0.5),
-1.5707963267948966
)
),
deltaTime
)
--LeftArm,-1,0,0,1,-175,-10,1.5,1,0.5,0,0,1,-90,5,0.6,1,0,0,0,1,-90,0,0,1,RightArm,1,0,0,1,180,-5,0,1,0.5,0,0,1,20,5,0.3,1,0,0,0,1,-110,5,1,1,Head,0,0,0,1,-75,-15,1.2,1,1,0,0,1,-0,5,0.2,0.5,0,0,0,1,-170,0,0,1,Torso,0,0,0,1,-5,10,1.2,1,5,-0.5,-0.2,1,-0,5,0,0.5,0,0.2,-1.2,1,180,0,0,1,LeftLeg,-1,0,0,1,80,7,1.5,1,-1,0,0,1,-70,5,0.2,0.5,0,0,0,1,90,0,0,1,RightLeg,1,0,0,1,110,7,1.5,1,-1,0,0,1,70,5,0.2,0.5,0,0,0,1,-90,0,0,1
end,
walk = function()
velYchg()
local Vfw, Vrt = velbycfrvec()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
-3.0543261909900767
- 0.17453292519943295 * sin(
(sine + 1.5) * 1
)
- Vfw * 0.1,
-1.5707963267948966
+ 0.08726646259971647 * sin(
(sine + 0.6) * 1
)
+ Vrt * 0.2,
-1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
3.141592653589793
- 0.08726646259971647 * sin(sine * 1),
0.3490658503988659
+ 0.08726646259971647
* sin((sine + 0.3) * 1),
-1.9198621771937625
+ 0.08726646259971647
* sin((sine + 1) * 1)
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.3089969389957472
- 0.2617993877991494 * sin((sine + 1.2) * 1)
+ Vfw * 0.1,
0.08726646259971647 * sin((sine + 0.2) * 0.5)
- Vrt * 0.2,
-2.9670597283903604
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
0,
5 - 0.5 * sin((sine - 0.2) * 1),
0.2 * sin((sine - 1.2) * 1)
),
angles(
-0.08726646259971647
+ 0.17453292519943295 * sin(
(sine + 1.2) * 1
)
- Vfw * 0.2,
0.08726646259971647 * sin(sine * 0.5),
3.141592653589793 - Vrt * 0.2
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1, 0),
angles(
1.3962634015954636
+ 0.12217304763960307 * sin(
(sine + 1.5) * 1
)
- Vfw * 0.2,
-1.2217304763960306
+ 0.08726646259971647
* sin((sine + 0.2) * 0.5),
1.5707963267948966
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1, 0),
angles(
1.9198621771937625
+ 0.12217304763960307 * sin(
(sine + 1.5) * 1
)
- Vfw * 0.2,
1.2217304763960306
+ 0.08726646259971647
* sin((sine + 0.2) * 0.5),
-1.5707963267948966
)
),
deltaTime
)
--LeftArm,-1,0,0,1,-175,-10,1.5,1,0.5,0,0,1,-90,5,0.6,1,0,0,0,1,-90,0,0,1,RightArm,1,0,0,1,180,-5,0,1,0.5,0,0,1,20,5,0.3,1,0,0,0,1,-110,5,1,1,Head,0,0,0,1,-75,-15,1.2,1,1,0,0,1,-0,5,0.2,0.5,0,0,0,1,-170,0,0,1,Torso,0,0,0,1,-5,10,1.2,1,5,-0.5,-0.2,1,-0,5,0,0.5,0,0.2,-1.2,1,180,0,0,1,LeftLeg,-1,0,0,1,80,7,1.5,1,-1,0,0,1,-70,5,0.2,0.5,0,0,0,1,90,0,0,1,RightLeg,1,0,0,1,110,7,1.5,1,-1,0,0,1,70,5,0.2,0.5,0,0,0,1,-90,0,0,1
end,
modeLeft = function()
setWalkSpeed(16)
end,
})
addmode('g', {
idle = function()
local Ychg = velYchg() / 20
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
-0.9 + 0.4 * sin(sine * 8),
0.5,
0.5 * sin((sine + 0.25) * 4)
),
angles(
1.5707963267948966,
-1.5707963267948966
+ 1.0471975511965976 * sin(sine * 8),
1.5707963267948966
+ 0.6981317007977318
* sin((sine + 0.25) * 4)
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0.3 * sin((sine + 0.4) * 8), Ychg, 0),
angles(
-1.5707963267948966,
0.3490658503988659 * sin(sine * 8),
-3.141592653589793
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.061086523819801536
* sin((sine + 0.125) * 16),
-0.3839724354387525 * sin(sine * 8),
-3.141592653589793
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1 + 0.4 * sin((sine - 0.01) * 8) - Ychg, 0),
angles(
1.5707963267948966,
1.7453292519943295
+ 0.6981317007977318 * sin(sine * 8),
-1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1 - 0.4 * sin((sine - 0.01) * 8) - Ychg, 0),
angles(
1.5707963267948966,
-1.7453292519943295
+ 0.6981317007977318 * sin(sine * 8),
1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
0.9 + 0.4 * sin(sine * 8),
0.5,
-0.5 * sin((sine - 0.35) * 4)
),
angles(
1.5707963267948966
+ 0.6981317007977318 * sin(sine * 4),
1.5707963267948966
+ 1.0471975511965976 * sin(sine * 8),
-1.5707963267948966
+ 0.17453292519943295
* sin((sine - 0.35) * 4)
)
),
deltaTime
)
--LeftArm,-0.9,0.4,0,8,90,0,0.25,4,0.5,0,0,8,-90,60,0,8,0,0.5,0.25,4,90,40,0.25,4,Torso,0,0.3,0.4,8,-90,0,0,8,0,0,0,4,0,20,0,8,0,0,0,8,-180,0,0,8,Head,0,0,0,8,-90,3.5,0.125,16,1,0,0,8,0,-22,0,8,0,0,0,8,-180,0,0,1.1,RightLeg,1,0,0,8,90,0,0,8,-1,0.4,-0.01,8,100,40,0,8,0,0,0,8,-90,0,0,8,LeftLeg,-1,0,0,8,90,0,0,8,-1,-0.4,-0.01,8,-100,40,0,8,0,0,0,8,90,0,0,8,RightArm,0.9,0.4,0,8,90,40,0,4,0.5,0,0,8,90,60,0,8,0,-0.5,-0.35,4,-90,10,-0.35,4
end,
})
addmode('h', {
idle = function()
local Ychg = velYchg() / 20
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966,
-0.4363323129985824 * sin(sine * 8),
-3.141592653589793
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1 + 0.3 * sin(sine * 8) - Ychg, 0),
angles(
1.5707963267948966,
1.5707963267948966
+ 0.5235987755982988 * sin(sine * 8),
-1.5707963267948966
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-0.5, 1, 0),
angles(
-0.5235987755982988,
-1.5707963267948966
- 0.5235987755982988 * sin(sine * 8),
3.141592653589793
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(0.5, 1, 0),
angles(
-0.5235987755982988,
1.5707963267948966
- 0.5235987755982988 * sin(sine * 8),
3.141592653589793
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
-0.1 * sin(sine * 8),
0.2 * sin((sine + 0.1) * 16) + Ychg,
0
),
angles(
-1.5707963267948966,
0.2617993877991494 * sin(sine * 8),
-3.141592653589793
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1 - 0.3 * sin(sine * 8) - Ychg, 0),
angles(
1.5707963267948966,
-1.5707963267948966
+ 0.5235987755982988 * sin(sine * 8),
1.5707963267948966
)
),
deltaTime
)
--Head,0,0,0,8,-90,0,0,8,1,0,0,8,0,-25,0,8,0,0,0,8,-180,0,0,8,RightLeg,1,0,0,8,90,0,0,8,-1,0.3,0,8,90,30,0,8,0,0,0,8,-90,0,0,8,LeftArm,-0.5,0,0,8,-30,0,0,8,1,0,0,8,-90,-30,0,8,0,0,0,8,180,0,0,8,RightArm,0.5,0,0,8,-30,0,0,8,1,0,0,16,90,-30,0,8,0,0,0,8,180,0,0,8,Torso,0,-0.1,0,8,-90,0,0,8,0,0.2,0.1,16,0,15,0,8,0,0,0,8,-180,0,0,8,LeftLeg,-1,0,0,8,90,0,0,8,-1,-0.3,0,8,-90,30,0,8,0,0,0,8,90,0,0,8,Fedora_Handle,8.657480066176504e-09,0,0,8,-6,0,0,8,-0.15052366256713867,0,0,8,0,0,0,8,-0.010221302509307861,0,0,8,0,0,0,8
end,
})
addmode('j', {
idle = function()
local Ychg = velYchg() / 20
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-0.8, -1, -0.1),
angles(0.17453292519943295, -0.6981317007977318, 0)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1.2, 0.5, 0),
angles(
-0.3490658503988659
+ 0.08726646259971647
* sin((sine + 0.1) * 4),
0,
0.6981317007977318
+ 0.08726646259971647
* sin((sine + 0.1) * 4)
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1.1, -1, 0),
angles(
1.5707963267948966,
1.7453292519943295,
-1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.08726646259971647
* sin((sine + 0.1) * 4),
0,
2.792526803190927
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
0,
-1.7 + 0.5 * sin(sine * 4) + Ychg,
0.15 * sin(sine * 4)
),
angles(
3.3161255787892263
+ 0.17453292519943295 * sin(sine * 4),
0,
3.6651914291880923
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
0.8 + 0.4 * sin(sine * 4),
0.6 + 0.1 * sin(sine * 4),
0.4 - 0.25 * sin(sine * 4)
),
angles(
2.9670597283903604,
2.2689280275926285
- 0.17453292519943295 * sin(sine * 4),
-1.4835298641951802
- 0.17453292519943295 * sin(sine * 4)
)
),
deltaTime
)
--GalaxyBeautifulHair_Handle,-0.15000000596046448,0,0,1,0,0,0,1,0.10000000149011612,0,0,1,0,0,0,1,0,0,0,1,0,0,0,1,LeftLeg,-0.8,0,0,4,10,0,0,4,-1,0,0,4,-40,0,0,4,-0.1,0,0,4,0,0,0,4,LeftArm,-1.2,0,0,4,-20,5,0.1,4,0.5,0,0,4,0,0,0,4,0,0,0,4,40,5,0.1,4,Fedora_Handle,8.657480066176504e-09,0,0,1,-6,0,0,1,-0.15052366256713867,0,0,1,0,0,0,1,-0.010221302509307861,0,0,1,0,0,0,1,ValkyrieHelm_Handle,8.658389560878277e-09,0,0,1,-15,0,0,1,-0.2433757781982422,0,0,1,0,0,0,1,-0.2657628059387207,0,0,1,0,0,0,1,RightLeg,1.1,0,0,4,90,0,0,4,-1,0,0,4,100,0,0,4,0,0,0,4,-90,0,0,4,BlackIronAntlers_Handle,8.658389560878277e-09,0,0,1,0,0,0,1,-0.6500000953674316,0,0,1,0,0,0,1,0.19972775876522064,0,0,1,0,0,0,1,DevAwardsAdurite_Handle,0,0,0,1,0,0,0,1,-0.25,0,0,1,0,0,0,1,0,0,0,1,0,0,0,1,SilverthornAntlers_Handle,8.658389560878277e-09,0,0,1,0,0,0,1,-0.6500000953674316,0,0,1,0,0,0,1,0.19972775876522064,0,0,1,0,0,0,1,Head,0,0,0,4,-90,5,0.1,4,1,0,0,4,-0,0,0,4,0,0,0,4,160,0,0,4,Torso,0,0,0,4,190,10,0,4,-1.70,0.5,0,4,-0,0,0,4,0,0.15,0,4,210,0,0,4,RightArm,0.8,0.4,0,4,170,0,0,4,0.6,0.1,0,4,130,-10,0,4,0.4,-0.25,0,4,-85,-10,0,4
end,
})
addmode('k', {
idle = function()
local Ychg = velYchg() / 20
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.6580627893946132
- 0.08726646259971647
* sin(
(sine + 0.3333333333333333) * 12
),
-0.08726646259971647 * sin((sine + 0.2) * 6),
3.141592653589793
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-0.5
- 0.5 * sin(
(sine + 0.39999999999999997) * 12
)
- Ychg,
-0.5
),
angles(
1.7453292519943295
- 1.0471975511965976 * sin(sine * 6),
-1.5707963267948966
+ 0.1308996938995747 * sin(sine * 6),
1.5707963267948966
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-0.5
- 0.5 * sin(
(sine + 0.39999999999999997) * 12
)
- Ychg,
-0.5
),
angles(
1.7453292519943295
+ 1.0471975511965976 * sin(sine * 6),
1.5707963267948966
+ 0.1308996938995747 * sin(sine * 6),
-1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
0,
-0.5
+ 0.3 * sin(
(sine + 0.16666666666666666) * 12
)
+ Ychg,
0
),
angles(
-1.3962634015954636
+ 0.08726646259971647
* sin(
(sine + 0.3333333333333333) * 12
),
0.08726646259971647
* sin((sine + 0.06666666666666667) * 6),
3.141592653589793
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
-0.8 - 0.1 * sin(sine * 6),
0.5 + 0.1 * sin(sine * 6),
-0.2
),
angles(
3.141592653589793
- 0.17453292519943295
* sin(
(sine + 0.39999999999999997) * 12
),
-0.17453292519943295,
1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
0.8 - 0.1 * sin(sine * 6),
0.5 - 0.1 * sin(sine * 6),
-0.2
),
angles(
3.141592653589793
- 0.17453292519943295
* sin(
(sine + 0.39999999999999997) * 12
),
0.17453292519943295,
-1.5707963267948966
)
),
deltaTime
)
--GalaxyBeautifulHair_Handle,-0.15000000596046448,0,0,1.5,0,0,0,1.5,0.10000000149011612,0,0,1.5,0,0,0,1.5,0,0,0,1.5,0,0,0,1.5,Head,0,0,0,6,-95,-5,0.3333333333333333,12,1,0,0,6,-0,-5,0.2,6,0,0,0,6,180,0,0,6,ValkyrieHelm_Handle,8.658389560878277e-09,0,0,1.5,-15,0,0,1.5,-0.2433757781982422,0,0,1.5,0,0,0,1.5,-0.2657628059387207,0,0,1.5,0,0,0,1.5,SilverthornAntlers_Handle,8.658389560878277e-09,0,0,1.5,0,0,0,1.5,-0.6500000953674316,0,0,1.5,0,0,0,1.5,0.19972775876522064,0,0,1.5,0,0,0,1.5,BlackIronAntlers_Handle,8.658389560878277e-09,0,0,1.5,0,0,0,1.5,-0.6500000953674316,0,0,1.5,0,0,0,1.5,0.19972775876522064,0,0,1.5,0,0,0,1.5,Fedora_Handle,8.657480066176504e-09,0,0,1.5,-6,0,0,1.5,-0.15052366256713867,0,0,1.5,0,0,0,1.5,-0.010221302509307861,0,0,1.5,0,0,0,1.5,LeftLeg,-1,0,0,6,100,-60,0,6,-0.5,-0.5,0.39999999999999997,12,-90,7.5,0,6,-0.5,0,0,6,90,0,0,6,EyelessSmileHead_Handle,-0.00043487548828125,0,0,1.5,180,0,0,1.5,0.6000361442565918,0,0,1.5,0,0,0,1.5,0.0003204345703125,0,0,1.5,180,0,0,1.5,RightLeg,1,0,0,6,100,60,0,6,-0.5,-0.5,0.39999999999999997,12,90,7.5,0,6,-0.5,0,0,6,-90,0,0,6,DevAwardsAdurite_Handle,0,0,0,1.5,0,0,0,1.5,-0.25,0,0,1.5,0,0,0,1.5,0,0,0,1.5,0,0,0,1.5,Torso,0,0,0,6,-80,5,0.3333333333333333,12,-0.5,0.3,0.16666666666666666,12,-0,5,0.06666666666666667,6,0,0,0,6,180,0,0,6,LeftArm,-0.8,-0.1,0,6,180,-10,0.39999999999999997,12,0.5,0.1,0,6,-10,0,0,6,-0.2,0,0,6,90,0,0,6,RightArm,0.8,-0.1,0,6,180,-10,0.39999999999999997,12,0.5,-0.1,0,6,10,0,0,6,-0.2,0,0,6,-90,0,0,6
end,
})
local idleL = function()
local Ychg = velYchg() / 20
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -0.9 + 0.2 * sin((sine - 0.2) * 16) - Ychg, 0.25),
angles(
0,
0.7853981633974483,
0.4363323129985824
- 1.1344640137963142
* sin((sine - 0.0875) * 8)
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
0.15 * sin((sine - 0.1) * 8),
0.54 * sin(sine * 16) + Ychg,
0
),
angles(
-1.5707963267948966,
-0.08726646259971647 * sin((sine - 0.0785) * 8),
3.141592653589793
- 0.08726646259971647
* sin((sine - 0.0785) * 8)
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
0.75 + 0.07 * sin((sine - 0.0785) * 8),
1.3 + 0.1 * sin((sine - 0.0875) * 16),
0
),
angles(
1.3962634015954636,
2.356194490192345
- 0.06981317007977318
* sin((sine - 0.0785) * 8),
1.2217304763960306
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.08726646259971647
* sin((sine - 0.1) * 16),
0.12217304763960307 * sin((sine - 0.0785) * 8),
3.141592653589793
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -0.9 + 0.2 * sin((sine - 0.2) * 16) - Ychg, 0.25),
angles(
0,
-0.7853981633974483,
-0.4363323129985824
- 1.1344640137963142
* sin((sine - 0.0875) * 8)
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.45 + 0.05 * sin((sine - 0.0875) * 16), -0.2),
angles(
2.0943951023931953
+ 0.17453292519943295
* sin((sine - 0.0875) * 16),
-0.5235987755982988,
1.5707963267948966
+ 0.17453292519943295
* sin((sine - 0.0875) * 16)
)
),
deltaTime
)
--MW_animatorProgressSave: RightLeg,1,0,0,16,0,0,0,8,-0.9,0.2,-0.2,16,45,0,-0.0875,8,0.25,0,0,16,25,-65,-0.0875,8,Fedora_Handle,8.657480066176504e-09,0,0,2,-6,0,0,2,-0.15052366256713867,0,0,2,0,0,0,2,-0.010221302509307861,0,0,2,0,0,0,2,Torso,0,0.15,-0.1,8,-90,0,0,16,0,0.54,0,16,-0,-5,-0.0785,8,0,0,0,16,180,-5,-0.0785,8,RightArm,0.75,0.07,-0.0785,8,80,0,0,16,1.3,0.1,-0.0875,16,135,-4,-0.0785,8,0,0,0,16,70,0,0,16,Head,0,0,0,16,-90,5,-0.1,16,1,0,0,16,-0,7,-0.0785,8,0,0,0,16,180,0,0,16,LeftLeg,-1,0,0,16,0,0,0,8,-0.9,0.2,-0.2,16,-45,0,0,8,0.25,0,0,16,-25,-65,-0.0875,8,Bandana_Handle,3.9362930692732334e-09,0,0,2,0,0,0,2,0.3000001907348633,0,0,2,0,0,0,2,-0.6002722978591919,0,0,2,0,0,0,2,LeftArm,-1,0,0,16,120,10,-0.0875,16,0.45,0.05,-0.0875,16,-30,0,0,16,-0.2,0,0,16,90,10,-0.0875,16
end
addmode('l', {
modeEntered = function()
setWalkSpeed(10)
end,
idle = idleL,
walk = idleL,
modeLeft = function()
setWalkSpeed(16)
end,
})
end)
btn('nameless animations V7', function()
local t = reanimate()
if type(t) ~= 'table' then
return
end
local raycastlegs = t.raycastlegs
local velbycfrvec = t.velbycfrvec
local velchgbycfrvec = t.velchgbycfrvec
local addmode = t.addmode
local getJoint = t.getJoint
local RootJoint = getJoint('RootJoint')
local RightShoulder = getJoint('Right Shoulder')
local LeftShoulder = getJoint('Left Shoulder')
local RightHip = getJoint('Right Hip')
local LeftHip = getJoint('Left Hip')
local Neck = getJoint('Neck')
addmode('default', {
idle = function()
local rY, lY = raycastlegs()
local Cfw, Crt = velchgbycfrvec()
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.3 + 0.1 * sin(sine * 2), -0.1),
angles(
-0.5235987755982988
+ 0.05235987755982989
* sin((sine + 1.5) * 2),
1.0471975511965976
+ 0.08726646259971647
* sin((sine + 0.5) * 2),
0.5235987755982988
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.6580627893946132
+ 0.08726646259971647
* sin((sine + 0.6) * 2),
0,
3.141592653589793
+ 0.2617993877991494
* sin((sine - 1.2) * 1)
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(Crt * 3, 0.1 * sin(sine * 2), Cfw * -3),
angles(
-1.5707963267948966
+ 0.08726646259971647 * sin(sine * 2)
- Cfw,
Crt,
3.141592653589793
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-1 - 0.1 * sin(sine * 2) + rY,
0.1 * sin(sine * 2) - rY * 0.5
),
angles(
-0.6981317007977318
- 0.08726646259971647 * sin(sine * 2),
1.0471975511965976,
0.5235987755982988
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.6 + 0.1 * sin(sine * 2), 0),
angles(
3.141592653589793
+ 0.05235987755982989
* sin((sine + 0.5) * 2),
-2.705260340591211
+ 0.017453292519943295
* sin((sine + 1.5) * 2),
-1.2217304763960306
+ 0.05235987755982989
* sin((sine + 1.5) * 2)
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-1 - 0.1 * sin(sine * 2) + lY,
0.1 * sin(sine * 2) - lY * 0.5
),
angles(
-0.3490658503988659
- 0.08726646259971647 * sin(sine * 2),
-1.0471975511965976,
-0.5235987755982988
)
),
deltaTime
)
--RightArm,1,0,0,2,-30,3,1.5,2,0.3,0.1,0,2,60,5,0.5,2,-0.1,0,0,2,30,0,0,2,Head,0,0,0,2,-95,5,0.6,2,1,0,0,2,-0,0,0,1,0,0,0,2,180,15,-1.2,1,Torso,0,0,0,2,-90,5,0,2,0,0.1,0,2,-0,0,0,2,0,0,0,2,180,0,0,2,RightLeg,1,0,0,2,-40,-5,0,2,-1,-0.1,0,2,60,0,0,2,0,0.1,0,2,30,0,0,2,Meshes/TrollFaceHeadAccessory_Handle,0.01043701171875,0,0,1,0,0,0,1,0.43610429763793945,0,0,1,0,0,0,1,-0.01102447509765625,0,0,1,0,0,0,1,LeftArm,-1,0,0,2,180,3,0.5,2,0.6,0.1,0,2,-155,1,1.5,2,0,0,0,2,-70,3,1.5,2,LeftLeg,-1,0,0,2,-20,-5,0,2,-1,-0.1,0,2,-60,0,0,2,0,0.1,0,2,-30,0,0,2
end,
walk = function()
local Vfw, Vrt = velbycfrvec()
local rY, lY = raycastlegs()
local Cfw, Crt = velchgbycfrvec()
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(Crt * 3, -0.2 + 0.2 * sin(sine * 16), Cfw * -3),
angles(
-1.6580627893946132
+ 0.04363323129985824 * sin(sine * 16)
- Vfw * 0.15
- Cfw,
0.03490658503988659 * sin(sine * 8)
+ Vrt * 0.15
+ Crt,
-3.141592653589793
- 0.08726646259971647 * sin(
(sine + 0.25) * 8
)
- Vrt * 0.1
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-0.8 + 0.4 * sin((sine + 0.125) * 8) + rY,
-0.15 * Vfw
+ 0.4 * sin((sine + 10) * 8) * Vfw
+ rY * -0.5
),
angles(
1.3962634015954636
+ 0.6981317007977318
* sin(sine * 8)
* Vfw,
1.5707963267948966
+ 0.6981317007977318
* sin(sine * 8)
* Vrt,
-1.5707963267948966
+ 0.2617993877991494 * sin(sine * 8)
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.35 - 0.1 * sin(sine * 8), 0),
angles(
0.5235987755982988 * sin(sine * 8) * Vfw,
-1.5707963267948966
- 0.5235987755982988
* sin(sine * 8)
* Vfw,
-0.5235987755982988 * sin(sine * 8) * Vfw
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.35 + 0.1 * sin(sine * 8), 0),
angles(
-0.5235987755982988 * sin(sine * 8) * Vfw,
1.5707963267948966
- 0.5235987755982988
* sin(sine * 8)
* Vfw,
-0.5235987755982988 * sin(sine * 8) * Vfw
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-0.8 - 0.4 * sin((sine + 0.125) * 8) + lY,
-0.15 * Vfw
- 0.4 * sin((sine + 10) * 8) * Vfw
+ lY * -0.5
),
angles(
1.3962634015954636
- 0.6981317007977318
* sin(sine * 8)
* Vfw,
-1.5707963267948966
- 0.6981317007977318
* sin(sine * 8)
* Vrt,
1.5707963267948966
+ 0.2617993877991494 * sin(sine * 8)
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.08726646259971647 * sin(
(sine + 10) * 16
)
+ Vfw * 0.15,
-0.08726646259971647 * sin(sine * 8)
+ Vrt * -0.1,
3.141592653589793
- 0.05235987755982989 * sin((sine + 5) * 8)
- Vrt * 0.5
)
),
deltaTime
)
--Torso,0,0,0,8,-95,2.5,0,16,-0.2,0.2,0,16,0,5,0,8,0,0,0,8,-180,-5,0.25,8,RightArm,1,0,0,1,0,-30,0,8,0.35,0.1,0,8,90,-30,0,8,0,0,0,8,0,-30,0,8,RightLeg,1,0,0,8,80,40,0,8,-0.8,0.4,0.125,8,90,40,0,8,-0.15,0.4,10,8,-90,15,0,8,LeftLeg,-1,0,0,8,80,-40,0,8,-0.8,-0.4,0.125,8,-90,-40,0,8,-0.15,-0.4,10,8,90,15,0,8,Head,0,0,0,1,-90,2.5,10,16,1,0,0,1,-0,-5,0,8,0,0,0,1,180,-3,5,8,LeftArm,-1,0,0,1,0,30,0,8,0.35,-0.1,0,8,-90,-30,0,8,0,-0.4,0,8,0,-30,0,8
end,
jump = function()
local Vfw, Vrt = velbycfrvec()
local Cfw, Crt = velchgbycfrvec()
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(Crt * 3, 0, Cfw * -3),
angles(
-1.4835298641951802 + Vfw * 0.1 - Cfw,
Vrt * -0.05 + Crt,
-3.141592653589793
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
4.014257279586958
- 0.08726646259971647
* sin((sine + 0.5) * 4),
1.7453292519943295
+ 0.08726646259971647
* sin((sine + 0.25) * 4),
-1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1, 0),
angles(
1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.5) * 4),
-1.6580627893946132
+ 0.06981317007977318
* sin((sine + 0.25) * 4),
1.5707963267948966
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
4.014257279586958
- 0.08726646259971647
* sin((sine + 0.5) * 4),
-1.7453292519943295
- 0.08726646259971647
* sin((sine + 0.25) * 4),
1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.3962634015954636,
0,
-3.141592653589793 - Vrt
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1, 0),
angles(
1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.5) * 4),
1.6580627893946132
- 0.06981317007977318
* sin((sine + 0.25) * 4),
-1.5707963267948966
)
),
deltaTime
)
--Torso,0,0,0,4,-85,0,0,4,0,0,0,4,0,0,0,4,0,0,0,4,-180,0,0,4,RightArm,1,0,0,4,230,-5,0.5,4,0.5,0,0,4,100,5,0.25,4,0,0,0,4,-90,0,0,4,LeftLeg,-1,0,0,4,90,-5,0.5,4,-1,0,0,4,-95,4,0.25,4,0,0,0,4,90,0,0,4,LeftArm,-1,0,0,4,230,-5,0.5,4,0.5,0,0,4,-100,-5,0.25,4,0,0,0,4,90,0,0,4,Head,0,0,0,4,-80,0,0.5,4,1,0,0,4,0,0,0.25,4,0,0,0,4,-180,0,0,4,RightLeg,1,0,0,4,90,-5,0.5,4,-1,0,0,4,95,-4,0.25,4,0,0,0,4,-90,0,0,4
end,
fall = function()
local Vfw, Vrt = velbycfrvec()
local Cfw, Crt = velchgbycfrvec()
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(Crt * 3, 0, Cfw * -3),
angles(
-1.6580627893946132 + Vfw * 0.1 - Cfw,
Vrt * -0.05 + Crt,
-3.141592653589793
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
4.014257279586958
- 0.08726646259971647
* sin((sine + 0.5) * 4),
1.7453292519943295
+ 0.08726646259971647
* sin((sine + 0.25) * 4),
-1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1, 0),
angles(
1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.5) * 4),
-1.6580627893946132
+ 0.06981317007977318
* sin((sine + 0.25) * 4),
1.5707963267948966
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
4.014257279586958
- 0.08726646259971647
* sin((sine + 0.5) * 4),
-1.7453292519943295
- 0.08726646259971647
* sin((sine + 0.25) * 4),
1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.7453292519943295,
0,
-3.141592653589793 - Vrt
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1, 0),
angles(
1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.5) * 4),
1.6580627893946132
- 0.06981317007977318
* sin((sine + 0.25) * 4),
-1.5707963267948966
)
),
deltaTime
)
--Torso,0,0,0,4,-95,0,0,4,0,0,0,4,0,0,0,4,0,0,0,4,-180,0,0,4,RightArm,1,0,0,4,230,-5,0.5,4,0.5,0,0,4,100,5,0.25,4,0,0,0,4,-90,0,0,4,LeftLeg,-1,0,0,4,90,-5,0.5,4,-1,0,0,4,-95,4,0.25,4,0,0,0,4,90,0,0,4,LeftArm,-1,0,0,4,230,-5,0.5,4,0.5,0,0,4,-100,-5,0.25,4,0,0,0,4,90,0,0,4,Head,0,0,0,4,-100,0,0.5,4,1,0,0,4,0,0,0.25,4,0,0,0,4,-180,0,0,4,RightLeg,1,0,0,4,90,-5,0.5,4,-1,0,0,4,95,-4,0.25,4,0,0,0,4,-90,0,0,4
end,
})
addmode('q', {
idle = function()
local Cfw, Crt = velchgbycfrvec()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.75, -0.2),
angles(
2.705260340591211
- 0.08726646259971647
* sin((sine + 0.1) * 2),
-2.792526803190927,
-0.6981317007977318
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.75, -0.2),
angles(
2.705260340591211
- 0.08726646259971647
* sin((sine + 0.1) * 2),
2.792526803190927,
0.6981317007977318
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.9198621771937625
- 0.10471975511965978
* sin((sine + 0.3) * 2),
0,
3.141592653589793
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(Crt * 3, -2.45 - 0.05 * sin(sine * 2), Cfw * -3),
angles(
0.03490658503988659 * sin(sine * 2) - Cfw,
Crt,
3.141592653589793
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1, 0),
angles(
1.3962634015954636
- 0.03490658503988659 * sin(sine * 2),
1.3089969389957472,
-0.9599310885968813
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1, 0),
angles(
1.5707963267948966
- 0.03490658503988659 * sin(sine * 2),
-1.3089969389957472,
1.5707963267948966
)
),
deltaTime
)
--LeftArm,-1,0,0,2,155,-5,0.1,2,0.75,0,0,2,-160,0,0,2,-0.2,0,0,2,-40,0,0,2,RightArm,1,0,0,2,155,-5,0.1,2,0.75,0,0,2,160,0,0,2,-0.2,0,0,2,40,0,0,2,Head,0,0,0,2,-110,-6,0.3,2,1,0,0,2,-0,0,0,2,0,0,0,2,180,0,0,2,Torso,0,0,0,2,0,2,0,2,-2.45,-0.05,0,2,-0,0,0,2,0,0,0,2,180,0,0,2,RightLeg,1,0,0,2,80,-2,0,2,-1,0,0,2,75,0,0,2,0,0,0,2,-55,0,0,2,LeftLeg,-1,0,0,2,90,-2,0,2,-1,0,0,2,-75,0,0,2,0,0,0,2,90,0,0,2
end,
})
addmode('e', {
idle = function()
local Cfw, Crt = velchgbycfrvec()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
-0.9,
0.4 + 0.1 * sin(sine * 2),
0.3 - 0.15 * sin(sine * 2)
),
angles(
-1.0471975511965976
- 0.12217304763960307 * sin(sine * 2),
-1.3962634015954636,
-0.6981317007977318
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
Crt * 3,
-1.85 - 0.1 * sin((sine + 0.2) * 2),
Cfw * -3
),
angles(
-1.3962634015954636
+ 0.03490658503988659 * sin(sine * 2)
- Cfw,
-0.08726646259971647 + Crt,
3.141592653589793
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
1,
0.4 + 0.1 * sin(sine * 2),
0.2 - 0.15 * sin(sine * 2)
),
angles(
0.6108652381980153
- 0.12217304763960307 * sin(sine * 2),
1.2217304763960306,
-0.7853981633974483
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.6580627893946132
- 0.03490658503988659
* sin((sine + 0.6) * 2),
0.10471975511965978
+ 0.06981317007977318 * sin(sine * 0.66),
3.141592653589793
+ 0.3490658503988659 * sin(sine * 0.66)
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
0.2 + 0.15 * sin((sine + 0.2) * 2),
-0.7 + 0.1 * sin(sine * 2)
),
angles(
1.4835298641951802
+ 0.03490658503988659 * sin(sine * 2),
1.4835298641951802,
-1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -0.75 + 0.1 * sin((sine + 0.2) * 2), -0.5),
angles(
1.3962634015954636
- 0.03490658503988659 * sin(sine * 2),
-1.6580627893946132,
0
)
),
deltaTime
)
--LeftArm,-0.9,0,0,2,-60,-7,0,2,0.4,0.1,0,2,-80,0,0,2,0.3,-0.15,0,2,-40,0,0,2,Torso,0,0,0,2,-80,2,0,2,-1.85,-0.1,0.2,2,-5,0,0,2,0,0,0,2,180,0,0,2,RightArm,1,0,0,2,35,-7,0,2,0.4,0.1,0,2,70,0,0,2,0.2,-0.15,0,2,-45,0,0,2,Head,0,0,0,2,-95,-2,0.6,2,1,0,0,2,6,4,0,0.66,0,0,0,2,180,20,0,0.66,RightLeg,1,0,0,2,85,2,0,2,0.2,0.15,0.2,2,85,0,0,2,-0.7,0.1,0,2,-90,0,0,2,LeftLeg,-1,0,0,2,80,-2,0,2,-0.75,0.1,0.2,2,-95,0,0,2,-0.5,0,0,2,0,0,0,2
end,
})
addmode('r', {
idle = function()
local Cfw, Crt = velchgbycfrvec()
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -0.9 - 0.2 * sin(sine * 2), 0),
angles(
1.5707963267948966,
1.6580627893946132
- 0.17453292519943295 * sin(sine + 0.8),
-1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
0.3 * sin(sine + 0.8) + Crt * 3,
-0.1 + 0.2 * sin(sine * 2),
Cfw * -3
),
angles(
-1.5707963267948966 - Cfw,
Crt,
-3.141592653589793
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.08726646259971647
* sin((sine - 0.5) * 2),
0.08726646259971647 * sin(sine - 1),
-3.141592653589793
+ 0.2617993877991494 * sin(sine * 5)
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
-1 + 0.1 * sin(sine * 7),
0.2 - 0.1 * sin(sine + 0.8),
-0.25
),
angles(
1.5707963267948966
+ 0.5235987755982988 * sin(sine * 7),
-0.6981317007977318,
0.3490658503988659 * sin(sine * 7)
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -0.9 - 0.2 * sin(sine * 2), 0),
angles(
1.5707963267948966,
-1.6580627893946132
- 0.17453292519943295 * sin(sine + 0.8),
1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
1 + 0.1 * sin(sine * 7),
0.2 + 0.1 * sin(sine + 0.8),
-0.25
),
angles(
1.5707963267948966
- 0.5235987755982988 * sin(sine * 7),
0.6981317007977318,
0.3490658503988659 * sin(sine * 7)
)
),
deltaTime
)
--RightLeg,1,0,0,1,90,0,0,1,-0.9,-0.2,0,2,95,-10,0.8,1,0,0,0,1,-90,0,0,1,Torso,0,0.3,0.8,1,-90,0,0,1,-0.1,0.2,0,2,0,0,0,1,0,0,0,1,-180,0,0,1,Head,0,0,0,1,-90,5,-0.5,2,1,0,0,1,0,5,-1,1,0,0,0,1,-180,15,0,5,Fedora_Handle,8.657480066176504e-09,0,0,1,-6,0,0,1,-0.15052366256713867,0,0,1,0,0,0,1,-0.010221302509307861,0,0,1,0,0,0,1,LeftArm,-1,0.1,0,7,90,30,0,7,0.2,-0.1,0.8,1,-40,0,0,1,-0.25,0,0,1,0,20,0,7,LeftLeg,-1,0,0,1,90,0,0,1,-0.9,-0.2,0,2,-95,-10,0.8,1,0,0,0,1,90,0,0,1,RightArm,1,0.1,0,7,90,-30,0,7,0.2,0.1,0.8,1,40,0,0,1,-0.25,0,0,1,-0,20,0,7
end,
})
addmode('t', {
idle = function()
local Cfw, Crt = velchgbycfrvec()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
1.5707963267948966,
-1.6580627893946132
+ 0.08726646259971647
* sin((sine - 0.3) * 4),
1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1 + 0.15 * sin((sine - 0.4) * 4), 1.42, 0),
angles(
1.5707963267948966,
1.4835298641951802
- 0.3490658503988659
* sin((sine - 0.4) * 4),
1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.4835298641951802,
0.04363323129985824
- 0.08726646259971647
* sin((sine + 0.1) * 4),
-3.141592653589793
+ 0.04363323129985824 * sin(sine * 4)
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0.1 * sin(sine * 4) + Crt * 3, 0, Cfw * -3),
angles(
-1.5707963267948966 - Cfw,
-0.08726646259971647
+ 0.08726646259971647 * sin(sine * 4)
+ Crt,
-3.141592653589793
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1.1 + 0.1 * sin(sine * 4), 0),
angles(
1.5707963267948966,
1.5707963267948966
+ 0.08726646259971647 * sin(sine * 4),
-1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1 - 0.02 * sin(sine * 4),
-0.925 - 0.07 * sin(sine * 4),
0
),
angles(
1.5707963267948966,
-1.7453292519943295
+ 0.08726646259971647 * sin(sine * 4),
1.5707963267948966
)
),
deltaTime
)
--LeftArm,-1,0,0,4,90,0,0,4,0.5,0,0,4,-95,5,-0.3,4,0,0,0,4,90,0,0,4,RightArm,1,0.15,-0.4,4,90,0,0,4,1.42,0,0,4,85,-20,-0.4,4,0,0,0,4,90,0,0,4,Head,0,0,0,4,-85,0,0,4,1,0,0,4,2.5,-5,0.1,4,0,0,0,4,-180,2.5,0,4,Torso,0,0.1,0,4,-90,0,0,4,0,0,0,4,-5,5,0,4,0,0,0,4,-180,0,0,4,RightLeg,1,0,0,4,90,0,0,4,-1.1,0.1,0,4,90,5,0,4,0,0,0,4,-90,0,0,4,LeftLeg,-1,-0.02,0,4,90,0,0,4,-0.925,-0.07,0,4,-100,5,0,4,0,0,0,4,90,0,0,4
end,
})
addmode('y', {
idle = function()
local Cfw, Crt = velchgbycfrvec()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1.5, 0.5, 0),
angles(
-1.7453292519943295,
0.17453292519943295
- 0.04363323129985824 * sin(sine * 2),
-1.4835298641951802
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -0.9000000953674316 - 0.1 * sin(sine * 2), 0),
angles(
-1.3962634015954636,
1.3962634015954636,
1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1.0000001192092896 - 0.1 * sin(sine * 2), 0),
angles(
-1.5707963267948966,
-1.3962634015954636,
-1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-2.0943951023931953
+ 0.08726646259971647
* sin((sine - 1) * 2),
-0.08726646259971647,
2.792526803190927
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 1.2000000476837158, 0),
angles(
2.6179938779914944
+ 0.08726646259971647
* sin((sine - 1) * 2),
0.6981317007977318,
-1.3962634015954636
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(Crt * 3, 0.1 * sin(sine * 2), Cfw * -3),
angles(
-1.6580627893946132 - Cfw,
0.08726646259971647 + Crt,
3.0543261909900767
)
),
deltaTime
)
--LeftArm,-1.5,0,0,2,-100,0,0,2,0.5,0,0,2,10,-2.5,0,2,0,0,0,2,-85,0,0,2,RightLeg,1,0,0,2,-80,0,0,2,-0.9000000953674316,-0.1,0,2,80,0,0,2,0,0,0,2,90,0,0,2,LeftLeg,-1,0,0,2,-90,0,0,2,-1.0000001192092896,-0.1,0,2,-80,0,0,2,0,0,0,2,-90,0,0,2,Fedora_Handle,8.657480066176504e-09,0,0,2,-6,0,0,2,-0.15052366256713867,0,0,2,0,0,0,2,-0.010221302509307861,0,0,2,0,0,0,2,Head,0,0,0,2,-120,5,-1,2,1,0,0,2,-5,0,0,2,0,0,0,2,160,0,0,2,RightArm,1,0,0,2,150,5,-1,2,1.2000000476837158,0,0,2,40,0,0,2,0,0,0,2,-80,0,0,2,Torso,0,0,0,2,-95,0,0,2,0,0.1,0,2,5,0,0,2,0,0,0,2,175,0,0,2
end,
})
addmode('u', {
idle = function()
local Cfw, Crt = velchgbycfrvec()
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(Crt * 3, 0.75 + 0.25 * sin(sine * 2), Cfw * -3),
angles(
-1.5707963267948966 - Cfw,
Crt,
3.141592653589793
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1.5 - 0.1 * sin((sine + 0.2) * 2), 0),
angles(
-1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.4) * 2),
0,
3.141592653589793
+ 0.3490658503988659 * sin(sine * 0.66)
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-0.5 - 1 * sin((sine + 0.2) * 2.2),
-0.75 - 0.25 * sin(sine * 2),
1 * sin((sine + 0.95) * 2.2)
),
angles(0, -1.5707963267948966, 0)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
0.5 + 1 * sin((sine + 0.2) * 2.2),
-0.75 - 0.25 * sin(sine * 2),
-1 * sin((sine + 0.95) * 2.2)
),
angles(0, 1.5707963267948966, 0)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
-0.5 - 1.85 * sin(sine * 2),
0.8 - 0.5 * sin(sine * 2),
-1.85 * sin((sine + 0.75) * 2)
),
angles(0, 1.5707963267948966, 0)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
0.5 + 1.85 * sin(sine * 2),
0.8 - 0.5 * sin(sine * 2),
1.85 * sin((sine + 0.75) * 2)
),
angles(0, -1.5707963267948966, 0)
),
deltaTime
)
--Torso,0,0,0,2,-90,0,0,2,0.75,0.25,0,2,-0,0,0,2,0,0,0,2,180,0,0,2,Fedora_Handle,8.657480066176504e-09,0,0,2,-6,0,0,2,-0.15052366256713867,0,0,2,0,0,0,2,-0.010221302509307861,0,0,2,0,0,0,2,Head,0,0,0,2,-90,-5,0.4,2,1.5,-0.1,0.2,2,-0,0,0,2,0,0,0,2,180,20,0,0.66,LeftLeg,-0.5,-1,0.2,2.2,-0,0,0,2,-0.75,-0.25,0,2,-90,0,0,2,0,1,0.95,2.2,0,0,0,2,RightLeg,0.5,1,0.2,2.2,0,0,0,2,-0.75,-0.25,0,2,90,0,0,2,0,-1,0.95,2.2,0,0,0,2,RightArm,-0.5,-1.85,0,2,0,0,0,2,0.8,-0.5,0,2,90,0,0,2,0,-1.85,0.75,2,0,0,0,2,LeftArm,0.5,1.85,0,2,-0,0,0,2,0.8,-0.5,0,2,-90,0,0,2,0,1.85,0.75,2,0,0,0,2
end,
})
addmode('i', {
idle = function()
local Cfw, Crt = velchgbycfrvec()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
-0.5,
0.5 + 0.1 * sin((sine - 0.4444444444444444) * 9),
0
),
angles(
2.9670597283903604
+ 0.17453292519943295
* sin(
(sine - 0.17777777777777778) * 9
),
-0.5235987755982988,
1.5707963267948966
+ 0.17453292519943295 * sin(sine * 4.5)
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-0.5
+ 0.1
* sin(
(sine + 0.26666666666666666) * 4.5
),
-0.5
),
angles(
1.7453292519943295
- 1.0471975511965976 * sin(sine * 4.5),
-1.5707963267948966
+ 0.03490658503988659 * sin(sine * 4.5),
1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
Crt * 3,
-0.5
+ 0.5
* sin(
(sine + 0.17777777777777778) * 9
),
Cfw * -3
),
angles(
-1.3962634015954636
- 0.03490658503988659 * sin(
(sine + 0.17777777777777778) * 9
)
- Cfw,
-0.05235987755982989 * sin(sine * 4.5) + Crt,
3.141592653589793
+ 0.03490658503988659 * sin(sine * 4.5)
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1 + 0.2 * sin(sine * 9), 0),
angles(
-1.5707963267948966
+ 0.08726646259971647 * sin(sine * 9),
0.08726646259971647 * sin(sine * 4.5),
3.141592653589793
- 0.06981317007977318 * sin(sine * 4.5)
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
0.5,
0.5 + 0.1 * sin((sine - 0.4444444444444444) * 9),
0
),
angles(
2.9670597283903604
+ 0.17453292519943295
* sin(
(sine - 0.17777777777777778) * 9
),
0.5235987755982988,
-1.5707963267948966
+ 0.17453292519943295 * sin(sine * 4.5)
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-0.5
+ 0.1
* sin(
(sine - 0.26666666666666666) * 4.5
),
-0.5
),
angles(
1.7453292519943295
+ 1.0471975511965976 * sin(sine * 4.5),
1.5707963267948966
+ 0.03490658503988659 * sin(sine * 4.5),
-1.5707963267948966
)
),
deltaTime
)
--LeftArm,-0.5,0,0,4.5,170,10,-0.17777777777777778,9,0.5,0.1,-0.4444444444444444,9,-30,0,0,4.5,0,0,0,4.5,90,10,0,4.5,LeftLeg,-1,0,0,4.5,100,-60,0,4.5,-0.5,0.1,0.26666666666666666,4.5,-90,2,0,4.5,-0.5,0,0,4.5,90,0,0,4.5,Torso,0,0,0,4.5,-80,-2,0.17777777777777778,9,-0.5,0.5,0.17777777777777778,9,-0,-3,0,4.5,0,0,0,4.5,180,2,0,4.5,Head,0,0,0,4.5,-90,5,0,9,1,0.2,0,9,-0,5,0,4.5,0,0,0,4.5,180,-4,0,4.5,RightArm,0.5,0,0,4.5,170,10,-0.17777777777777778,9,0.5,0.1,-0.4444444444444444,9,30,0,0,4.5,0,0,0,4.5,-90,10,0,4.5,RightLeg,1,0,0,4.5,100,60,0,4.5,-0.5,0.1,-0.26666666666666666,4.5,90,2,0,4.5,-0.5,0,0,4.5,-90,0,0,4.5
end,
})
addmode('o', {
idle = function()
local rY, lY = raycastlegs()
local Cfw, Crt = velchgbycfrvec()
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1 + lY, lY * -0.5),
angles(
-1.8325957145940461
- 0.08726646259971647 * sin(sine * 2),
-1.4835298641951802,
-1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(Crt, 0, 0.09 * sin(sine * 2) - Cfw * 3),
angles(
-1.3962634015954636
+ 0.08726646259971647 * sin(sine * 2)
- Cfw,
-0.08726646259971647 + Crt,
3.141592653589793
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
2.9670597283903604
+ 0.08726646259971647 * sin(sine * 1),
-1.5707963267948966
+ 0.08726646259971647
* sin((sine + 0.6) * 1),
1.5707963267948966
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1.1 + rY, rY * -0.5),
angles(
-1.7453292519943295
- 0.08726646259971647 * sin(sine * 2),
1.5707963267948966,
1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.2217304763960306
- 0.08726646259971647
* sin((sine + 0.3) * 2),
-0.2617993877991494
- 0.08726646259971647 * sin(sine * 2),
3.141592653589793
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
2.8797932657906435
+ 0.08726646259971647 * sin(sine * 1),
1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.6) * 1),
-1.5707963267948966
)
),
deltaTime
)
--LeftLeg,-1,0,0,2,-105,-5,0,2,-1,0,0,2,-85,0,0,2,0,0,0,2,-90,0,0.75,2,Torso,0,0,0,2,-80,5,0,2,0,0,0,2,-5,0,0,2,0,0.09,0,2,180,0,0,2,LeftArm,-1,0,0,2,170,5,0,1,0.5,0,0,2,-90,5,0.6,1,0,0,0,2,90,0,0,2,RightLeg,1,0,0,2,-100,-5,0,2,-1.1,0,0,2,90,0,0,2,0,0,0,2,90,0,0.75,2,Head,0,0,0,2,-70,-5,0.3,2,1,0,0,2,-15,-5,0,2,0,0,0,2,180,0,0,2,RightArm,1,0,0,2,165,5,0,1,0.5,0,0,2,90,-5,0.6,1,0,0,0,2,-90,0,0,2
end,
walk = function()
local Vfw, Vrt = velbycfrvec()
local rY, lY = raycastlegs()
local Cfw, Crt = velchgbycfrvec()
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.04363323129985824 * sin(sine * 16),
0,
3.141592653589793
+ 0.08726646259971647 * sin(sine * 8)
- Vrt
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-1 - 0.3 * sin((sine + 0.15) * 8) + rY,
rY * -0.5
),
angles(
-1.5707963267948966
- 0.6981317007977318
* sin(sine * 8)
* Vfw,
1.5707963267948966
+ 0.6981317007977318
* sin(sine * 8)
* Vrt,
1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
0.08726646259971647 * sin((sine - 0.05) * 16),
1.5707963267948966
+ 0.08726646259971647 * sin(sine * 8)
- Vrt / 3,
1.5707963267948966
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
0.08726646259971647 * sin((sine - 0.05) * 16),
-1.5707963267948966
+ 0.08726646259971647 * sin(sine * 8)
- Vrt / 3,
-1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(Crt * 3, 0.1 * sin((sine + 0.1) * 16), Cfw * -3),
angles(
-1.5707963267948966 - Cfw,
Crt,
3.141592653589793
- 0.08726646259971647 * sin(sine * 8)
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-1 + 0.3 * sin((sine + 0.15) * 8) + lY,
lY * -0.5
),
angles(
1.5707963267948966
+ 0.6981317007977318
* sin(sine * 8)
* Vfw,
-1.5707963267948966
+ 0.6981317007977318
* sin(sine * 8)
* Vrt,
1.5707963267948966
)
),
deltaTime
)
--Head,0,0,0,8,-90,2.5,0,16,1,0,0,8,-0,0,0,8,0,0,0,8,180,5,0,8,RightLeg,1,0,0,8,-90,-40,0,8,-1,-0.3,0.15,8,90,40,0,8,0,0,0,8,90,0,0,8,RightArm,1,0,0,8,0,5,-0.05,16,0.5,0,0,8,90,5,0,8,0,0,0,8,90,0,0,8,LeftArm,-1,0,0,8,0,5,-0.05,16,0.5,0,0,8,-90,5,0,8,0,0,0,8,-90,0,0,8,Torso,0,0,0,8,-90,0,0,8,0,0.1,0.1,16,-0,0,0,8,0,0,0,8,180,-5,0,8,LeftLeg,-1,0,0,8,90,40,0,8,-1,0.3,0.15,8,-90,40,0,8,0,0,0,8,90,0,0,8
end,
})
addmode('p', {
idle = function()
local Cfw, Crt = velchgbycfrvec()
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1.5, 0.5, 0),
angles(
1.5707963267948966,
3.141592653589793,
-1.5707963267948966
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(cf(1, -1, 0), angles(0, 1.5707963267948966, 0)),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1.5, 0.5, 0),
angles(
1.5707963267948966,
3.141592653589793,
1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(cf(-1, -1, 0), angles(0, -1.5707963267948966, 0)),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(-1.5707963267948966, 0, -3.141592653589793)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(Crt * 3, 0, Cfw * -3),
angles(
-1.5707963267948966 - Cfw,
Crt,
-3.141592653589793
)
),
deltaTime
)
--RightArm,1.5,0,0,1,90,0,0,1,0.5,0,0,1,180,0,0,1,0,0,0,1,-90,0,0,1,RightLeg,1,0,0,1,0,0,0,1,-1,0,0,1,90,0,0,1,0,0,0,1,0,0,0,1,Fedora_Handle,8.657480066176504e-09,0,0,1,-6,0,0,1,-0.15052366256713867,0,0,1,0,0,0,1,-0.010221302509307861,0,0,1,0,0,0,1,LeftArm,-1.5,0,0,1,90,0,0,1,0.5,0,0,1,180,0,0,1,0,0,0,1,90,0,0,1,LeftLeg,-1,0,0,1,-0,0,0,1,-1,0,0,1,-90,0,0,1,0,0,0,1,0,0,0,1,Head,0,0,0,1,-90,0,0,1,1,0,0,1,0,0,0,1,0,0,0,1,-180,0,0,1,Torso,0,0,0,1,-90,0,0,1,0,0,0,1,0,0,0,1,0,0,0,1,-180,0,0,1
end,
})
addmode('f', {
idle = function()
local Cfw, Crt = velchgbycfrvec()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
-3.0543261909900767
- 0.17453292519943295
* sin((sine + 1.5) * 1),
-1.5707963267948966
+ 0.08726646259971647
* sin((sine + 0.6) * 1),
-1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
3.141592653589793
- 0.08726646259971647 * sin(sine * 1),
0.3490658503988659
+ 0.08726646259971647
* sin((sine + 0.3) * 1),
-1.9198621771937625
+ 0.08726646259971647
* sin((sine + 1) * 1)
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.3089969389957472
- 0.2617993877991494
* sin((sine + 1.2) * 1),
0.08726646259971647 * sin((sine + 0.2) * 0.5),
-2.9670597283903604
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
Crt * 3,
5 - 0.5 * sin((sine - 0.2) * 1),
0.2 * sin((sine - 1.2) * 1) - Cfw * 3
),
angles(
-0.08726646259971647
+ 0.17453292519943295 * sin(
(sine + 1.2) * 1
)
- Cfw,
0.08726646259971647 * sin(sine * 0.5) + Crt,
3.141592653589793
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1, 0),
angles(
1.3962634015954636
+ 0.12217304763960307
* sin((sine + 1.5) * 1),
-1.2217304763960306
+ 0.08726646259971647
* sin((sine + 0.2) * 0.5),
1.5707963267948966
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1, 0),
angles(
1.9198621771937625
+ 0.12217304763960307
* sin((sine + 1.5) * 1),
1.2217304763960306
+ 0.08726646259971647
* sin((sine + 0.2) * 0.5),
-1.5707963267948966
)
),
deltaTime
)
--LeftArm,-1,0,0,1,-175,-10,1.5,1,0.5,0,0,1,-90,5,0.6,1,0,0,0,1,-90,0,0,1,RightArm,1,0,0,1,180,-5,0,1,0.5,0,0,1,20,5,0.3,1,0,0,0,1,-110,5,1,1,Head,0,0,0,1,-75,-15,1.2,1,1,0,0,1,-0,5,0.2,0.5,0,0,0,1,-170,0,0,1,Torso,0,0,0,1,-5,10,1.2,1,5,-0.5,-0.2,1,-0,5,0,0.5,0,0.2,-1.2,1,180,0,0,1,LeftLeg,-1,0,0,1,80,7,1.5,1,-1,0,0,1,-70,5,0.2,0.5,0,0,0,1,90,0,0,1,RightLeg,1,0,0,1,110,7,1.5,1,-1,0,0,1,70,5,0.2,0.5,0,0,0,1,-90,0,0,1
end,
walk = function()
local Vfw, Vrt = velbycfrvec()
local Cfw, Crt = velchgbycfrvec()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
-3.0543261909900767
- 0.17453292519943295 * sin(
(sine + 1.5) * 1
)
- Vfw * 0.1,
-1.5707963267948966
+ 0.08726646259971647 * sin(
(sine + 0.6) * 1
)
+ Vrt * 0.2,
-1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
3.141592653589793
- 0.08726646259971647 * sin(sine * 1),
0.3490658503988659
+ 0.08726646259971647
* sin((sine + 0.3) * 1),
-1.9198621771937625
+ 0.08726646259971647
* sin((sine + 1) * 1)
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.3089969389957472
- 0.2617993877991494 * sin((sine + 1.2) * 1)
+ Vfw * 0.1,
0.08726646259971647 * sin((sine + 0.2) * 0.5)
- Vrt * 0.2,
-2.9670597283903604
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
Crt * 3,
5 - 0.5 * sin((sine - 0.2) * 1),
0.2 * sin((sine - 1.2) * 1) - Cfw * 3
),
angles(
-0.08726646259971647
+ 0.17453292519943295 * sin(
(sine + 1.2) * 1
)
- Vfw * 0.2
- Cfw,
0.08726646259971647 * sin(sine * 0.5) + Crt,
3.141592653589793 - Vrt * 0.2
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1, 0),
angles(
1.3962634015954636
+ 0.12217304763960307 * sin(
(sine + 1.5) * 1
)
- Vfw * 0.2,
-1.2217304763960306
+ 0.08726646259971647
* sin((sine + 0.2) * 0.5),
1.5707963267948966
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1, 0),
angles(
1.9198621771937625
+ 0.12217304763960307 * sin(
(sine + 1.5) * 1
)
- Vfw * 0.2,
1.2217304763960306
+ 0.08726646259971647
* sin((sine + 0.2) * 0.5),
-1.5707963267948966
)
),
deltaTime
)
--LeftArm,-1,0,0,1,-175,-10,1.5,1,0.5,0,0,1,-90,5,0.6,1,0,0,0,1,-90,0,0,1,RightArm,1,0,0,1,180,-5,0,1,0.5,0,0,1,20,5,0.3,1,0,0,0,1,-110,5,1,1,Head,0,0,0,1,-75,-15,1.2,1,1,0,0,1,-0,5,0.2,0.5,0,0,0,1,-170,0,0,1,Torso,0,0,0,1,-5,10,1.2,1,5,-0.5,-0.2,1,-0,5,0,0.5,0,0.2,-1.2,1,180,0,0,1,LeftLeg,-1,0,0,1,80,7,1.5,1,-1,0,0,1,-70,5,0.2,0.5,0,0,0,1,90,0,0,1,RightLeg,1,0,0,1,110,7,1.5,1,-1,0,0,1,70,5,0.2,0.5,0,0,0,1,-90,0,0,1
end,
})
addmode('g', {
idle = function()
local Cfw, Crt = velchgbycfrvec()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
-0.9 + 0.4 * sin(sine * 8),
0.5,
0.5 * sin((sine + 0.25) * 4)
),
angles(
1.5707963267948966,
-1.5707963267948966
+ 1.0471975511965976 * sin(sine * 8),
1.5707963267948966
+ 0.6981317007977318
* sin((sine + 0.25) * 4)
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
0.3 * sin((sine + 0.4) * 8) + Crt * 3,
0,
Cfw * -3
),
angles(
-1.5707963267948966 - Cfw,
0.3490658503988659 * sin(sine * 8) + Crt,
-3.141592653589793
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.061086523819801536
* sin((sine + 0.125) * 16),
-0.3839724354387525 * sin(sine * 8),
-3.141592653589793
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1 + 0.4 * sin((sine - 0.01) * 8), 0),
angles(
1.5707963267948966,
1.7453292519943295
+ 0.6981317007977318 * sin(sine * 8),
-1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1 - 0.4 * sin((sine - 0.01) * 8), 0),
angles(
1.5707963267948966,
-1.7453292519943295
+ 0.6981317007977318 * sin(sine * 8),
1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
0.9 + 0.4 * sin(sine * 8),
0.5,
-0.5 * sin((sine - 0.35) * 4)
),
angles(
1.5707963267948966
+ 0.6981317007977318 * sin(sine * 4),
1.5707963267948966
+ 1.0471975511965976 * sin(sine * 8),
-1.5707963267948966
+ 0.17453292519943295
* sin((sine - 0.35) * 4)
)
),
deltaTime
)
--LeftArm,-0.9,0.4,0,8,90,0,0.25,4,0.5,0,0,8,-90,60,0,8,0,0.5,0.25,4,90,40,0.25,4,Torso,0,0.3,0.4,8,-90,0,0,8,0,0,0,4,0,20,0,8,0,0,0,8,-180,0,0,8,Head,0,0,0,8,-90,3.5,0.125,16,1,0,0,8,0,-22,0,8,0,0,0,8,-180,0,0,1.1,RightLeg,1,0,0,8,90,0,0,8,-1,0.4,-0.01,8,100,40,0,8,0,0,0,8,-90,0,0,8,LeftLeg,-1,0,0,8,90,0,0,8,-1,-0.4,-0.01,8,-100,40,0,8,0,0,0,8,90,0,0,8,RightArm,0.9,0.4,0,8,90,40,0,4,0.5,0,0,8,90,60,0,8,0,-0.5,-0.35,4,-90,10,-0.35,4
end,
})
addmode('h', {
idle = function()
local Cfw, Crt = velchgbycfrvec()
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966,
-0.4363323129985824 * sin(sine * 8),
-3.141592653589793
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1 + 0.3 * sin(sine * 8), 0),
angles(
1.5707963267948966,
1.5707963267948966
+ 0.5235987755982988 * sin(sine * 8),
-1.5707963267948966
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-0.5, 1, 0),
angles(
-0.5235987755982988,
-1.5707963267948966
- 0.5235987755982988 * sin(sine * 8),
3.141592653589793
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(0.5, 1, 0),
angles(
-0.5235987755982988,
1.5707963267948966
- 0.5235987755982988 * sin(sine * 8),
3.141592653589793
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
-0.1 * sin(sine * 8) + Crt * 3,
0.2 * sin((sine + 0.1) * 16),
Cfw * -3
),
angles(
-1.5707963267948966 - Cfw,
0.2617993877991494 * sin(sine * 8) + Crt,
-3.141592653589793
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1 - 0.3 * sin(sine * 8), 0),
angles(
1.5707963267948966,
-1.5707963267948966
+ 0.5235987755982988 * sin(sine * 8),
1.5707963267948966
)
),
deltaTime
)
--Head,0,0,0,8,-90,0,0,8,1,0,0,8,0,-25,0,8,0,0,0,8,-180,0,0,8,RightLeg,1,0,0,8,90,0,0,8,-1,0.3,0,8,90,30,0,8,0,0,0,8,-90,0,0,8,LeftArm,-0.5,0,0,8,-30,0,0,8,1,0,0,8,-90,-30,0,8,0,0,0,8,180,0,0,8,RightArm,0.5,0,0,8,-30,0,0,8,1,0,0,16,90,-30,0,8,0,0,0,8,180,0,0,8,Torso,0,-0.1,0,8,-90,0,0,8,0,0.2,0.1,16,0,15,0,8,0,0,0,8,-180,0,0,8,LeftLeg,-1,0,0,8,90,0,0,8,-1,-0.3,0,8,-90,30,0,8,0,0,0,8,90,0,0,8,Fedora_Handle,8.657480066176504e-09,0,0,8,-6,0,0,8,-0.15052366256713867,0,0,8,0,0,0,8,-0.010221302509307861,0,0,8,0,0,0,8
end,
})
addmode('j', {
idle = function()
local Cfw, Crt = velchgbycfrvec()
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-0.8, -1, -0.1),
angles(0.17453292519943295, -0.6981317007977318, 0)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1.2, 0.5, 0),
angles(
-0.3490658503988659
+ 0.08726646259971647
* sin((sine + 0.1) * 4),
0,
0.6981317007977318
+ 0.08726646259971647
* sin((sine + 0.1) * 4)
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1.1, -1, 0),
angles(
1.5707963267948966,
1.7453292519943295,
-1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.08726646259971647
* sin((sine + 0.1) * 4),
0,
2.792526803190927
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
Crt * 3,
-1.7 + 0.5 * sin(sine * 4),
0.15 * sin(sine * 4) - Cfw * 3
),
angles(
3.3161255787892263
+ 0.17453292519943295 * sin(sine * 4)
- Cfw,
Crt,
3.6651914291880923
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
0.8 + 0.4 * sin(sine * 4),
0.6 + 0.1 * sin(sine * 4),
0.4 - 0.25 * sin(sine * 4)
),
angles(
2.9670597283903604,
2.2689280275926285
- 0.17453292519943295 * sin(sine * 4),
-1.4835298641951802
- 0.17453292519943295 * sin(sine * 4)
)
),
deltaTime
)
--GalaxyBeautifulHair_Handle,-0.15000000596046448,0,0,1,0,0,0,1,0.10000000149011612,0,0,1,0,0,0,1,0,0,0,1,0,0,0,1,LeftLeg,-0.8,0,0,4,10,0,0,4,-1,0,0,4,-40,0,0,4,-0.1,0,0,4,0,0,0,4,LeftArm,-1.2,0,0,4,-20,5,0.1,4,0.5,0,0,4,0,0,0,4,0,0,0,4,40,5,0.1,4,Fedora_Handle,8.657480066176504e-09,0,0,1,-6,0,0,1,-0.15052366256713867,0,0,1,0,0,0,1,-0.010221302509307861,0,0,1,0,0,0,1,ValkyrieHelm_Handle,8.658389560878277e-09,0,0,1,-15,0,0,1,-0.2433757781982422,0,0,1,0,0,0,1,-0.2657628059387207,0,0,1,0,0,0,1,RightLeg,1.1,0,0,4,90,0,0,4,-1,0,0,4,100,0,0,4,0,0,0,4,-90,0,0,4,BlackIronAntlers_Handle,8.658389560878277e-09,0,0,1,0,0,0,1,-0.6500000953674316,0,0,1,0,0,0,1,0.19972775876522064,0,0,1,0,0,0,1,DevAwardsAdurite_Handle,0,0,0,1,0,0,0,1,-0.25,0,0,1,0,0,0,1,0,0,0,1,0,0,0,1,SilverthornAntlers_Handle,8.658389560878277e-09,0,0,1,0,0,0,1,-0.6500000953674316,0,0,1,0,0,0,1,0.19972775876522064,0,0,1,0,0,0,1,Head,0,0,0,4,-90,5,0.1,4,1,0,0,4,-0,0,0,4,0,0,0,4,160,0,0,4,Torso,0,0,0,4,190,10,0,4,-1.70,0.5,0,4,-0,0,0,4,0,0.15,0,4,210,0,0,4,RightArm,0.8,0.4,0,4,170,0,0,4,0.6,0.1,0,4,130,-10,0,4,0.4,-0.25,0,4,-85,-10,0,4
end,
})
addmode('k', {
idle = function()
local Cfw, Crt = velchgbycfrvec()
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.6580627893946132
- 0.08726646259971647
* sin(
(sine + 0.3333333333333333) * 12
),
-0.08726646259971647 * sin((sine + 0.2) * 6),
3.141592653589793
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-0.5
- 0.5
* sin(
(sine + 0.39999999999999997) * 12
),
-0.5
),
angles(
1.7453292519943295
- 1.0471975511965976 * sin(sine * 6),
-1.5707963267948966
+ 0.1308996938995747 * sin(sine * 6),
1.5707963267948966
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-0.5
- 0.5
* sin(
(sine + 0.39999999999999997) * 12
),
-0.5
),
angles(
1.7453292519943295
+ 1.0471975511965976 * sin(sine * 6),
1.5707963267948966
+ 0.1308996938995747 * sin(sine * 6),
-1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
Crt * 3,
-0.5
+ 0.3
* sin(
(sine + 0.16666666666666666) * 12
),
Cfw * -3
),
angles(
-1.3962634015954636
+ 0.08726646259971647 * sin(
(sine + 0.3333333333333333) * 12
)
- Cfw,
0.08726646259971647
* sin((sine + 0.06666666666666667) * 6)
+ Crt,
3.141592653589793
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
-0.8 - 0.1 * sin(sine * 6),
0.5 + 0.1 * sin(sine * 6),
-0.2
),
angles(
3.141592653589793
- 0.17453292519943295
* sin(
(sine + 0.39999999999999997) * 12
),
-0.17453292519943295,
1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
0.8 - 0.1 * sin(sine * 6),
0.5 - 0.1 * sin(sine * 6),
-0.2
),
angles(
3.141592653589793
- 0.17453292519943295
* sin(
(sine + 0.39999999999999997) * 12
),
0.17453292519943295,
-1.5707963267948966
)
),
deltaTime
)
--GalaxyBeautifulHair_Handle,-0.15000000596046448,0,0,1.5,0,0,0,1.5,0.10000000149011612,0,0,1.5,0,0,0,1.5,0,0,0,1.5,0,0,0,1.5,Head,0,0,0,6,-95,-5,0.3333333333333333,12,1,0,0,6,-0,-5,0.2,6,0,0,0,6,180,0,0,6,ValkyrieHelm_Handle,8.658389560878277e-09,0,0,1.5,-15,0,0,1.5,-0.2433757781982422,0,0,1.5,0,0,0,1.5,-0.2657628059387207,0,0,1.5,0,0,0,1.5,SilverthornAntlers_Handle,8.658389560878277e-09,0,0,1.5,0,0,0,1.5,-0.6500000953674316,0,0,1.5,0,0,0,1.5,0.19972775876522064,0,0,1.5,0,0,0,1.5,BlackIronAntlers_Handle,8.658389560878277e-09,0,0,1.5,0,0,0,1.5,-0.6500000953674316,0,0,1.5,0,0,0,1.5,0.19972775876522064,0,0,1.5,0,0,0,1.5,Fedora_Handle,8.657480066176504e-09,0,0,1.5,-6,0,0,1.5,-0.15052366256713867,0,0,1.5,0,0,0,1.5,-0.010221302509307861,0,0,1.5,0,0,0,1.5,LeftLeg,-1,0,0,6,100,-60,0,6,-0.5,-0.5,0.39999999999999997,12,-90,7.5,0,6,-0.5,0,0,6,90,0,0,6,EyelessSmileHead_Handle,-0.00043487548828125,0,0,1.5,180,0,0,1.5,0.6000361442565918,0,0,1.5,0,0,0,1.5,0.0003204345703125,0,0,1.5,180,0,0,1.5,RightLeg,1,0,0,6,100,60,0,6,-0.5,-0.5,0.39999999999999997,12,90,7.5,0,6,-0.5,0,0,6,-90,0,0,6,DevAwardsAdurite_Handle,0,0,0,1.5,0,0,0,1.5,-0.25,0,0,1.5,0,0,0,1.5,0,0,0,1.5,0,0,0,1.5,Torso,0,0,0,6,-80,5,0.3333333333333333,12,-0.5,0.3,0.16666666666666666,12,-0,5,0.06666666666666667,6,0,0,0,6,180,0,0,6,LeftArm,-0.8,-0.1,0,6,180,-10,0.39999999999999997,12,0.5,0.1,0,6,-10,0,0,6,-0.2,0,0,6,90,0,0,6,RightArm,0.8,-0.1,0,6,180,-10,0.39999999999999997,12,0.5,-0.1,0,6,10,0,0,6,-0.2,0,0,6,-90,0,0,6
end,
})
addmode('l', {
idle = function()
local Cfw, Crt = velchgbycfrvec()
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.04363323129985824
* sin((sine + 0.1) * 1),
-0.17453292519943295 * sin((sine + 0.1) * 5),
-3.141592653589793
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-1 + 0.2 * sin(sine * 5),
-0.2 + 0.2 * sin(sine * 5)
),
angles(
2.181661564992912
- 0.8726646259971648 * sin(sine * 5),
1.9198621771937625
- 0.3490658503988659 * sin(sine * 5),
-1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(0.7, 0.8, 0),
angles(
1.0471975511965976
+ 0.03490658503988659 * sin(sine * 10),
2.0943951023931953
+ 0.10471975511965978
* sin((sine + 0.1) * 5),
1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-1 - 0.2 * sin(sine * 5),
-0.2 - 0.2 * sin(sine * 5)
),
angles(
2.181661564992912
+ 0.8726646259971648 * sin(sine * 5),
-1.9198621771937625
- 0.3490658503988659 * sin(sine * 5),
1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
Crt * 3,
0.15 + 0.4 * sin((sine - 0.5) * 10),
Cfw * -3
),
angles(
-1.4835298641951802 - Cfw,
0.17453292519943295 * sin(sine * 5) + Crt,
-3.141592653589793
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-0.7, 0.5, -0.3),
angles(
1.7453292519943295,
-0.8726646259971648,
1.5707963267948966
)
),
deltaTime
)
--Head,0,0,0,5,-90,2.5,0.1,1,1,0,0,4,0,-10,0.1,5,0,0,0,4,-180,0,0,4,RightLeg,1,0,0,4,125,-50,0,5,-1,0.2,0,5,110,-20,0,5,-0.2,0.2,0,5,-90,0,0,4,RightArm,0.7,0,0,4,60,2,0,10,0.8,0,0,4,120,6,0.1,5,0,0,0,4,90,0,0,4,LeftLeg,-1,0,0,4,125,50,0,5,-1,-0.2,0,5,-110,-20,0,5,-0.2,-0.2,0,5,90,0,0,4,Torso,0,0,0,4,-85,0,0,4,0.15,0.4,-0.5,10,0,10,0,5,0,0,0,4,-180,0,0,4,LeftArm,-0.7,0,0,4,100,0,0,4,0.5,0,0,4,-50,0,0,4,-0.3,0,0,4,90,0,0,4
end,
})
addmode('x', {
idle = function()
local Cfw, Crt = velchgbycfrvec()
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(cf(1, 0.5, 0), angles(0, 1.5707963267948966, 0)),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(-1.5707963267948966, 0, 3.141592653589793)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(cf(1, -1, 0), angles(0, 1.5707963267948966, 0)),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(cf(-1, -1, 0), angles(0, -1.5707963267948966, 0)),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(Crt * 3, 0, Cfw * -3),
angles(
-1.5707963267948966 - Cfw,
Crt,
3.141592653589793
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(cf(-1, 0.5, 0), angles(0, -1.5707963267948966, 0)),
deltaTime
)
--RightArm,1,0,0,1,0,0,0,1,0.5,0,0,1,90,0,0,1,0,0,0,1,0,0,0,1,Fedora_Handle,8.657480066176504e-09,0,0,1,-6,0,0,1,-0.15052366256713867,0,0,1,0,0,0,1,-0.010221302509307861,0,0,1,0,0,0,1,Head,0,0,0,1,-90,0,0,1,1,0,0,1,-0,0,0,1,0,0,0,1,180,0,0,1,RightLeg,1,0,0,1,0,0,0,1,-1,0,0,1,90,0,0,1,0,0,0,1,0,0,0,1,LeftLeg,-1,0,0,1,-0,0,0,1,-1,0,0,1,-90,0,0,1,0,0,0,1,0,0,0,1,Torso,0,0,0,1,-90,0,0,1,0,0,0,1,-0,0,0,1,0,0,0,1,180,0,0,1,LeftArm,-1,0,0,1,-0,0,0,1,0.5,0,0,1,-90,0,0,1,0,0,0,1,0,0,0,1
end,
walk = function()
local Cfw, Crt = velchgbycfrvec()
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(cf(1, 0.5, 0), angles(0, 1.5707963267948966, 0)),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(-1.5707963267948966, 0, 3.141592653589793)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(cf(1, -1, 0), angles(0, 1.5707963267948966, 0)),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(cf(-1, -1, 0), angles(0, -1.5707963267948966, 0)),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(Crt * 3, 0, Cfw * -3),
angles(
-1.5707963267948966 - Cfw,
Crt,
3.141592653589793
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(cf(-1, 0.5, 0), angles(0, -1.5707963267948966, 0)),
deltaTime
)
--RightArm,1,0,0,1,0,0,0,1,0.5,0,0,1,90,0,0,1,0,0,0,1,0,0,0,1,Fedora_Handle,8.657480066176504e-09,0,0,1,-6,0,0,1,-0.15052366256713867,0,0,1,0,0,0,1,-0.010221302509307861,0,0,1,0,0,0,1,Head,0,0,0,1,-90,0,0,1,1,0,0,1,-0,0,0,1,0,0,0,1,180,0,0,1,RightLeg,1,0,0,1,0,0,0,1,-1,0,0,1,90,0,0,1,0,0,0,1,0,0,0,1,LeftLeg,-1,0,0,1,-0,0,0,1,-1,0,0,1,-90,0,0,1,0,0,0,1,0,0,0,1,Torso,0,0,0,1,-90,0,0,1,0,0,0,1,-0,0,0,1,0,0,0,1,180,0,0,1,LeftArm,-1,0,0,1,-0,0,0,1,0.5,0,0,1,-90,0,0,1,0,0,0,1,0,0,0,1
end,
})
end)
btn('nameless animations V6', function()
local t = reanimate()
if type(t) ~= 'table' then
return
end
local raycastlegs = t.raycastlegs
local velbycfrvec = t.velbycfrvec
local addmode = t.addmode
local getJoint = t.getJoint
local RootJoint = getJoint('RootJoint')
local RightShoulder = getJoint('Right Shoulder')
local LeftShoulder = getJoint('Left Shoulder')
local RightHip = getJoint('Right Hip')
local LeftHip = getJoint('Left Hip')
local Neck = getJoint('Neck')
addmode('default', {
idle = function()
local rY, lY = raycastlegs()
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.3 + 0.1 * sin(sine * 2), -0.1),
angles(
-0.5235987755982988
+ 0.05235987755982989
* sin((sine + 1.5) * 2),
1.0471975511965976
+ 0.08726646259971647
* sin((sine + 0.5) * 2),
0.5235987755982988
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.6580627893946132
+ 0.08726646259971647
* sin((sine + 0.6) * 2),
0,
3.141592653589793
+ 0.2617993877991494
* sin((sine - 1.2) * 1)
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, 0.1 * sin(sine * 2), 0),
angles(
-1.5707963267948966
+ 0.08726646259971647 * sin(sine * 2),
0,
3.141592653589793
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-1 - 0.1 * sin(sine * 2) + rY,
0.1 * sin(sine * 2) - rY * 0.5
),
angles(
-0.6981317007977318
- 0.08726646259971647 * sin(sine * 2),
1.0471975511965976,
0.5235987755982988
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.6 + 0.1 * sin(sine * 2), 0),
angles(
3.141592653589793
+ 0.05235987755982989
* sin((sine + 0.5) * 2),
-2.705260340591211
+ 0.017453292519943295
* sin((sine + 1.5) * 2),
-1.2217304763960306
+ 0.05235987755982989
* sin((sine + 1.5) * 2)
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-1 - 0.1 * sin(sine * 2) + lY,
0.1 * sin(sine * 2) - lY * 0.5
),
angles(
-0.3490658503988659
- 0.08726646259971647 * sin(sine * 2),
-1.0471975511965976,
-0.5235987755982988
)
),
deltaTime
)
--RightArm,1,0,0,2,-30,3,1.5,2,0.3,0.1,0,2,60,5,0.5,2,-0.1,0,0,2,30,0,0,2,Head,0,0,0,2,-95,5,0.6,2,1,0,0,2,-0,0,0,1,0,0,0,2,180,15,-1.2,1,Torso,0,0,0,2,-90,5,0,2,0,0.1,0,2,-0,0,0,2,0,0,0,2,180,0,0,2,RightLeg,1,0,0,2,-40,-5,0,2,-1,-0.1,0,2,60,0,0,2,0,0.1,0,2,30,0,0,2,Meshes/TrollFaceHeadAccessory_Handle,0.01043701171875,0,0,1,0,0,0,1,0.43610429763793945,0,0,1,0,0,0,1,-0.01102447509765625,0,0,1,0,0,0,1,LeftArm,-1,0,0,2,180,3,0.5,2,0.6,0.1,0,2,-155,1,1.5,2,0,0,0,2,-70,3,1.5,2,LeftLeg,-1,0,0,2,-20,-5,0,2,-1,-0.1,0,2,-60,0,0,2,0,0.1,0,2,-30,0,0,2
end,
walk = function()
local fw, rt = velbycfrvec()
local rY, lY = raycastlegs()
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, -0.2 + 0.2 * sin(sine * 16), 0),
angles(
-1.6580627893946132
+ 0.04363323129985824 * sin(sine * 16)
- fw * 0.15,
0.03490658503988659 * sin(sine * 8) + rt * 0.15,
-3.141592653589793
- 0.08726646259971647 * sin(
(sine + 0.25) * 8
)
- rt * 0.1
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-0.8 + 0.4 * sin((sine + 0.125) * 8) + rY,
-0.15 * fw
+ 0.4 * sin((sine + 10) * 8) * fw
+ rY * -0.5
),
angles(
1.3962634015954636
+ 0.6981317007977318
* sin(sine * 8)
* fw,
1.5707963267948966
+ 0.6981317007977318
* sin(sine * 8)
* rt,
-1.5707963267948966
+ 0.2617993877991494 * sin(sine * 8)
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.35 - 0.1 * sin(sine * 8), 0),
angles(
0.5235987755982988 * sin(sine * 8) * fw,
-1.5707963267948966
- 0.5235987755982988
* sin(sine * 8)
* fw,
-0.5235987755982988 * sin(sine * 8) * fw
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.35 + 0.1 * sin(sine * 8), 0),
angles(
-0.5235987755982988 * sin(sine * 8) * fw,
1.5707963267948966
- 0.5235987755982988
* sin(sine * 8)
* fw,
-0.5235987755982988 * sin(sine * 8) * fw
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-0.8 - 0.4 * sin((sine + 0.125) * 8) + lY,
-0.15 * fw
- 0.4 * sin((sine + 10) * 8) * fw
+ lY * -0.5
),
angles(
1.3962634015954636
- 0.6981317007977318
* sin(sine * 8)
* fw,
-1.5707963267948966
- 0.6981317007977318
* sin(sine * 8)
* rt,
1.5707963267948966
+ 0.2617993877991494 * sin(sine * 8)
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.08726646259971647 * sin(
(sine + 10) * 16
)
+ fw * 0.15,
-0.08726646259971647 * sin(sine * 8) + rt * -0.1,
3.141592653589793
- 0.05235987755982989 * sin((sine + 5) * 8)
- rt * 0.5
)
),
deltaTime
)
--Torso,0,0,0,8,-95,2.5,0,16,-0.2,0.2,0,16,0,5,0,8,0,0,0,8,-180,-5,0.25,8,RightArm,1,0,0,1,0,-30,0,8,0.35,0.1,0,8,90,-30,0,8,0,0,0,8,0,-30,0,8,RightLeg,1,0,0,8,80,40,0,8,-0.8,0.4,0.125,8,90,40,0,8,-0.15,0.4,10,8,-90,15,0,8,LeftLeg,-1,0,0,8,80,-40,0,8,-0.8,-0.4,0.125,8,-90,-40,0,8,-0.15,-0.4,10,8,90,15,0,8,Head,0,0,0,1,-90,2.5,10,16,1,0,0,1,-0,-5,0,8,0,0,0,1,180,-3,5,8,LeftArm,-1,0,0,1,0,30,0,8,0.35,-0.1,0,8,-90,-30,0,8,0,-0.4,0,8,0,-30,0,8
end,
jump = function()
local fw, rt = velbycfrvec()
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf_0,
angles(
-1.4835298641951802 + fw * 0.1,
rt * -0.05,
-3.141592653589793
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
4.014257279586958
- 0.08726646259971647
* sin((sine + 0.5) * 4),
1.7453292519943295
+ 0.08726646259971647
* sin((sine + 0.25) * 4),
-1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1, 0),
angles(
1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.5) * 4),
-1.6580627893946132
+ 0.06981317007977318
* sin((sine + 0.25) * 4),
1.5707963267948966
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
4.014257279586958
- 0.08726646259971647
* sin((sine + 0.5) * 4),
-1.7453292519943295
- 0.08726646259971647
* sin((sine + 0.25) * 4),
1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.3962634015954636,
0,
-3.141592653589793 - rt
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1, 0),
angles(
1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.5) * 4),
1.6580627893946132
- 0.06981317007977318
* sin((sine + 0.25) * 4),
-1.5707963267948966
)
),
deltaTime
)
--Torso,0,0,0,4,-85,0,0,4,0,0,0,4,0,0,0,4,0,0,0,4,-180,0,0,4,RightArm,1,0,0,4,230,-5,0.5,4,0.5,0,0,4,100,5,0.25,4,0,0,0,4,-90,0,0,4,LeftLeg,-1,0,0,4,90,-5,0.5,4,-1,0,0,4,-95,4,0.25,4,0,0,0,4,90,0,0,4,LeftArm,-1,0,0,4,230,-5,0.5,4,0.5,0,0,4,-100,-5,0.25,4,0,0,0,4,90,0,0,4,Head,0,0,0,4,-80,0,0.5,4,1,0,0,4,0,0,0.25,4,0,0,0,4,-180,0,0,4,RightLeg,1,0,0,4,90,-5,0.5,4,-1,0,0,4,95,-4,0.25,4,0,0,0,4,-90,0,0,4
end,
fall = function()
local fw, rt = velbycfrvec()
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf_0,
angles(
-1.6580627893946132 + fw * 0.1,
rt * -0.05,
-3.141592653589793
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
4.014257279586958
- 0.08726646259971647
* sin((sine + 0.5) * 4),
1.7453292519943295
+ 0.08726646259971647
* sin((sine + 0.25) * 4),
-1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1, 0),
angles(
1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.5) * 4),
-1.6580627893946132
+ 0.06981317007977318
* sin((sine + 0.25) * 4),
1.5707963267948966
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
4.014257279586958
- 0.08726646259971647
* sin((sine + 0.5) * 4),
-1.7453292519943295
- 0.08726646259971647
* sin((sine + 0.25) * 4),
1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.7453292519943295,
0,
-3.141592653589793 - rt
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1, 0),
angles(
1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.5) * 4),
1.6580627893946132
- 0.06981317007977318
* sin((sine + 0.25) * 4),
-1.5707963267948966
)
),
deltaTime
)
--Torso,0,0,0,4,-95,0,0,4,0,0,0,4,0,0,0,4,0,0,0,4,-180,0,0,4,RightArm,1,0,0,4,230,-5,0.5,4,0.5,0,0,4,100,5,0.25,4,0,0,0,4,-90,0,0,4,LeftLeg,-1,0,0,4,90,-5,0.5,4,-1,0,0,4,-95,4,0.25,4,0,0,0,4,90,0,0,4,LeftArm,-1,0,0,4,230,-5,0.5,4,0.5,0,0,4,-100,-5,0.25,4,0,0,0,4,90,0,0,4,Head,0,0,0,4,-100,0,0.5,4,1,0,0,4,0,0,0.25,4,0,0,0,4,-180,0,0,4,RightLeg,1,0,0,4,90,-5,0.5,4,-1,0,0,4,95,-4,0.25,4,0,0,0,4,-90,0,0,4
end,
})
addmode('q', {
idle = function()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.75, -0.2),
angles(
2.705260340591211
- 0.08726646259971647
* sin((sine + 0.1) * 2),
-2.792526803190927,
-0.6981317007977318
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.75, -0.2),
angles(
2.705260340591211
- 0.08726646259971647
* sin((sine + 0.1) * 2),
2.792526803190927,
0.6981317007977318
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.9198621771937625
- 0.10471975511965978
* sin((sine + 0.3) * 2),
0,
3.141592653589793
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, -2.45 - 0.05 * sin(sine * 2), 0),
angles(
0.03490658503988659 * sin(sine * 2),
0,
3.141592653589793
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1, 0),
angles(
1.3962634015954636
- 0.03490658503988659 * sin(sine * 2),
1.3089969389957472,
-0.9599310885968813
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1, 0),
angles(
1.5707963267948966
- 0.03490658503988659 * sin(sine * 2),
-1.3089969389957472,
1.5707963267948966
)
),
deltaTime
)
--LeftArm,-1,0,0,2,155,-5,0.1,2,0.75,0,0,2,-160,0,0,2,-0.2,0,0,2,-40,0,0,2,RightArm,1,0,0,2,155,-5,0.1,2,0.75,0,0,2,160,0,0,2,-0.2,0,0,2,40,0,0,2,Head,0,0,0,2,-110,-6,0.3,2,1,0,0,2,-0,0,0,2,0,0,0,2,180,0,0,2,Torso,0,0,0,2,0,2,0,2,-2.45,-0.05,0,2,-0,0,0,2,0,0,0,2,180,0,0,2,RightLeg,1,0,0,2,80,-2,0,2,-1,0,0,2,75,0,0,2,0,0,0,2,-55,0,0,2,LeftLeg,-1,0,0,2,90,-2,0,2,-1,0,0,2,-75,0,0,2,0,0,0,2,90,0,0,2
end,
})
addmode('e', {
idle = function()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
-0.9,
0.4 + 0.1 * sin(sine * 2),
0.3 - 0.15 * sin(sine * 2)
),
angles(
-1.0471975511965976
- 0.12217304763960307 * sin(sine * 2),
-1.3962634015954636,
-0.6981317007977318
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, -1.85 - 0.1 * sin((sine + 0.2) * 2), 0),
angles(
-1.3962634015954636
+ 0.03490658503988659 * sin(sine * 2),
-0.08726646259971647,
3.141592653589793
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
1,
0.4 + 0.1 * sin(sine * 2),
0.2 - 0.15 * sin(sine * 2)
),
angles(
0.6108652381980153
- 0.12217304763960307 * sin(sine * 2),
1.2217304763960306,
-0.7853981633974483
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.6580627893946132
- 0.03490658503988659
* sin((sine + 0.6) * 2),
0.10471975511965978
+ 0.06981317007977318 * sin(sine * 0.66),
3.141592653589793
+ 0.3490658503988659 * sin(sine * 0.66)
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
0.2 + 0.15 * sin((sine + 0.2) * 2),
-0.7 + 0.1 * sin(sine * 2)
),
angles(
1.4835298641951802
+ 0.03490658503988659 * sin(sine * 2),
1.4835298641951802,
-1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -0.75 + 0.1 * sin((sine + 0.2) * 2), -0.5),
angles(
1.3962634015954636
- 0.03490658503988659 * sin(sine * 2),
-1.6580627893946132,
0
)
),
deltaTime
)
--LeftArm,-0.9,0,0,2,-60,-7,0,2,0.4,0.1,0,2,-80,0,0,2,0.3,-0.15,0,2,-40,0,0,2,Torso,0,0,0,2,-80,2,0,2,-1.85,-0.1,0.2,2,-5,0,0,2,0,0,0,2,180,0,0,2,RightArm,1,0,0,2,35,-7,0,2,0.4,0.1,0,2,70,0,0,2,0.2,-0.15,0,2,-45,0,0,2,Head,0,0,0,2,-95,-2,0.6,2,1,0,0,2,6,4,0,0.66,0,0,0,2,180,20,0,0.66,RightLeg,1,0,0,2,85,2,0,2,0.2,0.15,0.2,2,85,0,0,2,-0.7,0.1,0,2,-90,0,0,2,LeftLeg,-1,0,0,2,80,-2,0,2,-0.75,0.1,0.2,2,-95,0,0,2,-0.5,0,0,2,0,0,0,2
end,
})
addmode('r', {
idle = function()
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -0.9 - 0.2 * sin(sine * 2), 0),
angles(
1.5707963267948966,
1.6580627893946132
- 0.17453292519943295 * sin(sine + 0.8),
-1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
0.3 * sin(sine + 0.8),
-0.1 + 0.2 * sin(sine * 2),
0
),
angles(-1.5707963267948966, 0, -3.141592653589793)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.08726646259971647
* sin((sine - 0.5) * 2),
0.08726646259971647 * sin(sine - 1),
-3.141592653589793
+ 0.2617993877991494 * sin(sine * 5)
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
-1 + 0.1 * sin(sine * 7),
0.2 - 0.1 * sin(sine + 0.8),
-0.25
),
angles(
1.5707963267948966
+ 0.5235987755982988 * sin(sine * 7),
-0.6981317007977318,
0.3490658503988659 * sin(sine * 7)
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -0.9 - 0.2 * sin(sine * 2), 0),
angles(
1.5707963267948966,
-1.6580627893946132
- 0.17453292519943295 * sin(sine + 0.8),
1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
1 + 0.1 * sin(sine * 7),
0.2 + 0.1 * sin(sine + 0.8),
-0.25
),
angles(
1.5707963267948966
- 0.5235987755982988 * sin(sine * 7),
0.6981317007977318,
0.3490658503988659 * sin(sine * 7)
)
),
deltaTime
)
--RightLeg,1,0,0,1,90,0,0,1,-0.9,-0.2,0,2,95,-10,0.8,1,0,0,0,1,-90,0,0,1,Torso,0,0.3,0.8,1,-90,0,0,1,-0.1,0.2,0,2,0,0,0,1,0,0,0,1,-180,0,0,1,Head,0,0,0,1,-90,5,-0.5,2,1,0,0,1,0,5,-1,1,0,0,0,1,-180,15,0,5,Fedora_Handle,8.657480066176504e-09,0,0,1,-6,0,0,1,-0.15052366256713867,0,0,1,0,0,0,1,-0.010221302509307861,0,0,1,0,0,0,1,LeftArm,-1,0.1,0,7,90,30,0,7,0.2,-0.1,0.8,1,-40,0,0,1,-0.25,0,0,1,0,20,0,7,LeftLeg,-1,0,0,1,90,0,0,1,-0.9,-0.2,0,2,-95,-10,0.8,1,0,0,0,1,90,0,0,1,RightArm,1,0.1,0,7,90,-30,0,7,0.2,0.1,0.8,1,40,0,0,1,-0.25,0,0,1,-0,20,0,7
end,
})
addmode('t', {
idle = function()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
1.5707963267948966,
-1.6580627893946132
+ 0.08726646259971647
* sin((sine - 0.3) * 4),
1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1 + 0.15 * sin((sine - 0.4) * 4), 1.42, 0),
angles(
1.5707963267948966,
1.4835298641951802
- 0.3490658503988659
* sin((sine - 0.4) * 4),
1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.4835298641951802,
0.04363323129985824
- 0.08726646259971647
* sin((sine + 0.1) * 4),
-3.141592653589793
+ 0.04363323129985824 * sin(sine * 4)
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0.1 * sin(sine * 4), 0, 0),
angles(
-1.5707963267948966,
-0.08726646259971647
+ 0.08726646259971647 * sin(sine * 4),
-3.141592653589793
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1.1 + 0.1 * sin(sine * 4), 0),
angles(
1.5707963267948966,
1.5707963267948966
+ 0.08726646259971647 * sin(sine * 4),
-1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1 - 0.02 * sin(sine * 4),
-0.925 - 0.07 * sin(sine * 4),
0
),
angles(
1.5707963267948966,
-1.7453292519943295
+ 0.08726646259971647 * sin(sine * 4),
1.5707963267948966
)
),
deltaTime
)
--LeftArm,-1,0,0,4,90,0,0,4,0.5,0,0,4,-95,5,-0.3,4,0,0,0,4,90,0,0,4,RightArm,1,0.15,-0.4,4,90,0,0,4,1.42,0,0,4,85,-20,-0.4,4,0,0,0,4,90,0,0,4,Head,0,0,0,4,-85,0,0,4,1,0,0,4,2.5,-5,0.1,4,0,0,0,4,-180,2.5,0,4,Torso,0,0.1,0,4,-90,0,0,4,0,0,0,4,-5,5,0,4,0,0,0,4,-180,0,0,4,RightLeg,1,0,0,4,90,0,0,4,-1.1,0.1,0,4,90,5,0,4,0,0,0,4,-90,0,0,4,LeftLeg,-1,-0.02,0,4,90,0,0,4,-0.925,-0.07,0,4,-100,5,0,4,0,0,0,4,90,0,0,4
end,
})
addmode('y', {
idle = function()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1.5, 0.5, 0),
angles(
-1.7453292519943295,
0.17453292519943295
- 0.04363323129985824 * sin(sine * 2),
-1.4835298641951802
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -0.9000000953674316 - 0.1 * sin(sine * 2), 0),
angles(
-1.3962634015954636,
1.3962634015954636,
1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1.0000001192092896 - 0.1 * sin(sine * 2), 0),
angles(
-1.5707963267948966,
-1.3962634015954636,
-1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-2.0943951023931953
+ 0.08726646259971647
* sin((sine - 1) * 2),
-0.08726646259971647,
2.792526803190927
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 1.2000000476837158, 0),
angles(
2.6179938779914944
+ 0.08726646259971647
* sin((sine - 1) * 2),
0.6981317007977318,
-1.3962634015954636
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, 0.1 * sin(sine * 2), 0),
angles(
-1.6580627893946132,
0.08726646259971647,
3.0543261909900767
)
),
deltaTime
)
--LeftArm,-1.5,0,0,2,-100,0,0,2,0.5,0,0,2,10,-2.5,0,2,0,0,0,2,-85,0,0,2,RightLeg,1,0,0,2,-80,0,0,2,-0.9000000953674316,-0.1,0,2,80,0,0,2,0,0,0,2,90,0,0,2,LeftLeg,-1,0,0,2,-90,0,0,2,-1.0000001192092896,-0.1,0,2,-80,0,0,2,0,0,0,2,-90,0,0,2,Fedora_Handle,8.657480066176504e-09,0,0,2,-6,0,0,2,-0.15052366256713867,0,0,2,0,0,0,2,-0.010221302509307861,0,0,2,0,0,0,2,Head,0,0,0,2,-120,5,-1,2,1,0,0,2,-5,0,0,2,0,0,0,2,160,0,0,2,RightArm,1,0,0,2,150,5,-1,2,1.2000000476837158,0,0,2,40,0,0,2,0,0,0,2,-80,0,0,2,Torso,0,0,0,2,-95,0,0,2,0,0.1,0,2,5,0,0,2,0,0,0,2,175,0,0,2
end,
})
addmode('u', {
idle = function()
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, 0.75 + 0.25 * sin(sine * 2), 0),
angles(-1.5707963267948966, 0, 3.141592653589793)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1.5 - 0.1 * sin((sine + 0.2) * 2), 0),
angles(
-1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.4) * 2),
0,
3.141592653589793
+ 0.3490658503988659 * sin(sine * 0.66)
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-0.5 - 1 * sin((sine + 0.2) * 2.2),
-0.75 - 0.25 * sin(sine * 2),
1 * sin((sine + 0.95) * 2.2)
),
angles(0, -1.5707963267948966, 0)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
0.5 + 1 * sin((sine + 0.2) * 2.2),
-0.75 - 0.25 * sin(sine * 2),
-1 * sin((sine + 0.95) * 2.2)
),
angles(0, 1.5707963267948966, 0)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
-0.5 - 1.85 * sin(sine * 2),
0.8 - 0.5 * sin(sine * 2),
-1.85 * sin((sine + 0.75) * 2)
),
angles(0, 1.5707963267948966, 0)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
0.5 + 1.85 * sin(sine * 2),
0.8 - 0.5 * sin(sine * 2),
1.85 * sin((sine + 0.75) * 2)
),
angles(0, -1.5707963267948966, 0)
),
deltaTime
)
--Torso,0,0,0,2,-90,0,0,2,0.75,0.25,0,2,-0,0,0,2,0,0,0,2,180,0,0,2,Fedora_Handle,8.657480066176504e-09,0,0,2,-6,0,0,2,-0.15052366256713867,0,0,2,0,0,0,2,-0.010221302509307861,0,0,2,0,0,0,2,Head,0,0,0,2,-90,-5,0.4,2,1.5,-0.1,0.2,2,-0,0,0,2,0,0,0,2,180,20,0,0.66,LeftLeg,-0.5,-1,0.2,2.2,-0,0,0,2,-0.75,-0.25,0,2,-90,0,0,2,0,1,0.95,2.2,0,0,0,2,RightLeg,0.5,1,0.2,2.2,0,0,0,2,-0.75,-0.25,0,2,90,0,0,2,0,-1,0.95,2.2,0,0,0,2,RightArm,-0.5,-1.85,0,2,0,0,0,2,0.8,-0.5,0,2,90,0,0,2,0,-1.85,0.75,2,0,0,0,2,LeftArm,0.5,1.85,0,2,-0,0,0,2,0.8,-0.5,0,2,-90,0,0,2,0,1.85,0.75,2,0,0,0,2
end,
})
addmode('i', {
idle = function()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
-0.5,
0.5 + 0.1 * sin((sine - 0.4444444444444444) * 9),
0
),
angles(
2.9670597283903604
+ 0.17453292519943295
* sin(
(sine - 0.17777777777777778) * 9
),
-0.5235987755982988,
1.5707963267948966
+ 0.17453292519943295 * sin(sine * 4.5)
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-0.5
+ 0.1
* sin(
(sine + 0.26666666666666666) * 4.5
),
-0.5
),
angles(
1.7453292519943295
- 1.0471975511965976 * sin(sine * 4.5),
-1.5707963267948966
+ 0.03490658503988659 * sin(sine * 4.5),
1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
0,
-0.5
+ 0.5
* sin(
(sine + 0.17777777777777778) * 9
),
0
),
angles(
-1.3962634015954636
- 0.03490658503988659
* sin(
(sine + 0.17777777777777778) * 9
),
-0.05235987755982989 * sin(sine * 4.5),
3.141592653589793
+ 0.03490658503988659 * sin(sine * 4.5)
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1 + 0.2 * sin(sine * 9), 0),
angles(
-1.5707963267948966
+ 0.08726646259971647 * sin(sine * 9),
0.08726646259971647 * sin(sine * 4.5),
3.141592653589793
- 0.06981317007977318 * sin(sine * 4.5)
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
0.5,
0.5 + 0.1 * sin((sine - 0.4444444444444444) * 9),
0
),
angles(
2.9670597283903604
+ 0.17453292519943295
* sin(
(sine - 0.17777777777777778) * 9
),
0.5235987755982988,
-1.5707963267948966
+ 0.17453292519943295 * sin(sine * 4.5)
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-0.5
+ 0.1
* sin(
(sine - 0.26666666666666666) * 4.5
),
-0.5
),
angles(
1.7453292519943295
+ 1.0471975511965976 * sin(sine * 4.5),
1.5707963267948966
+ 0.03490658503988659 * sin(sine * 4.5),
-1.5707963267948966
)
),
deltaTime
)
--LeftArm,-0.5,0,0,4.5,170,10,-0.17777777777777778,9,0.5,0.1,-0.4444444444444444,9,-30,0,0,4.5,0,0,0,4.5,90,10,0,4.5,LeftLeg,-1,0,0,4.5,100,-60,0,4.5,-0.5,0.1,0.26666666666666666,4.5,-90,2,0,4.5,-0.5,0,0,4.5,90,0,0,4.5,Torso,0,0,0,4.5,-80,-2,0.17777777777777778,9,-0.5,0.5,0.17777777777777778,9,-0,-3,0,4.5,0,0,0,4.5,180,2,0,4.5,Head,0,0,0,4.5,-90,5,0,9,1,0.2,0,9,-0,5,0,4.5,0,0,0,4.5,180,-4,0,4.5,RightArm,0.5,0,0,4.5,170,10,-0.17777777777777778,9,0.5,0.1,-0.4444444444444444,9,30,0,0,4.5,0,0,0,4.5,-90,10,0,4.5,RightLeg,1,0,0,4.5,100,60,0,4.5,-0.5,0.1,-0.26666666666666666,4.5,90,2,0,4.5,-0.5,0,0,4.5,-90,0,0,4.5
end,
})
addmode('o', {
idle = function()
local rY, lY = raycastlegs()
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1 + lY, lY * -0.5),
angles(
-1.8325957145940461
- 0.08726646259971647 * sin(sine * 2),
-1.4835298641951802,
-1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, 0, 0.09 * sin(sine * 2)),
angles(
-1.3962634015954636
+ 0.08726646259971647 * sin(sine * 2),
-0.08726646259971647,
3.141592653589793
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
2.9670597283903604
+ 0.08726646259971647 * sin(sine * 1),
-1.5707963267948966
+ 0.08726646259971647
* sin((sine + 0.6) * 1),
1.5707963267948966
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1.1 + rY, rY * -0.5),
angles(
-1.7453292519943295
- 0.08726646259971647 * sin(sine * 2),
1.5707963267948966,
1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.2217304763960306
- 0.08726646259971647
* sin((sine + 0.3) * 2),
-0.2617993877991494
- 0.08726646259971647 * sin(sine * 2),
3.141592653589793
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
2.8797932657906435
+ 0.08726646259971647 * sin(sine * 1),
1.5707963267948966
- 0.08726646259971647
* sin((sine + 0.6) * 1),
-1.5707963267948966
)
),
deltaTime
)
--LeftLeg,-1,0,0,2,-105,-5,0,2,-1,0,0,2,-85,0,0,2,0,0,0,2,-90,0,0.75,2,Torso,0,0,0,2,-80,5,0,2,0,0,0,2,-5,0,0,2,0,0.09,0,2,180,0,0,2,LeftArm,-1,0,0,2,170,5,0,1,0.5,0,0,2,-90,5,0.6,1,0,0,0,2,90,0,0,2,RightLeg,1,0,0,2,-100,-5,0,2,-1.1,0,0,2,90,0,0,2,0,0,0,2,90,0,0.75,2,Head,0,0,0,2,-70,-5,0.3,2,1,0,0,2,-15,-5,0,2,0,0,0,2,180,0,0,2,RightArm,1,0,0,2,165,5,0,1,0.5,0,0,2,90,-5,0.6,1,0,0,0,2,-90,0,0,2
end,
walk = function()
local fw, rt = velbycfrvec()
local rY, lY = raycastlegs()
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.04363323129985824 * sin(sine * 16),
0,
3.141592653589793
+ 0.08726646259971647 * sin(sine * 8)
- rt
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-1 - 0.3 * sin((sine + 0.15) * 8) + rY,
rY * -0.5
),
angles(
-1.5707963267948966
- 0.6981317007977318
* sin(sine * 8)
* fw,
1.5707963267948966
+ 0.6981317007977318
* sin(sine * 8)
* rt,
1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
0.08726646259971647 * sin((sine - 0.05) * 16),
1.5707963267948966
+ 0.08726646259971647 * sin(sine * 8)
- rt / 3,
1.5707963267948966
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
0.08726646259971647 * sin((sine - 0.05) * 16),
-1.5707963267948966
+ 0.08726646259971647 * sin(sine * 8)
- rt / 3,
-1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, 0.1 * sin((sine + 0.1) * 16), 0),
angles(
-1.5707963267948966,
0,
3.141592653589793
- 0.08726646259971647 * sin(sine * 8)
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-1 + 0.3 * sin((sine + 0.15) * 8) + lY,
lY * -0.5
),
angles(
1.5707963267948966
+ 0.6981317007977318
* sin(sine * 8)
* fw,
-1.5707963267948966
+ 0.6981317007977318
* sin(sine * 8)
* rt,
1.5707963267948966
)
),
deltaTime
)
--Head,0,0,0,8,-90,2.5,0,16,1,0,0,8,-0,0,0,8,0,0,0,8,180,5,0,8,RightLeg,1,0,0,8,-90,-40,0,8,-1,-0.3,0.15,8,90,40,0,8,0,0,0,8,90,0,0,8,RightArm,1,0,0,8,0,5,-0.05,16,0.5,0,0,8,90,5,0,8,0,0,0,8,90,0,0,8,LeftArm,-1,0,0,8,0,5,-0.05,16,0.5,0,0,8,-90,5,0,8,0,0,0,8,-90,0,0,8,Torso,0,0,0,8,-90,0,0,8,0,0.1,0.1,16,-0,0,0,8,0,0,0,8,180,-5,0,8,LeftLeg,-1,0,0,8,90,40,0,8,-1,0.3,0.15,8,-90,40,0,8,0,0,0,8,90,0,0,8
end,
})
addmode('p', {
idle = function()
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1.5, 0.5, 0),
angles(
1.5707963267948966,
3.141592653589793,
-1.5707963267948966
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(cf(1, -1, 0), angles(0, 1.5707963267948966, 0)),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1.5, 0.5, 0),
angles(
1.5707963267948966,
3.141592653589793,
1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(cf(-1, -1, 0), angles(0, -1.5707963267948966, 0)),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(-1.5707963267948966, 0, -3.141592653589793)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf_0,
angles(-1.5707963267948966, 0, -3.141592653589793)
),
deltaTime
)
--RightArm,1.5,0,0,1,90,0,0,1,0.5,0,0,1,180,0,0,1,0,0,0,1,-90,0,0,1,RightLeg,1,0,0,1,0,0,0,1,-1,0,0,1,90,0,0,1,0,0,0,1,0,0,0,1,Fedora_Handle,8.657480066176504e-09,0,0,1,-6,0,0,1,-0.15052366256713867,0,0,1,0,0,0,1,-0.010221302509307861,0,0,1,0,0,0,1,LeftArm,-1.5,0,0,1,90,0,0,1,0.5,0,0,1,180,0,0,1,0,0,0,1,90,0,0,1,LeftLeg,-1,0,0,1,-0,0,0,1,-1,0,0,1,-90,0,0,1,0,0,0,1,0,0,0,1,Head,0,0,0,1,-90,0,0,1,1,0,0,1,0,0,0,1,0,0,0,1,-180,0,0,1,Torso,0,0,0,1,-90,0,0,1,0,0,0,1,0,0,0,1,0,0,0,1,-180,0,0,1
end,
})
addmode('f', {
idle = function()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
-3.0543261909900767
- 0.17453292519943295
* sin((sine + 1.5) * 1),
-1.5707963267948966
+ 0.08726646259971647
* sin((sine + 0.6) * 1),
-1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
3.141592653589793
- 0.08726646259971647 * sin(sine * 1),
0.3490658503988659
+ 0.08726646259971647
* sin((sine + 0.3) * 1),
-1.9198621771937625
+ 0.08726646259971647
* sin((sine + 1) * 1)
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.3089969389957472
- 0.2617993877991494
* sin((sine + 1.2) * 1),
0.08726646259971647 * sin((sine + 0.2) * 0.5),
-2.9670597283903604
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
0,
5 - 0.5 * sin((sine - 0.2) * 1),
0.2 * sin((sine - 1.2) * 1)
),
angles(
-0.08726646259971647
+ 0.17453292519943295
* sin((sine + 1.2) * 1),
0.08726646259971647 * sin(sine * 0.5),
3.141592653589793
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1, 0),
angles(
1.3962634015954636
+ 0.12217304763960307
* sin((sine + 1.5) * 1),
-1.2217304763960306
+ 0.08726646259971647
* sin((sine + 0.2) * 0.5),
1.5707963267948966
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1, 0),
angles(
1.9198621771937625
+ 0.12217304763960307
* sin((sine + 1.5) * 1),
1.2217304763960306
+ 0.08726646259971647
* sin((sine + 0.2) * 0.5),
-1.5707963267948966
)
),
deltaTime
)
--LeftArm,-1,0,0,1,-175,-10,1.5,1,0.5,0,0,1,-90,5,0.6,1,0,0,0,1,-90,0,0,1,RightArm,1,0,0,1,180,-5,0,1,0.5,0,0,1,20,5,0.3,1,0,0,0,1,-110,5,1,1,Head,0,0,0,1,-75,-15,1.2,1,1,0,0,1,-0,5,0.2,0.5,0,0,0,1,-170,0,0,1,Torso,0,0,0,1,-5,10,1.2,1,5,-0.5,-0.2,1,-0,5,0,0.5,0,0.2,-1.2,1,180,0,0,1,LeftLeg,-1,0,0,1,80,7,1.5,1,-1,0,0,1,-70,5,0.2,0.5,0,0,0,1,90,0,0,1,RightLeg,1,0,0,1,110,7,1.5,1,-1,0,0,1,70,5,0.2,0.5,0,0,0,1,-90,0,0,1
end,
walk = function()
local fw, rt = velbycfrvec()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
-3.0543261909900767
- 0.17453292519943295 * sin(
(sine + 1.5) * 1
)
- fw * 0.1,
-1.5707963267948966
+ 0.08726646259971647 * sin(
(sine + 0.6) * 1
)
+ rt * 0.2,
-1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
3.141592653589793
- 0.08726646259971647 * sin(sine * 1),
0.3490658503988659
+ 0.08726646259971647
* sin((sine + 0.3) * 1),
-1.9198621771937625
+ 0.08726646259971647
* sin((sine + 1) * 1)
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.3089969389957472
- 0.2617993877991494 * sin((sine + 1.2) * 1)
+ fw * 0.1,
0.08726646259971647 * sin((sine + 0.2) * 0.5)
- rt * 0.2,
-2.9670597283903604
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
0,
5 - 0.5 * sin((sine - 0.2) * 1),
0.2 * sin((sine - 1.2) * 1)
),
angles(
-0.08726646259971647
+ 0.17453292519943295 * sin(
(sine + 1.2) * 1
)
- fw * 0.2,
0.08726646259971647 * sin(sine * 0.5),
3.141592653589793 - rt * 0.2
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1, 0),
angles(
1.3962634015954636
+ 0.12217304763960307 * sin(
(sine + 1.5) * 1
)
- fw * 0.2,
-1.2217304763960306
+ 0.08726646259971647
* sin((sine + 0.2) * 0.5),
1.5707963267948966
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1, 0),
angles(
1.9198621771937625
+ 0.12217304763960307 * sin(
(sine + 1.5) * 1
)
- fw * 0.2,
1.2217304763960306
+ 0.08726646259971647
* sin((sine + 0.2) * 0.5),
-1.5707963267948966
)
),
deltaTime
)
--LeftArm,-1,0,0,1,-175,-10,1.5,1,0.5,0,0,1,-90,5,0.6,1,0,0,0,1,-90,0,0,1,RightArm,1,0,0,1,180,-5,0,1,0.5,0,0,1,20,5,0.3,1,0,0,0,1,-110,5,1,1,Head,0,0,0,1,-75,-15,1.2,1,1,0,0,1,-0,5,0.2,0.5,0,0,0,1,-170,0,0,1,Torso,0,0,0,1,-5,10,1.2,1,5,-0.5,-0.2,1,-0,5,0,0.5,0,0.2,-1.2,1,180,0,0,1,LeftLeg,-1,0,0,1,80,7,1.5,1,-1,0,0,1,-70,5,0.2,0.5,0,0,0,1,90,0,0,1,RightLeg,1,0,0,1,110,7,1.5,1,-1,0,0,1,70,5,0.2,0.5,0,0,0,1,-90,0,0,1
end,
})
addmode('g', {
idle = function()
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
-0.9 + 0.4 * sin(sine * 8),
0.5,
0.5 * sin((sine + 0.25) * 4)
),
angles(
1.5707963267948966,
-1.5707963267948966
+ 1.0471975511965976 * sin(sine * 8),
1.5707963267948966
+ 0.6981317007977318
* sin((sine + 0.25) * 4)
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0.3 * sin((sine + 0.4) * 8), 0, 0),
angles(
-1.5707963267948966,
0.3490658503988659 * sin(sine * 8),
-3.141592653589793
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.061086523819801536
* sin((sine + 0.125) * 16),
-0.3839724354387525 * sin(sine * 8),
-3.141592653589793
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1 + 0.4 * sin((sine - 0.01) * 8), 0),
angles(
1.5707963267948966,
1.7453292519943295
+ 0.6981317007977318 * sin(sine * 8),
-1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1 - 0.4 * sin((sine - 0.01) * 8), 0),
angles(
1.5707963267948966,
-1.7453292519943295
+ 0.6981317007977318 * sin(sine * 8),
1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
0.9 + 0.4 * sin(sine * 8),
0.5,
-0.5 * sin((sine - 0.35) * 4)
),
angles(
1.5707963267948966
+ 0.6981317007977318 * sin(sine * 4),
1.5707963267948966
+ 1.0471975511965976 * sin(sine * 8),
-1.5707963267948966
+ 0.17453292519943295
* sin((sine - 0.35) * 4)
)
),
deltaTime
)
--LeftArm,-0.9,0.4,0,8,90,0,0.25,4,0.5,0,0,8,-90,60,0,8,0,0.5,0.25,4,90,40,0.25,4,Torso,0,0.3,0.4,8,-90,0,0,8,0,0,0,4,0,20,0,8,0,0,0,8,-180,0,0,8,Head,0,0,0,8,-90,3.5,0.125,16,1,0,0,8,0,-22,0,8,0,0,0,8,-180,0,0,1.1,RightLeg,1,0,0,8,90,0,0,8,-1,0.4,-0.01,8,100,40,0,8,0,0,0,8,-90,0,0,8,LeftLeg,-1,0,0,8,90,0,0,8,-1,-0.4,-0.01,8,-100,40,0,8,0,0,0,8,90,0,0,8,RightArm,0.9,0.4,0,8,90,40,0,4,0.5,0,0,8,90,60,0,8,0,-0.5,-0.35,4,-90,10,-0.35,4
end,
})
addmode('h', {
idle = function()
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966,
-0.4363323129985824 * sin(sine * 8),
-3.141592653589793
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1 + 0.3 * sin(sine * 8), 0),
angles(
1.5707963267948966,
1.5707963267948966
+ 0.5235987755982988 * sin(sine * 8),
-1.5707963267948966
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-0.5, 1, 0),
angles(
-0.5235987755982988,
-1.5707963267948966
- 0.5235987755982988 * sin(sine * 8),
3.141592653589793
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(0.5, 1, 0),
angles(
-0.5235987755982988,
1.5707963267948966
- 0.5235987755982988 * sin(sine * 8),
3.141592653589793
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
-0.1 * sin(sine * 8),
0.2 * sin((sine + 0.1) * 16),
0
),
angles(
-1.5707963267948966,
0.2617993877991494 * sin(sine * 8),
-3.141592653589793
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1 - 0.3 * sin(sine * 8), 0),
angles(
1.5707963267948966,
-1.5707963267948966
+ 0.5235987755982988 * sin(sine * 8),
1.5707963267948966
)
),
deltaTime
)
--Head,0,0,0,8,-90,0,0,8,1,0,0,8,0,-25,0,8,0,0,0,8,-180,0,0,8,RightLeg,1,0,0,8,90,0,0,8,-1,0.3,0,8,90,30,0,8,0,0,0,8,-90,0,0,8,LeftArm,-0.5,0,0,8,-30,0,0,8,1,0,0,8,-90,-30,0,8,0,0,0,8,180,0,0,8,RightArm,0.5,0,0,8,-30,0,0,8,1,0,0,16,90,-30,0,8,0,0,0,8,180,0,0,8,Torso,0,-0.1,0,8,-90,0,0,8,0,0.2,0.1,16,0,15,0,8,0,0,0,8,-180,0,0,8,LeftLeg,-1,0,0,8,90,0,0,8,-1,-0.3,0,8,-90,30,0,8,0,0,0,8,90,0,0,8,Fedora_Handle,8.657480066176504e-09,0,0,8,-6,0,0,8,-0.15052366256713867,0,0,8,0,0,0,8,-0.010221302509307861,0,0,8,0,0,0,8
end,
})
addmode('j', {
idle = function()
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-0.8, -1, -0.1),
angles(0.17453292519943295, -0.6981317007977318, 0)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1.2, 0.5, 0),
angles(
-0.3490658503988659
+ 0.08726646259971647
* sin((sine + 0.1) * 4),
0,
0.6981317007977318
+ 0.08726646259971647
* sin((sine + 0.1) * 4)
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1.1, -1, 0),
angles(
1.5707963267948966,
1.7453292519943295,
-1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.08726646259971647
* sin((sine + 0.1) * 4),
0,
2.792526803190927
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
0,
-1.7 + 0.5 * sin(sine * 4),
0.15 * sin(sine * 4)
),
angles(
3.3161255787892263
+ 0.17453292519943295 * sin(sine * 4),
0,
3.6651914291880923
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
0.8 + 0.4 * sin(sine * 4),
0.6 + 0.1 * sin(sine * 4),
0.4 - 0.25 * sin(sine * 4)
),
angles(
2.9670597283903604,
2.2689280275926285
- 0.17453292519943295 * sin(sine * 4),
-1.4835298641951802
- 0.17453292519943295 * sin(sine * 4)
)
),
deltaTime
)
--GalaxyBeautifulHair_Handle,-0.15000000596046448,0,0,1,0,0,0,1,0.10000000149011612,0,0,1,0,0,0,1,0,0,0,1,0,0,0,1,LeftLeg,-0.8,0,0,4,10,0,0,4,-1,0,0,4,-40,0,0,4,-0.1,0,0,4,0,0,0,4,LeftArm,-1.2,0,0,4,-20,5,0.1,4,0.5,0,0,4,0,0,0,4,0,0,0,4,40,5,0.1,4,Fedora_Handle,8.657480066176504e-09,0,0,1,-6,0,0,1,-0.15052366256713867,0,0,1,0,0,0,1,-0.010221302509307861,0,0,1,0,0,0,1,ValkyrieHelm_Handle,8.658389560878277e-09,0,0,1,-15,0,0,1,-0.2433757781982422,0,0,1,0,0,0,1,-0.2657628059387207,0,0,1,0,0,0,1,RightLeg,1.1,0,0,4,90,0,0,4,-1,0,0,4,100,0,0,4,0,0,0,4,-90,0,0,4,BlackIronAntlers_Handle,8.658389560878277e-09,0,0,1,0,0,0,1,-0.6500000953674316,0,0,1,0,0,0,1,0.19972775876522064,0,0,1,0,0,0,1,DevAwardsAdurite_Handle,0,0,0,1,0,0,0,1,-0.25,0,0,1,0,0,0,1,0,0,0,1,0,0,0,1,SilverthornAntlers_Handle,8.658389560878277e-09,0,0,1,0,0,0,1,-0.6500000953674316,0,0,1,0,0,0,1,0.19972775876522064,0,0,1,0,0,0,1,Head,0,0,0,4,-90,5,0.1,4,1,0,0,4,-0,0,0,4,0,0,0,4,160,0,0,4,Torso,0,0,0,4,190,10,0,4,-1.70,0.5,0,4,-0,0,0,4,0,0.15,0,4,210,0,0,4,RightArm,0.8,0.4,0,4,170,0,0,4,0.6,0.1,0,4,130,-10,0,4,0.4,-0.25,0,4,-85,-10,0,4
end,
})
addmode('k', {
idle = function()
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.6580627893946132
- 0.08726646259971647
* sin(
(sine + 0.3333333333333333) * 12
),
-0.08726646259971647 * sin((sine + 0.2) * 6),
3.141592653589793
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-0.5
- 0.5
* sin(
(sine + 0.39999999999999997) * 12
),
-0.5
),
angles(
1.7453292519943295
- 1.0471975511965976 * sin(sine * 6),
-1.5707963267948966
+ 0.1308996938995747 * sin(sine * 6),
1.5707963267948966
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-0.5
- 0.5
* sin(
(sine + 0.39999999999999997) * 12
),
-0.5
),
angles(
1.7453292519943295
+ 1.0471975511965976 * sin(sine * 6),
1.5707963267948966
+ 0.1308996938995747 * sin(sine * 6),
-1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(
0,
-0.5
+ 0.3
* sin(
(sine + 0.16666666666666666) * 12
),
0
),
angles(
-1.3962634015954636
+ 0.08726646259971647
* sin(
(sine + 0.3333333333333333) * 12
),
0.08726646259971647
* sin((sine + 0.06666666666666667) * 6),
3.141592653589793
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(
-0.8 - 0.1 * sin(sine * 6),
0.5 + 0.1 * sin(sine * 6),
-0.2
),
angles(
3.141592653589793
- 0.17453292519943295
* sin(
(sine + 0.39999999999999997) * 12
),
-0.17453292519943295,
1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(
0.8 - 0.1 * sin(sine * 6),
0.5 - 0.1 * sin(sine * 6),
-0.2
),
angles(
3.141592653589793
- 0.17453292519943295
* sin(
(sine + 0.39999999999999997) * 12
),
0.17453292519943295,
-1.5707963267948966
)
),
deltaTime
)
--GalaxyBeautifulHair_Handle,-0.15000000596046448,0,0,1.5,0,0,0,1.5,0.10000000149011612,0,0,1.5,0,0,0,1.5,0,0,0,1.5,0,0,0,1.5,Head,0,0,0,6,-95,-5,0.3333333333333333,12,1,0,0,6,-0,-5,0.2,6,0,0,0,6,180,0,0,6,ValkyrieHelm_Handle,8.658389560878277e-09,0,0,1.5,-15,0,0,1.5,-0.2433757781982422,0,0,1.5,0,0,0,1.5,-0.2657628059387207,0,0,1.5,0,0,0,1.5,SilverthornAntlers_Handle,8.658389560878277e-09,0,0,1.5,0,0,0,1.5,-0.6500000953674316,0,0,1.5,0,0,0,1.5,0.19972775876522064,0,0,1.5,0,0,0,1.5,BlackIronAntlers_Handle,8.658389560878277e-09,0,0,1.5,0,0,0,1.5,-0.6500000953674316,0,0,1.5,0,0,0,1.5,0.19972775876522064,0,0,1.5,0,0,0,1.5,Fedora_Handle,8.657480066176504e-09,0,0,1.5,-6,0,0,1.5,-0.15052366256713867,0,0,1.5,0,0,0,1.5,-0.010221302509307861,0,0,1.5,0,0,0,1.5,LeftLeg,-1,0,0,6,100,-60,0,6,-0.5,-0.5,0.39999999999999997,12,-90,7.5,0,6,-0.5,0,0,6,90,0,0,6,EyelessSmileHead_Handle,-0.00043487548828125,0,0,1.5,180,0,0,1.5,0.6000361442565918,0,0,1.5,0,0,0,1.5,0.0003204345703125,0,0,1.5,180,0,0,1.5,RightLeg,1,0,0,6,100,60,0,6,-0.5,-0.5,0.39999999999999997,12,90,7.5,0,6,-0.5,0,0,6,-90,0,0,6,DevAwardsAdurite_Handle,0,0,0,1.5,0,0,0,1.5,-0.25,0,0,1.5,0,0,0,1.5,0,0,0,1.5,0,0,0,1.5,Torso,0,0,0,6,-80,5,0.3333333333333333,12,-0.5,0.3,0.16666666666666666,12,-0,5,0.06666666666666667,6,0,0,0,6,180,0,0,6,LeftArm,-0.8,-0.1,0,6,180,-10,0.39999999999999997,12,0.5,0.1,0,6,-10,0,0,6,-0.2,0,0,6,90,0,0,6,RightArm,0.8,-0.1,0,6,180,-10,0.39999999999999997,12,0.5,-0.1,0,6,10,0,0,6,-0.2,0,0,6,-90,0,0,6
end,
})
addmode('l', {
idle = function()
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.04363323129985824
* sin((sine + 0.1) * 1),
-0.17453292519943295 * sin((sine + 0.1) * 5),
-3.141592653589793
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(
1,
-1 + 0.2 * sin(sine * 5),
-0.2 + 0.2 * sin(sine * 5)
),
angles(
2.181661564992912
- 0.8726646259971648 * sin(sine * 5),
1.9198621771937625
- 0.3490658503988659 * sin(sine * 5),
-1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(0.7, 0.8, 0),
angles(
1.0471975511965976
+ 0.03490658503988659 * sin(sine * 10),
2.0943951023931953
+ 0.10471975511965978
* sin((sine + 0.1) * 5),
1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(
-1,
-1 - 0.2 * sin(sine * 5),
-0.2 - 0.2 * sin(sine * 5)
),
angles(
2.181661564992912
+ 0.8726646259971648 * sin(sine * 5),
-1.9198621771937625
- 0.3490658503988659 * sin(sine * 5),
1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, 0.15 + 0.4 * sin((sine - 0.5) * 10), 0),
angles(
-1.4835298641951802,
0.17453292519943295 * sin(sine * 5),
-3.141592653589793
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-0.7, 0.5, -0.3),
angles(
1.7453292519943295,
-0.8726646259971648,
1.5707963267948966
)
),
deltaTime
)
--Head,0,0,0,5,-90,2.5,0.1,1,1,0,0,4,0,-10,0.1,5,0,0,0,4,-180,0,0,4,RightLeg,1,0,0,4,125,-50,0,5,-1,0.2,0,5,110,-20,0,5,-0.2,0.2,0,5,-90,0,0,4,RightArm,0.7,0,0,4,60,2,0,10,0.8,0,0,4,120,6,0.1,5,0,0,0,4,90,0,0,4,LeftLeg,-1,0,0,4,125,50,0,5,-1,-0.2,0,5,-110,-20,0,5,-0.2,-0.2,0,5,90,0,0,4,Torso,0,0,0,4,-85,0,0,4,0.15,0.4,-0.5,10,0,10,0,5,0,0,0,4,-180,0,0,4,LeftArm,-0.7,0,0,4,100,0,0,4,0.5,0,0,4,-50,0,0,4,-0.3,0,0,4,90,0,0,4
end,
})
end)
btn('Immortality Lord', function()
local backup = accessorylimbs
accessorylimbs = {
{
meshid = '17269636541',
textureid = '',
C0 = cf_0,
Name = 'Torso',
},
{
meshid = '17269753087',
textureid = '',
C0 = angles(0, 3.14, 0),
Name = 'Head',
},
{
meshid = '17375312569',
textureid = '',
C0 = cf(
1.50995803e-08,
-1.07200003,
-0.100000001,
-1,
0,
1.50995803e-07,
0,
1,
0,
-1.50995803e-07,
0,
-1
),
Name = 'Head',
},
{
meshid = '17269487439',
textureid = '',
C0 = angles(0, 0, 1.5707963267948966),
Name = 'Left Arm',
},
{
meshid = '17269487439',
textureid = '',
C0 = angles(0, 0, 1.5707963267948966),
Name = 'Right Arm',
},
{
meshid = '17269487439',
textureid = '',
C0 = angles(0, 0, 1.5707963267948966),
Name = 'Left Leg',
},
{
meshid = '17269487439',
textureid = '',
C0 = angles(0, 0, 1.5707963267948966),
Name = 'Right Leg',
},
{
meshid = '111946216585470',
textureid = '',
C0 = cf_0,
Name = 'Torso',
},
{
meshid = '92572400594624',
textureid = '',
C0 = angles(0, 3.14, 0),
Name = 'Head',
},
{
meshid = '117649985156221',
textureid = '',
C0 = cf_0,
Name = 'Left Arm',
},
{
meshid = '93749227415046',
textureid = '',
C0 = cf_0,
Name = 'Right Arm',
},
{
meshid = '137156465227879',
textureid = '',
C0 = cf_0,
Name = 'Left Leg',
},
{
meshid = '76010149115685',
textureid = '',
C0 = cf_0,
Name = 'Right Leg',
},
{
meshid = '126825022897778',
textureid = '',
C0 = cf_0,
Name = 'Torso',
},
{
meshid = '138744606849121',
textureid = '83207562332062',
C0 = angles(0, 0, 1.5707963267948966),
Name = 'Left Arm',
},
{
meshid = '138744606849121',
textureid = '83207562332062',
C0 = angles(0, 0, 1.5707963267948966),
Name = 'Right Arm',
},
{
meshid = '138744606849121',
textureid = '136752500636691',
C0 = angles(0, 0, 1.5707963267948966),
Name = 'Left Leg',
},
{
meshid = '138744606849121',
textureid = '136752500636691',
C0 = angles(0, 0, 1.5707963267948966),
Name = 'Right Leg',
},
}
local t = reanimate()
accessorylimbs = backup
if type(t) ~= 'table' then
return
end
local getJoint = t.getJoint
local RootJoint = getJoint('RootJoint')
local RightShoulder = getJoint('Right Shoulder')
local LeftShoulder = getJoint('Left Shoulder')
local RightHip = getJoint('Right Hip')
local LeftHip = getJoint('Left Hip')
local Neck = getJoint('Neck')
local getVel = t.getVel
local setCfr = t.setCfr
local getCamCF = t.getCamCF
local cframes = t.cframes
local joints = t.joints
local getAccWeldFromMesh = t.getAccWeldFromMesh
local setWalkSpeed = t.setWalkSpeed
local fling = t.fling
local rad = math.rad
Neck.C1 = cf(0, -1, 0, -1, 0, 0, 0, 0, 1, 0, 1, -0)
RootJoint.C1 = cf(0, 0, 0, -1, 0, 0, 0, 0, 1, 0, 1, -0)
RightShoulder.C1 = cf(-1, 1, 0, 0, 0, 1, 0, 1, -0, -1, 0, 0)
LeftShoulder.C1 = cf(1, 1, 0, 0, 0, -1, 0, 1, 0, 1, 0, 0)
RightHip.C1 = cf(1, 2, 0, 0, 0, 1, 0, 1, -0, -1, 0, 0)
LeftHip.C1 = cf(-1, 2, 0, 0, 0, -1, 0, 1, 0, 1, 0, 0)
setWalkSpeed(32)
t.setJumpPower(0)
t.setHipHeight(7)
t.setGravity(math.huge)
local torso = t.getPart('Torso')
local rootpart = t.getPart('HumanoidRootPart')
local leftWingPart = {}
cframes[leftWingPart] = cf_0
local leftWingAccWeld = getAccWeldFromMesh('17269814619', '')
leftWingAccWeld.C0 = angles(0, 3.14, 0)
leftWingAccWeld.C1 = cf_0
leftWingAccWeld.Part1 = leftWingPart
local LeftWing = {
C0 = cf(-0.3, 1, 1) * angles(0, 1.5707963267948966, 0),
C1 = cf(2.2, 2, 1.5),
Part0 = torso,
Part1 = leftWingPart,
}
tinsert(joints, LeftWing)
local rightWingPart = {}
cframes[rightWingPart] = cf_0
local rightWingAccWeld = getAccWeldFromMesh('17269824947', '')
rightWingAccWeld.C0 = angles(0, 3.14, 0)
rightWingAccWeld.C1 = cf_0
rightWingAccWeld.Part1 = rightWingPart
local RightWing = {
C0 = cf(0.3, 1, 1) * angles(0, 1.5707963267948966, 0),
C1 = cf(2.2, 2, -1.5),
Part0 = torso,
Part1 = rightWingPart,
}
tinsert(joints, RightWing)
local swordpart = {}
cframes[swordpart] = cf_0
local swordAccWeld0 = getAccWeldFromMesh('17326555172', '')
swordAccWeld0.C0 = cf(
-0.0023765564,
2.14191723,
3.825109,
-1,
0,
0,
0,
-0.519688249,
-0.85435611,
0,
-0.854355931,
0.519688308
)
swordAccWeld0.C1 = cf_0
swordAccWeld0.Part1 = swordpart
local swordAccWeld1 = getAccWeldFromMesh('17326476901', '')
swordAccWeld1.C0 = cf(
-0.00237464905,
-1.31204176,
-3.18902349,
-1,
0,
0,
0,
-0.519688249,
-0.85435611,
0,
-0.854355931,
0.519688308
)
swordAccWeld1.C1 = cf_0
swordAccWeld1.Part1 = swordpart
local Sword = {
C0 = cf(0, -2, 0) * angles(1.57, 0, 0),
C1 = cf(0, -6.3, 0),
Part0 = t.getPart('Right Arm'),
Part1 = swordpart,
}
tinsert(joints, Sword)
local DefaultsNeckC0 = cf(0, 2, 0)
* angles(-1.5707963267948966, 0, 3.141592653589793)
local DefaultsRootJointC0 = angles(
-1.5707963267948966,
0,
3.141592653589793
)
local DefaultsRightShoulderC0 = cf(-1, 0, 0)
* angles(0, 1.5707963267948966, 0)
local DefaultsLeftShoulderC0 = cf(1, 0, 0)
* angles(0, -1.5707963267948966, 0)
local TimingSine = sine * 60
local attacking = false
local animOverwrite = nil
local neckSnap = false
local Lerp1 = function(a, b, c)
return Lerp(a, b, min(c * 6 * deltaTime, 1))
end
local v3_030 = v3_010 * 3
local flycf = nil
local flypos = nil
local charcf = cf_0
local animations = function(onground)
TimingSine = sine * 60
local vel = getVel()
local xzvel = vel * v3_101
if flycf then
if xzvel ~= v3_0 then
local camrot = cfGet(getCamCF(), 'Rotation')
local clv = cfGet(camrot, 'LookVector')
local crv = cfGet(camrot, 'RightVector')
local fw = v3Get(clv * v3_101, 'Unit') * xzvel
fw = clv * (v3Get(fw, 'X') + v3Get(fw, 'Z'))
local rt = v3Get(crv * v3_101, 'Unit') * xzvel
rt = crv * (v3Get(rt, 'X') + v3Get(rt, 'Z'))
flypos = flypos
+ v3Get(fw + rt, 'Unit') * deltaTime * 3.2
flycf = cfAdd(camrot, flypos)
charcf = cfAdd(
flycf,
cfGet(flycf, 'UpVector') * 3 - v3_030
)
end
cframes[rootpart] = flycf
setCfr(charcf)
elseif onground then
charcf = cframes[rootpart]
elseif cframes[rootpart].Y < charcf.Y then
local newcf = cframes[rootpart]
local lastY = cfGet(charcf, 'Y')
charcf = cfAdd(
cfGet(newcf, 'Rotation'),
v3(
cfGet(newcf, 'X'),
lastY
+ (cfGet(newcf, 'Y') - lastY)
* deltaTime
* 0.6,
cfGet(newcf, 'Z')
)
)
cframes[rootpart] = charcf
setCfr(charcf)
else
charcf = cframes[rootpart]
end
if attacking then
animOverwrite()
elseif xzvel ~= v3_0 then
if neckSnap then
Neck.C0 = DefaultsNeckC0
neckSnap = false
else
Neck.C0 = Lerp1(Neck.C0, DefaultsNeckC0, 0.25)
end
if mrandom(15) == 1 then
Neck.C0 = DefaultsNeckC0
* angles(
rad(mrandom(-20, 20)),
rad(mrandom(-20, 20)),
rad(mrandom(-20, 20))
)
neckSnap = true
end
if onground and not flycf then
RightShoulder.C0 = Lerp1(
RightShoulder.C0,
cf(3, 1, 0)
* angles(-0.17453292519943295, 0, 0)
* DefaultsRightShoulderC0,
0.25
)
Sword.C0 = Lerp1(
Sword.C0,
cf(0, -2, 0)
* angles(
rad(154.35 - 5.65 * sin(TimingSine / 25)),
0,
0
),
0.25
)
else
RightShoulder.C0 = Lerp1(
RightShoulder.C0,
cf(3, 1, 0)
* angles(
rad(80 + 5 * cos(TimingSine / 25)),
0,
0.7853981633974483
)
* DefaultsRightShoulderC0,
0.25
)
Sword.C0 = Lerp1(
Sword.C0,
cf(0, -0, -1)
* angles(
0,
2.9670597283903604,
-0.17453292519943295
),
0.25
)
end
RootJoint.C0 = Lerp1(
RootJoint.C0,
DefaultsRootJointC0
* cf(0, 0, -sin(TimingSine / 25))
* angles(0.3490658503988659, 0, 0),
0.25
)
LeftShoulder.C0 = Lerp1(
LeftShoulder.C0,
cf(-3, 1, 0)
* angles(
0.3490658503988659,
0,
rad(-10 - 10 * cos(TimingSine / 25))
)
* DefaultsLeftShoulderC0,
0.25
)
RightHip.C0 = Lerp1(
RightHip.C0,
cf(2, -2, 0)
* angles(
-0.3490658503988659,
1.3962634015954636,
rad(10 + 10 * cos(TimingSine / 25))
),
0.25
)
LeftHip.C0 = Lerp1(
LeftHip.C0,
cf(-2, -2, 0)
* angles(
-0.17453292519943295,
-1.3962634015954636,
rad(-10 - 10 * cos(TimingSine / 25))
),
0.25
)
else
RootJoint.C0 = Lerp1(
RootJoint.C0,
DefaultsRootJointC0
* cf(0, 0, -sin(TimingSine / 25))
* angles(0.3490658503988659, 0, 0),
0.25
)
if neckSnap then
Neck.C0 = DefaultsNeckC0
* angles(
0.3490658503988659,
rad(10 * sin(TimingSine / 50)),
0
)
neckSnap = false
else
Neck.C0 = Lerp1(
Neck.C0,
DefaultsNeckC0
* angles(
0.3490658503988659,
rad(10 * sin(TimingSine / 50)),
0
),
0.25
)
end
if mrandom(15) == 1 then
Neck.C0 = DefaultsNeckC0
* angles(
rad(20 + mrandom(-20, 20)),
rad(
(10 * sin(TimingSine / 50))
+ mrandom(-20, 20)
),
rad(mrandom(-20, 20))
)
neckSnap = true
end
if onground and not flycf then
RightShoulder.C0 = Lerp1(
RightShoulder.C0,
cf(3, 1, 0)
* angles(-0.17453292519943295, 0, 0)
* DefaultsRightShoulderC0,
0.25
)
Sword.C0 = Lerp1(
Sword.C0,
cf(0, -2, 0)
* angles(
rad(154.35 - 5.65 * sin(TimingSine / 25)),
0,
0
),
0.25
)
else
RightShoulder.C0 = Lerp1(
RightShoulder.C0,
cf(3, 1, 0)
* angles(
rad(80 + 5 * cos(TimingSine / 25)),
0,
0.7853981633974483
)
* DefaultsRightShoulderC0,
0.25
)
Sword.C0 = Lerp1(
Sword.C0,
cf(0, 0, -1)
* angles(
0,
2.9670597283903604,
-0.17453292519943295
),
0.25
)
end
LeftShoulder.C0 = Lerp1(
LeftShoulder.C0,
cf(-3, 1, 0)
* angles(
0.3490658503988659,
0,
rad(-10 - 10 * cos(TimingSine / 25))
)
* DefaultsLeftShoulderC0,
0.25
)
RightHip.C0 = Lerp1(
RightHip.C0,
cf(2, -2, 0)
* angles(
0.17453292519943295,
1.3962634015954636,
rad(10 + 10 * cos(TimingSine / 25))
),
0.25
)
LeftHip.C0 = Lerp1(
LeftHip.C0,
cf(-2, -2, 0)
* angles(
0.3490658503988659,
-1.3962634015954636,
rad(-10 - 10 * cos(TimingSine / 25))
),
0.25
)
end
RightWing.C0 = Lerp1(
RightWing.C0,
cf(0.3, 1, 1)
* angles(0, rad(105 - 25 * cos(TimingSine / 25)), 0),
0.25
)
LeftWing.C0 = Lerp1(
LeftWing.C0,
cf(-0.3, 1, 1)
* angles(0, rad(75 + 25 * cos(TimingSine / 25)), 0),
0.25
)
end
local onKeyPressed = function(key)
if key == 'f' then
if flycf then
flycf = nil
charcf = cf(flypos)
setCfr(charcf)
else
flypos = cfGet(cframes[rootpart], 'Position')
flycf = cf(flypos)
charcf = flycf
end
elseif key == 'z' then
if attacking then
return
end
attacking = true
setWalkSpeed(0)
animOverwrite = function()
RootJoint.C0 = Lerp1(
RootJoint.C0,
DefaultsRootJointC0
* cf(0, 0, -sin(TimingSine / 25))
* angles(
0.08726646259971647,
0,
-0.3490658503988659
),
0.25
)
if neckSnap then
Neck.C0 = DefaultsNeckC0
neckSnap = false
else
Neck.C0 = Lerp1(Neck.C0, DefaultsNeckC0, 0.25)
end
if mrandom(15) == 1 then
Neck.C0 = DefaultsNeckC0
* angles(
rad(mrandom(-20, 20)),
rad(mrandom(-20, 20)),
rad(mrandom(-20, 20))
)
neckSnap = true
end
RightShoulder.C0 = Lerp1(
RightShoulder.C0,
cf(3, 1, 0)
* angles(
1.3962634015954636,
0,
0.8726646259971648
)
* DefaultsRightShoulderC0,
0.25
)
Sword.C0 = Lerp1(
Sword.C0,
cf(-1, -1, 0)
* angles(
3.141592653589793,
-1.5707963267948966,
0
),
0.25
)
LeftShoulder.C0 = Lerp1(
LeftShoulder.C0,
cf(-3, 1, 0)
* angles(
0.08726646259971647,
0,
rad(-10 - 10 * cos(TimingSine / 25))
)
* DefaultsLeftShoulderC0,
0.25
)
RightHip.C0 = Lerp1(
RightHip.C0,
cf(2, -2, 0)
* angles(
-0.3490658503988659,
1.3962634015954636,
rad(10 + 10 * cos(TimingSine / 25))
),
0.25
)
LeftHip.C0 = Lerp1(
LeftHip.C0,
cf(-2, -2, 0)
* angles(
-0.17453292519943295,
-1.3962634015954636,
rad(-10 - 10 * cos(TimingSine / 25))
),
0.25
)
end
twait(0.25)
local flingpos = cfGet(
cfMul(cframes[rootpart], cf(0, 0, -9)),
'Position'
)
for i, v in next, GetDescendants(ws) do
if IsA(v, 'Humanoid') then
local p = v.Parent
p = gp(p, 'HumanoidRootPart', 'BasePart')
or FindFirstChildWhichIsA(p, 'BasePart')
if
p
and (
v3Get(
insGet(p, 'Position') - flingpos,
'Magnitude'
) < 9
)
then
fling(v)
end
end
end
animOverwrite = function()
RootJoint.C0 = Lerp1(
RootJoint.C0,
DefaultsRootJointC0
* cf(0, 0, -sin(TimingSine / 25))
* angles(
0.08726646259971647,
0,
0.3490658503988659
),
0.25
)
if neckSnap then
Neck.C0 = DefaultsNeckC0
neckSnap = false
else
Neck.C0 = Lerp1(Neck.C0, DefaultsNeckC0, 0.25)
end
if mrandom(15) == 1 then
Neck.C0 = DefaultsNeckC0
* angles(
rad(mrandom(-20, 20)),
rad(mrandom(-20, 20)),
rad(mrandom(-20, 20))
)
neckSnap = true
end
RightShoulder.C0 = Lerp1(
RightShoulder.C0,
cf(2, 1, -1)
* angles(
1.3962634015954636,
0,
-0.8726646259971648
)
* DefaultsRightShoulderC0,
0.25
)
Sword.C0 = Lerp1(
Sword.C0,
cf(-1, -1, 0)
* angles(
3.141592653589793,
-1.5707963267948966,
0
),
0.25
)
LeftShoulder.C0 = Lerp1(
LeftShoulder.C0,
cf(-3, 1, 0)
* angles(
0.08726646259971647,
0,
rad(-10 - 10 * cos(TimingSine / 25))
)
* DefaultsLeftShoulderC0,
0.25
)
RightHip.C0 = Lerp1(
RightHip.C0,
cf(2, -2, 0)
* angles(
-0.3490658503988659,
1.3962634015954636,
rad(10 + 10 * cos(TimingSine / 25))
),
0.25
)
LeftHip.C0 = Lerp1(
LeftHip.C0,
cf(-2, -2, 0)
* angles(
-0.17453292519943295,
-1.3962634015954636,
rad(-10 - 10 * cos(TimingSine / 25))
),
0.25
)
end
twait(0.25)
setWalkSpeed(32)
attacking = false
elseif key == 'x' then
attacking = true
setWalkSpeed(0)
local newpos = cfGet(insGet(mouse, 'Hit'), 'Position')
+ v3_010 * 10
local newcf = cfl(
newpos,
newpos + cfGet(getCamCF(), 'LookVector') * v3_101
)
animOverwrite = function()
RootJoint.C0 = Lerp1(
RootJoint.C0,
DefaultsRootJointC0
* cf(0, 0, -sin(TimingSine / 25))
* angles(0.3490658503988659, 0, 0),
0.25
)
if neckSnap then
Neck.C0 = DefaultsNeckC0
neckSnap = false
else
Neck.C0 = Lerp1(Neck.C0, DefaultsNeckC0, 0.25)
end
if mrandom(15) == 1 then
Neck.C0 = DefaultsNeckC0
* angles(
rad(mrandom(-20, 20)),
rad(mrandom(-20, 20)),
rad(mrandom(-20, 20))
)
neckSnap = true
end
RightShoulder.C0 = Lerp1(
RightShoulder.C0,
cf(3, 1, 0)
* angles(
rad(80 + 5 * cos(TimingSine / 25)),
0,
0.7853981633974483
)
* DefaultsRightShoulderC0,
0.25
)
Sword.C0 = Lerp1(
Sword.C0,
cf(0, -0, -1)
* angles(
0,
2.9670597283903604,
-0.17453292519943295
),
0.25
)
LeftShoulder.C0 = Lerp1(
LeftShoulder.C0,
cf(-3, 1, 0)
* angles(
0.3490658503988659,
0,
rad(-10 - 10 * cos(TimingSine / 25))
)
* DefaultsLeftShoulderC0,
0.25
)
RightHip.C0 = Lerp1(
RightHip.C0,
cf(2, -2, 0)
* angles(
-0.3490658503988659,
1.3962634015954636,
rad(10 + 10 * cos(TimingSine / 25))
),
0.25
)
LeftHip.C0 = Lerp1(
LeftHip.C0,
cf(-2, -2, 0)
* angles(
-0.17453292519943295,
-1.3962634015954636,
rad(-10 - 10 * cos(TimingSine / 25))
),
0.25
)
end
twait(0.5)
local animStart = sine
animOverwrite = function()
RootJoint.C0 = Lerp1(
RootJoint.C0,
DefaultsRootJointC0
* cf(0, 0, -20 * (0.5 + sine - animStart))
* angles(0.3490658503988659, 0, 0),
0.25
)
if neckSnap then
Neck.C0 = DefaultsNeckC0
neckSnap = false
else
Neck.C0 = Lerp1(Neck.C0, DefaultsNeckC0, 0.25)
end
if mrandom(15) == 1 then
Neck.C0 = DefaultsNeckC0
* angles(
rad(mrandom(-20, 20)),
rad(mrandom(-20, 20)),
rad(mrandom(-20, 20))
)
neckSnap = true
end
RightShoulder.C0 = Lerp1(
RightShoulder.C0,
cf(3, 1, 0)
* angles(
rad(80 + 5 * cos(TimingSine / 25)),
0,
0.7853981633974483
)
* DefaultsRightShoulderC0,
0.25
)
Sword.C0 = Lerp1(
Sword.C0,
cf(0, -0, -1)
* angles(
0,
2.9670597283903604,
-0.17453292519943295
),
0.25
)
LeftShoulder.C0 = Lerp1(
LeftShoulder.C0,
cf(-3, 1, 0)
* angles(
0.3490658503988659,
0,
rad(-10 - 10 * cos(TimingSine / 25))
)
* DefaultsLeftShoulderC0,
0.25
)
RightHip.C0 = Lerp1(
RightHip.C0,
cf(2, -2, 0)
* angles(
-0.3490658503988659,
1.3962634015954636,
rad(10 + 10 * cos(TimingSine / 25))
),
0.25
)
LeftHip.C0 = Lerp1(
LeftHip.C0,
cf(-2, -2, 0)
* angles(
-0.17453292519943295,
-1.3962634015954636,
rad(-10 - 10 * cos(TimingSine / 25))
),
0.25
)
end
twait(0.5)
if flycf then
flycf = newcf
flypos = newpos
end
charcf = newcf
setCfr(newcf)
twait(0.5)
animStart = sine
animOverwrite = function()
RootJoint.C0 = Lerp1(
RootJoint.C0,
DefaultsRootJointC0
* cf(
0,
0,
(-sin(TimingSine / 25))
- (10 - (sine - animStart) * 20)
)
* angles(0.3490658503988659, 0, 0),
0.25
)
if neckSnap then
Neck.C0 = DefaultsNeckC0
neckSnap = false
else
Neck.C0 = Lerp1(Neck.C0, DefaultsNeckC0, 0.25)
end
if mrandom(15) == 1 then
Neck.C0 = DefaultsNeckC0
* angles(
rad(mrandom(-20, 20)),
rad(mrandom(-20, 20)),
rad(mrandom(-20, 20))
)
neckSnap = true
end
RightShoulder.C0 = Lerp1(
RightShoulder.C0,
cf(3, 1, 0)
* angles(
rad(80 + 5 * cos(TimingSine / 25)),
0,
0.7853981633974483
)
* DefaultsRightShoulderC0,
0.25
)
Sword.C0 = Lerp1(
Sword.C0,
cf(0, -0, -1)
* angles(
0,
2.9670597283903604,
-0.17453292519943295
),
0.25
)
LeftShoulder.C0 = Lerp1(
LeftShoulder.C0,
cf(-3, 1, 0)
* angles(
0.3490658503988659,
0,
rad(-10 - 10 * cos(TimingSine / 25))
)
* DefaultsLeftShoulderC0,
0.25
)
RightHip.C0 = Lerp1(
RightHip.C0,
cf(2, -2, 0)
* angles(
-0.3490658503988659,
1.3962634015954636,
rad(10 + 10 * cos(TimingSine / 25))
),
0.25
)
LeftHip.C0 = Lerp1(
LeftHip.C0,
cf(-2, -2, 0)
* angles(
-0.17453292519943295,
-1.3962634015954636,
rad(-10 - 10 * cos(TimingSine / 25))
),
0.25
)
end
twait(0.5)
setWalkSpeed(32)
attacking = false
end
end
local animations1 = function()
animations(true)
end
local animations0 = function()
animations(false)
end
local lastmode = 'default'
t.addmode('default', {
modeEntered = function()
onKeyPressed(lastmode)
lastmode = 'default'
end,
idle = animations1,
walk = animations1,
jump = animations0,
fall = animations0,
})
t.addmode('z', {
modeEntered = function()
onKeyPressed('z')
lastmode = 'z'
end,
idle = animations1,
walk = animations1,
jump = animations0,
fall = animations0,
})
t.addmode('x', {
modeEntered = function()
onKeyPressed('x')
lastmode = 'x'
end,
idle = animations1,
walk = animations1,
jump = animations0,
fall = animations0,
})
t.addmode('f', {
modeEntered = function()
onKeyPressed('f')
lastmode = 'f'
end,
idle = animations1,
walk = animations1,
jump = animations0,
fall = animations0,
})
end)
lbl('(needs specific accessories)')
btn('goofy trolus (goofy)', function()
local t = reanimate()
if type(t) ~= 'table' then
return
end
local velbycfrvec = t.velbycfrvec
local raycastlegs = t.raycastlegs
local getJoint = t.getJoint
local RootJoint = getJoint('RootJoint')
local RightShoulder = getJoint('Right Shoulder')
local LeftShoulder = getJoint('Left Shoulder')
local RightHip = getJoint('Right Hip')
local LeftHip = getJoint('Left Hip')
local Neck = getJoint('Neck')
t.addmode('default', {
idle = function()
local rY, lY = raycastlegs()
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
0.6981317007977318 * sin((sine + 0.5) * 4),
1.5707963267948966
- 0.3490658503988659 * sin(sine * 4),
0
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
0.6981317007977318 * sin((sine + 0.5) * 4),
-1.5707963267948966
+ 0.3490658503988659 * sin(sine * 4),
0
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1 + rY, 0),
angles(
1.5707963267948966
- 1.0471975511965976 * sin(sine * 4),
1.6580627893946132,
-1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, -0.2 + 0.2 * sin((sine + 1) * 8), 0),
angles(
-1.5707963267948966
+ 0.6981317007977318 * sin(sine * 4),
0,
3.141592653589793
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1 + lY, 0),
angles(
1.5707963267948966
- 1.0471975511965976 * sin(sine * 4),
-1.6580627893946132,
1.5707963267948966
)
),
deltaTime
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
- 0.8726646259971648
* sin((sine + 0.25) * 4),
0,
3.141592653589793
)
),
deltaTime
)
--RightArm,1,0,0,4,0,40,0.5,4,0.5,0,0,4,90,-20,0,4,0,0,0,4,0,0,0,4,LeftArm,-1,0,0,4,-0,40,0.5,4,0.5,0,0,4,-90,20,0,4,0,0,0,4,0,0,0,4,RightLeg,1,0,0,4,90,-60,0,4,-1,0,0,4,95,0,0,4,0,0,0,4,-90,0,0,4,Torso,0,0,0,4,-90,40,0,4,-0.2,0.2,1,8,-0,0,0,4,0,0,0,4,180,0,0,4,LeftLeg,-1,0,0,4,90,-60,0,4,-1,0,0,4,-95,0,0,4,0,0,0,4,90,0,0,4,Head,0,0,0,4,-90,-50,0.25,4,1,0,0,4,-0,0,0,4,0,0,0,4,180,0,0,4,CPlusPlusTextbook_Handle,8.658389560878277e-09,0,0,4,0,0,0,4,-0.25,0,0,4,0,0,0,4,-0.0002722442150115967,0,0,4,0,0,0,4
end,
walk = function()
local fw, rt = velbycfrvec()
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.5235987755982988
* sin((sine + 0.45) * 8),
0,
3.141592653589793
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
2.0943951023931953
- 1.7453292519943295
* sin((sine - 0.1) * 4),
1.9198621771937625,
-1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, 0.25 + 0.5 * sin((sine - 0.125) * 8), 0),
angles(
-1.5707963267948966
+ 0.17453292519943295 * sin(sine * 8),
0,
3.141592653589793
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1 - 1 * sin(sine * 4), 0),
angles(
1.5707963267948966
- 1.2217304763960306
* sin((sine - 0.15) * 4)
* fw,
-1.5707963267948966
- 0.6108652381980153
* sin((sine - 0.15) * 4)
* rt,
1.5707963267948966
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1 + 1 * sin(sine * 4), 0),
angles(
1.5707963267948966
+ 1.2217304763960306
* sin((sine - 0.15) * 4)
* fw,
1.5707963267948966
+ 0.6108652381980153
* sin((sine - 0.15) * 4)
* rt,
-1.5707963267948966
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
2.0943951023931953
+ 1.7453292519943295
* sin((sine - 0.1) * 4),
-1.7453292519943295,
1.5707963267948966
)
),
deltaTime
)
--Head,0,0,0,4,-90,30,0.45,8,1,0,0,4,-0,0,0,4,0,0,0,4,180,0,0,4,CPlusPlusTextbook_Handle,8.658389560878277e-09,0,0,4,0,0,0,4,-0.25,0,0,4,0,0,0,4,-0.0002722442150115967,0,0,4,0,0,0,4,RightArm,1,0,0,4,120,-100,-0.1,4,0.5,0,0,4,110,0,0,4,0,0,0,4,-90,0,0,4,Torso,0,0,0,4,-90,10,0,8,0.25,0.5,-0.125,8,-0,0,0,4,0,0,0,4,180,0,0,4,LeftLeg,-1,0,0,4,90,-70,-0.15,4,-1,-1,0,4,-90,-35,-0.15,4,0,0,0,4,90,0,0,4,RightLeg,1,0,0,4,90,70,-0.15,4,-1,1,0,4,90,35,-0.15,4,0,0,0,4,-90,0,0,4,LeftArm,-1,0,0,4,120,100,-0.1,4,0.5,0,0,4,-100,0,0,4,0,0,0,4,90,0,0,4
end,
})
end)
btn('good cop bad cop animations', function()
local t = reanimate()
if type(t) ~= 'table' then
return
end
local addmode = t.addmode
local getJoint = t.getJoint
local RootJoint = getJoint('RootJoint')
local RightShoulder = getJoint('Right Shoulder')
local LeftShoulder = getJoint('Left Shoulder')
local RightHip = getJoint('Right Hip')
local LeftHip = getJoint('Left Hip')
local Neck = getJoint('Neck')
local setWalkSpeed = t.setWalkSpeed
local setJumpPower = t.setJumpPower
setWalkSpeed(20)
setJumpPower(50)
local ROOTC0 = angles(-1.5707963267948966, 0, 3.141592653589793)
local NECKC0 = cfMul(
cf(0, 1, 0),
angles(-1.5707963267948966, 0, 3.141592653589793)
)
local RIGHTSHOULDERC0 = cfMul(
cf(-0.5, 0, 0),
angles(0, 1.5707963267948966, 0)
)
local LEFTSHOULDERC0 = cfMul(
cf(0.5, 0, 0),
angles(0, -1.5707963267948966, 0)
)
local rad = math.rad
--bruh yeah shackluster had a lot of math.rad(0) instead of just 0
--and a lot of multyplying by angles(0, 0, 0)
--and he had ArtificialHB
--and he had a sine value increasing by 2/3 each frame
--and a lot of variables with names saying other things
--and he had both C0 and C1 lerps for the same animations
local jumplerps = function()
local Animation_Speed = 0.45 / deltaTime
RootJoint.C1 = Lerp(RootJoint.C1, ROOTC0, 0.2 / Animation_Speed)
Neck.C1 = Lerp(
Neck.C1,
cfMul(
cf(0, -0.5, 0),
angles(-1.5707963267948966, 0, 3.141592653589793)
),
0.2 / Animation_Speed
)
RightHip.C1 = Lerp(
RightHip.C1,
cfMul(cf(0.5, 1, 0), angles(0, 1.5707963267948966, 0)),
0.7 / Animation_Speed
)
LeftHip.C1 = Lerp(
LeftHip.C1,
cfMul(cf(-0.5, 1, 0), angles(0, -1.5707963267948966, 0)),
0.7 / Animation_Speed
)
RootJoint.C0 = Lerp(RootJoint.C0, ROOTC0, 0.2 / Animation_Speed)
Neck.C0 = Lerp(
Neck.C0,
cfMul(NECKC0, angles(-0.3490658503988659, 0, 0)),
0.2 / Animation_Speed
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cfMul(
cf(1.5, 0.5, 0),
angles(-0.6981317007977318, 0, 0.3490658503988659)
),
RIGHTSHOULDERC0
),
0.2 / Animation_Speed
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cfMul(
cf(-1.5, 0.5, 0),
angles(-0.6981317007977318, 0, -0.3490658503988659)
),
LEFTSHOULDERC0
),
0.2 / Animation_Speed
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1, -0.3),
angles(0, 1.5707963267948966, 0),
angles(-0.08726646259971647, 0, -0.3490658503988659)
),
0.2 / Animation_Speed
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1, -0.3),
angles(0, -1.5707963267948966, 0),
angles(-0.08726646259971647, 0, 0.3490658503988659)
),
0.2 / Animation_Speed
)
end
local falllerps = function()
local Animation_Speed = 0.45 / deltaTime
RootJoint.C1 = Lerp(RootJoint.C1, ROOTC0, 0.2 / Animation_Speed)
Neck.C1 = Lerp(
Neck.C1,
cfMul(
cf(0, -0.5, 0),
angles(-1.5707963267948966, 0, 3.141592653589793)
),
0.2 / Animation_Speed
)
RightHip.C1 = Lerp(
RightHip.C1,
cfMul(cf(0.5, 1, 0), angles(0, 1.5707963267948966, 0)),
0.7 / Animation_Speed
)
LeftHip.C1 = Lerp(
LeftHip.C1,
cfMul(cf(-0.5, 1, 0), angles(0, -1.5707963267948966, 0)),
0.7 / Animation_Speed
)
RootJoint.C0 = Lerp(RootJoint.C0, ROOTC0, 0.2 / Animation_Speed)
Neck.C0 = Lerp(
Neck.C0,
cfMul(NECKC0, angles(0.3490658503988659, 0, 0)),
0.2 / Animation_Speed
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cfMul(cf(1.5, 0.5, 0), angles(0, 0, 1.0471975511965976)),
RIGHTSHOULDERC0
),
0.2 / Animation_Speed
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cfMul(
cf(-1.5, 0.5, 0),
angles(0, 0, -1.0471975511965976)
),
LEFTSHOULDERC0
),
0.2 / Animation_Speed
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cfMul(cf(1, -1, 0), angles(0, 1.5707963267948966, 0)),
angles(0, 0, 0.3490658503988659)
),
0.2 / Animation_Speed
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cfMul(cf(-1, -1, 0), angles(0, -1.5707963267948966, 0)),
angles(0, 0, 0.17453292519943295)
),
0.2 / Animation_Speed
)
end
local idleOverwrite = nil
addmode('default', { --mode 1
modeLeft = function() --enter mode 0
setWalkSpeed(0)
setJumpPower(0)
idleOverwrite = function()
local sine = sine * 40
local Animation_Speed = 0.45 / deltaTime
RootJoint.C1 = Lerp(
RootJoint.C1,
ROOTC0,
0.2 / Animation_Speed
)
Neck.C1 = Lerp(
Neck.C1,
cfMul(
cf(0, -0.5, 0),
angles(
-1.5707963267948966,
0,
3.141592653589793
)
),
0.2 / Animation_Speed
)
RightHip.C1 = Lerp(
RightHip.C1,
cfMul(
cf(0.5, 1, 0),
angles(0, 1.5707963267948966, 0)
),
0.7 / Animation_Speed
)
LeftHip.C1 = Lerp(
LeftHip.C1,
cfMul(
cf(-0.5, 1, 0),
angles(0, -1.5707963267948966, 0)
),
0.7 / Animation_Speed
)
RootJoint.C0 = Lerp(
RootJoint.C0,
ROOTC0 * cf(0, 0, 0.05 * cos(sine / 12)),
1 / Animation_Speed
)
Neck.C0 = Lerp(Neck.C0, NECKC0, 1 / Animation_Speed)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cf(1.5, 0.5, 0)
* angles(0, 0, 0.4363323129985824)
* RIGHTSHOULDERC0,
1 / Animation_Speed
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cf(-1.5, 0.5, 0)
* angles(0, 0, -0.4363323129985824)
* LEFTSHOULDERC0,
1 / Animation_Speed
)
RightHip.C0 = Lerp(
RightHip.C0,
cf(1, -1 - 0.05 * cos(sine / 12), -0.01)
* angles(0, 1.4486232791552935, 0),
1 / Animation_Speed
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cf(-1, -1 - 0.05 * cos(sine / 12), -0.01)
* angles(0, -1.4486232791552935, 0),
1 / Animation_Speed
)
end
twait(0.15)
idleOverwrite = function()
local sine = sine * 40
local Animation_Speed = 0.45 / deltaTime
RootJoint.C1 = Lerp(
RootJoint.C1,
ROOTC0,
0.2 / Animation_Speed
)
Neck.C1 = Lerp(
Neck.C1,
cfMul(
cf(0, -0.5, 0),
angles(
-1.5707963267948966,
0,
3.141592653589793
)
),
0.2 / Animation_Speed
)
RightHip.C1 = Lerp(
RightHip.C1,
cfMul(
cf(0.5, 1, 0),
angles(0, 1.5707963267948966, 0)
),
0.7 / Animation_Speed
)
LeftHip.C1 = Lerp(
LeftHip.C1,
cfMul(
cf(-0.5, 1, 0),
angles(0, -1.5707963267948966, 0)
),
0.7 / Animation_Speed
)
RootJoint.C0 = Lerp(
RootJoint.C0,
ROOTC0 * cf(0, 0, 0.05 * cos(sine / 12)),
1 / Animation_Speed
)
Neck.C0 = Lerp(
Neck.C0,
NECKC0 * angles(0.08726646259971647, 0, 0),
1 / Animation_Speed
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cf(1.25, 0.5, -0.5)
* angles(
1.7453292519943295,
0,
-1.2217304763960306
)
* RIGHTSHOULDERC0,
1 / Animation_Speed
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cf(-1.25, 0.35, -0.35)
* angles(
1.2217304763960306,
0,
1.3962634015954636
)
* LEFTSHOULDERC0,
1 / Animation_Speed
)
RightHip.C0 = Lerp(
RightHip.C0,
cf(1, -1 - 0.05 * cos(sine / 12), -0.01)
* angles(0, 1.4486232791552935, 0),
1 / Animation_Speed
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cf(-1, -1 - 0.05 * cos(sine / 12), -0.01)
* angles(0, -1.4486232791552935, 0),
1 / Animation_Speed
)
end
twait(0.5)
--CreateSound(363808674, Torso, 6, 1, false)
idleOverwrite = function()
local sine = sine * 40
local Animation_Speed = 0.45 / deltaTime
RootJoint.C1 = Lerp(
RootJoint.C1,
ROOTC0,
0.2 / Animation_Speed
)
Neck.C1 = Lerp(
Neck.C1,
cfMul(
cf(0, -0.5, 0),
angles(
-1.5707963267948966,
0,
3.141592653589793
)
),
0.2 / Animation_Speed
)
RightHip.C1 = Lerp(
RightHip.C1,
cfMul(
cf(0.5, 1, 0),
angles(0, 1.5707963267948966, 0)
),
0.7 / Animation_Speed
)
LeftHip.C1 = Lerp(
LeftHip.C1,
cfMul(
cf(-0.5, 1, 0),
angles(0, -1.5707963267948966, 0)
),
0.7 / Animation_Speed
)
RootJoint.C0 = Lerp(
RootJoint.C0,
ROOTC0 * cf(0, 0, 0.05 * cos(sine / 12)),
1 / Animation_Speed
)
Neck.C0 = Lerp(
Neck.C0,
NECKC0
* angles(
0.08726646259971647,
0.4363323129985824,
0
),
1 / Animation_Speed
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cf(1.25, 0.5, -0.5)
* angles(
1.7453292519943295,
0,
-0.8726646259971648
)
* RIGHTSHOULDERC0,
1 / Animation_Speed
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cf(-1.25, 0.35, -0.35)
* angles(
1.2217304763960306,
0,
1.0471975511965976
)
* LEFTSHOULDERC0,
1 / Animation_Speed
)
RightHip.C0 = Lerp(
RightHip.C0,
cf(1, -1 - 0.05 * cos(sine / 12), -0.01)
* angles(0, 1.4486232791552935, 0),
1 / Animation_Speed
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cf(-1, -1 - 0.05 * cos(sine / 12), -0.01)
* angles(0, -1.4486232791552935, 0),
1 / Animation_Speed
)
end
twait(0.3)
--CreateSound(363808674, Torso, 6, 1, false)
idleOverwrite = function()
local sine = sine * 40
local Animation_Speed = 0.45 / deltaTime
RootJoint.C1 = Lerp(
RootJoint.C1,
ROOTC0,
0.2 / Animation_Speed
)
Neck.C1 = Lerp(
Neck.C1,
cfMul(
cf(0, -0.5, 0),
angles(
-1.5707963267948966,
0,
3.141592653589793
)
),
0.2 / Animation_Speed
)
RightHip.C1 = Lerp(
RightHip.C1,
cfMul(
cf(0.5, 1, 0),
angles(0, 1.5707963267948966, 0)
),
0.7 / Animation_Speed
)
LeftHip.C1 = Lerp(
LeftHip.C1,
cfMul(
cf(-0.5, 1, 0),
angles(0, -1.5707963267948966, 0)
),
0.7 / Animation_Speed
)
RootJoint.C0 = Lerp(
RootJoint.C0,
ROOTC0 * cf(0, 0, 0.05 * cos(sine / 12)),
1 / Animation_Speed
)
Neck.C0 = Lerp(
Neck.C0,
NECKC0
* angles(
0.08726646259971647,
-0.4363323129985824,
0
),
1 / Animation_Speed
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cf(1.25, 0.5, -0.5)
* angles(
1.7453292519943295,
0,
-1.5707963267948966
)
* RIGHTSHOULDERC0,
1 / Animation_Speed
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cf(-1.25, 0.35, -0.35)
* angles(
1.2217304763960306,
0,
1.5707963267948966
)
* LEFTSHOULDERC0,
1 / Animation_Speed
)
RightHip.C0 = Lerp(
RightHip.C0,
cf(1, -1 - 0.05 * cos(sine / 12), -0.01)
* angles(0, 1.4486232791552935, 0),
1 / Animation_Speed
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cf(-1, -1 - 0.05 * cos(sine / 12), -0.01)
* angles(0, -1.4486232791552935, 0),
1 / Animation_Speed
)
end
twait(0.3)
idleOverwrite = nil
setWalkSpeed(20)
setJumpPower(50)
end,
idle = function()
if idleOverwrite then
return idleOverwrite()
end
local Animation_Speed = 0.45 / deltaTime
local sine = sine * 40
RootJoint.C1 = Lerp(
RootJoint.C1,
ROOTC0,
0.2 / Animation_Speed
)
Neck.C1 = Lerp(
Neck.C1,
cfMul(
cf(0, -0.5, 0),
angles(-1.5707963267948966, 0, 3.141592653589793)
),
0.2 / Animation_Speed
)
RightHip.C1 = Lerp(
RightHip.C1,
cfMul(cf(0.5, 1, 0), angles(0, 1.5707963267948966, 0)),
0.7 / Animation_Speed
)
LeftHip.C1 = Lerp(
LeftHip.C1,
cfMul(cf(-0.5, 1, 0), angles(0, -1.5707963267948966, 0)),
0.7 / Animation_Speed
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
ROOTC0,
cf(0.05 * cos(sine / 12), 0, 0.05 * sin(sine / 12))
),
0.15 / Animation_Speed
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
NECKC0,
angles(
rad(15 - 2.5 * sin(sine / 12)),
0,
-0.4363323129985824
)
),
1 / Animation_Speed
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cfMul(
cf(1.25, 0.5, 0.3),
angles(
-0.7853981633974483,
0,
-0.7853981633974483
)
),
RIGHTSHOULDERC0
),
1 / Animation_Speed
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cfMul(
cf(-1.25, 0.5, 0.3),
angles(
-0.6981317007977318,
0,
0.7853981633974483
)
),
LEFTSHOULDERC0
),
1 / Animation_Speed
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cfMul(
cf(
1 + 0.05 * cos(sine / 12),
-1 - 0.05 * sin(sine / 12),
-0.01
),
angles(0, 1.4835298641951802, 0)
),
angles(-0.017453292519943295, 0, 0)
),
0.15 / Animation_Speed
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cfMul(
cf(
-1 + 0.05 * cos(sine / 12),
-1 - 0.05 * sin(sine / 12),
-0.01
),
angles(0, -1.4835298641951802, 0)
),
angles(-0.017453292519943295, 0, 0)
),
0.15 / Animation_Speed
)
end,
walk = function()
local Animation_Speed = 0.45 / deltaTime
local sine = sine * 40
RootJoint.C1 = Lerp(
RootJoint.C1,
cfMul(ROOTC0, cf(0, 0, 0.05 * cos(sine / 2.4))),
2 * 1.25 / Animation_Speed
)
Neck.C1 = Lerp(
Neck.C1,
cfMul(
cf(0, -0.5, 0),
angles(-1.5707963267948966, 0, 3.141592653589793)
),
0.2 * 1.25 / Animation_Speed
)
RightHip.C1 = Lerp(
RightHip.C1,
cfMul(
cfMul(
cf(
0.5,
0.875
- 0.125 * sin(sine / 4.8)
- 0.15 * cos(sine / 2.4),
0
),
angles(0, 1.5707963267948966, 0)
),
angles(0, 0, rad(35 * cos(sine / 4.8)))
),
0.6 / Animation_Speed
)
LeftHip.C1 = Lerp(
LeftHip.C1,
cfMul(
cfMul(
cf(
-0.5,
0.875
+ 0.125 * sin(sine / 4.8)
- 0.15 * cos(sine / 2.4),
0
),
angles(0, -1.5707963267948966, 0)
),
angles(0, 0, rad(35 * cos(sine / 4.8)))
),
0.6 / Animation_Speed
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(ROOTC0, cf(0, 0, -0.05)),
0.15 / Animation_Speed
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(NECKC0, angles(0.08726646259971647, 0, 0)),
0.15 / Animation_Speed
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cfMul(
cf(1.25, 0.5 + 0.05 * sin(sine / 2.4), 0.3),
angles(
-0.7853981633974483,
0,
-0.7853981633974483
)
),
RIGHTSHOULDERC0
),
1 / Animation_Speed
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cfMul(
cf(-1.25, 0.5 + 0.05 * sin(sine / 2.4), 0.3),
angles(
-0.6981317007977318,
0,
0.7853981633974483
)
),
LEFTSHOULDERC0
),
1 / Animation_Speed
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cfMul(
cf(1, -1, 0),
angles(0, 1.3962634015954636, 0)
),
angles(0, 0, -0.08726646259971647)
),
2 / Animation_Speed
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cfMul(
cf(-1, -1, 0),
angles(0, -1.3962634015954636, 0)
),
angles(0, 0, 0.08726646259971647)
),
2 / Animation_Speed
)
end,
jump = jumplerps,
fall = falllerps,
})
addmode('f', { --mode 0
modeLeft = function() --enter mode 1
setWalkSpeed(0)
setJumpPower(0)
--CreateSound(147722227, Torso, 4, 1.3, false)
idleOverwrite = function()
local sine = sine * 40
local Animation_Speed = 0.45 / deltaTime
RootJoint.C1 = Lerp(
RootJoint.C1,
ROOTC0,
0.2 / Animation_Speed
)
Neck.C1 = Lerp(
Neck.C1,
cfMul(
cf(0, -0.5, 0),
angles(
-1.5707963267948966,
0,
3.141592653589793
)
),
0.2 / Animation_Speed
)
RightHip.C1 = Lerp(
RightHip.C1,
cfMul(
cf(0.5, 1, 0),
angles(0, 1.5707963267948966, 0)
),
0.7 / Animation_Speed
)
LeftHip.C1 = Lerp(
LeftHip.C1,
cfMul(
cf(-0.5, 1, 0),
angles(0, -1.5707963267948966, 0)
),
0.7 / Animation_Speed
)
RootJoint.C0 = Lerp(
RootJoint.C0,
ROOTC0 * cf(0, 0, 0.05 * cos(sine / 12)),
1 / Animation_Speed
)
Neck.C0 = Lerp(
Neck.C0,
NECKC0 * angles(0.6108652381980153, 0, 0),
1 / Animation_Speed
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cf(1.5, 0.5, 0)
* angles(0, 0, 0.4363323129985824)
* RIGHTSHOULDERC0,
1 / Animation_Speed
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cf(-1.5, 0.5, 0)
* angles(0, 0, -0.4363323129985824)
* LEFTSHOULDERC0,
1 / Animation_Speed
)
RightHip.C0 = Lerp(
RightHip.C0,
cf(1, -1 - 0.05 * cos(sine / 12), -0.01)
* angles(0, 1.4486232791552935, 0),
1 / Animation_Speed
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cf(-1, -1 - 0.05 * cos(sine / 12), -0.01)
* angles(0, -1.4486232791552935, 0),
1 / Animation_Speed
)
end
twait(0.15)
idleOverwrite = nil
setWalkSpeed(20)
setJumpPower(50)
end,
idle = function()
if idleOverwrite then
return idleOverwrite()
end
local Animation_Speed = 0.45 / deltaTime
local sine = sine * 40
RootJoint.C1 = Lerp(
RootJoint.C1,
ROOTC0,
0.2 / Animation_Speed
)
Neck.C1 = Lerp(
Neck.C1,
cfMul(
cf(0, -0.5, 0),
angles(-1.5707963267948966, 0, 3.141592653589793)
),
0.2 / Animation_Speed
)
RightHip.C1 = Lerp(
RightHip.C1,
cfMul(cf(0.5, 1, 0), angles(0, 1.5707963267948966, 0)),
0.7 / Animation_Speed
)
LeftHip.C1 = Lerp(
LeftHip.C1,
cfMul(cf(-0.5, 1, 0), angles(0, -1.5707963267948966, 0)),
0.7 / Animation_Speed
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(ROOTC0, cf(0, 0, 0.05 * cos(sine / 12))),
1 / Animation_Speed
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(
NECKC0,
angles(
rad(-5 - 2.5 * cos(sine / 12)),
0,
0.4363323129985824
)
),
1 / Animation_Speed
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cfMul(
cf(0.9, 0.5 + 0.05 * sin(sine / 12), -0.5),
angles(
1.7453292519943295,
0,
-1.2217304763960306
)
),
RIGHTSHOULDERC0
),
1 / Animation_Speed
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cfMul(
cf(-0.9, 0.25 + 0.05 * sin(sine / 12), -0.35),
angles(
1.2217304763960306,
0,
1.3962634015954636
)
),
LEFTSHOULDERC0
),
1 / Animation_Speed
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1 - 0.05 * cos(sine / 12), -0.01),
angles(0, 1.3962634015954636, 0)
),
1 / Animation_Speed
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1 - 0.05 * cos(sine / 12), -0.01),
angles(0, -1.3962634015954636, 0)
),
1 / Animation_Speed
)
end,
walk = function()
local Animation_Speed = 0.45 / deltaTime
local sine = sine * 40
RootJoint.C1 = Lerp(
RootJoint.C1,
cfMul(ROOTC0, cf(0, 0, 0.05 * cos(sine / 2.4))),
2 * 1.25 / Animation_Speed
)
Neck.C1 = Lerp(
Neck.C1,
cfMul(
cf(0, -0.5, 0),
angles(-1.5707963267948966, 0, 3.141592653589793)
),
0.2 * 1.25 / Animation_Speed
)
RightHip.C1 = Lerp(
RightHip.C1,
cfMul(
cfMul(
cf(
0.5,
0.875
- 0.125 * sin(sine / 4.8)
- 0.15 * cos(sine / 2.4),
0
),
angles(0, 1.5707963267948966, 0)
),
angles(0, 0, rad(35 * cos(sine / 4.8)))
),
0.6 / Animation_Speed
)
LeftHip.C1 = Lerp(
LeftHip.C1,
cfMul(
cfMul(
cf(
-0.5,
0.875
+ 0.125 * sin(sine / 4.8)
- 0.15 * cos(sine / 2.4),
0
),
angles(0, -1.5707963267948966, 0)
),
angles(0, 0, rad(35 * cos(sine / 4.8)))
),
0.6 / Animation_Speed
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(ROOTC0, cf(0, 0, -0.05)),
0.15 / Animation_Speed
)
Neck.C0 = Lerp(
Neck.C0,
cfMul(NECKC0, angles(0.08726646259971647, 0, 0)),
0.15 / Animation_Speed
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cfMul(
cf(0.9, 0.5 + 0.05 * sin(sine / 2.4), -0.5),
angles(
1.7453292519943295,
0,
-1.2217304763960306
)
),
RIGHTSHOULDERC0
),
1 / Animation_Speed
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cfMul(
cf(-0.9, 0.25 + 0.05 * sin(sine / 2.4), -0.35),
angles(
1.2217304763960306,
0,
1.3962634015954636
)
),
LEFTSHOULDERC0
),
1 / Animation_Speed
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cfMul(
cf(1, -1, 0),
angles(0, 1.3962634015954636, 0)
),
angles(0, 0, -0.08726646259971647)
),
2 / Animation_Speed
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cfMul(
cf(-1, -1, 0),
angles(0, -1.3962634015954636, 0)
),
angles(0, 0, 0.08726646259971647)
),
2 / Animation_Speed
)
end,
jump = jumplerps,
fall = falllerps,
})
end)
lbl('original by shackluster')
lbl('the classics never die')
btn('metamorphosis vibe', function()
local t = reanimate()
if type(t) ~= 'table' then
return
end
local addmode = t.addmode
local getJoint = t.getJoint
local velbycfrvec = t.velbycfrvec
local RootJoint = getJoint('RootJoint')
local RightShoulder = getJoint('Right Shoulder')
local LeftShoulder = getJoint('Left Shoulder')
local RightHip = getJoint('Right Hip')
local LeftHip = getJoint('Left Hip')
local Neck = getJoint('Neck')
t.setWalkSpeed(4.5)
addmode('default', {
idle = function()
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.7453292519943295
- 0.08726646259971647 * sin(sine * 8),
-0.12217304763960307 * sin((sine + 0.2) * 4),
2.8797932657906435
+ 0.2007128639793479
* sin((sine + 0.15) * 4)
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1 + 0.1 * sin(sine * 4), 0),
angles(
1.5707963267948966,
1.5707963267948966
+ 0.17453292519943295 * sin(sine * 4),
-1.5707963267948966
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.3, 0),
angles(
2.530727415391778
+ 0.20943951023931956
* sin((sine + 0.4) * 8),
1.5707963267948966
- 0.4363323129985824
* sin((sine + 0.2) * 4),
-1.5707963267948966
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
1.0471975511965976,
-1.2217304763960306
+ 0.08726646259971647
* sin((sine + 0.2) * 4),
1.5707963267948966
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1 - 0.1 * sin(sine * 4), 0),
angles(
1.5707963267948966,
-1.5707963267948966
+ 0.17453292519943295 * sin(sine * 4),
1.5707963267948966
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(-0.1 * sin(sine * 4), 0, 0),
angles(
-1.5707963267948966,
0.08726646259971647 * sin(sine * 4),
3.141592653589793
)
),
deltaTime
)
--MW_animatorProgressSave: Fedora_Handle,8.657480066176504e-09,0,0,4,-6,0,0,4,-0.15052366256713867,0,0,4,0,0,0,4,-0.010221302509307861,0,0,4,0,0,0,4,Bandana_Handle,3.9362930692732334e-09,0,0,4,0,0,0,4,0.3000001907348633,0,0,4,0,0,0,4,-0.6002722978591919,0,0,4,0,0,0,4,Head,0,0,0,4,-100,-5,0,8,1,0,0,4,-0,-7,0.2,4,0,0,0,4,165,11.5,0.15,4,RightLeg,1,0,0,4,90,0,0,4,-1,0.1,0,4,90,10,0,4,0,0,0,4,-90,0,0,4,RightArm,1,0,0,4,145,12,0.4,8,0.3,0,0,4,90,-25,0.2,4,0,0,0,4,-90,0,0,4,LeftArm,-1,0,0,4,60,0,0,4,0.5,0,0,4,-70,5,0.2,4,0,0,0,4,90,0,0,4,LeftLeg,-1,0,0,4,90,0,0,4,-1,-0.1,0,4,-90,10,0,4,0,0,0,4,90,0,0,4,Torso,0,-0.1,0,4,-90,0,0,4,0,0,0,4,-0,5,0,4,0,0,0,4,180,0,0,4
end,
walk = function()
local fw, rt = velbycfrvec()
Neck.C0 = Lerp(
Neck.C0,
cfMul(
cf(0, 1, 0),
angles(
-1.5707963267948966
+ 0.08726646259971647
* sin((sine - 0.1) * 8),
0.3490658503988659 * sin((sine - 0.07) * 4),
3.141592653589793
- 0.4363323129985824
* sin((sine - 0.4) * 4)
)
),
deltaTime
)
RightHip.C0 = Lerp(
RightHip.C0,
cfMul(
cf(1, -1 + 0.3 * sin((sine + 0.3) * 4), 0),
angles(
1.5707963267948966,
1.5707963267948966
+ 0.6981317007977318
* sin(sine * 4)
* rt,
-1.5707963267948966
+ 0.6981317007977318
* sin(sine * 4)
* fw
)
),
deltaTime
)
RightShoulder.C0 = Lerp(
RightShoulder.C0,
cfMul(
cf(1, 0.5, 0),
angles(
-0.5235987755982988 * sin((sine + 0.2) * 4),
1.5707963267948966
- 0.3490658503988659 * sin(sine * 4),
0
)
),
deltaTime
)
LeftShoulder.C0 = Lerp(
LeftShoulder.C0,
cfMul(
cf(-1, 0.5, 0),
angles(
0.5235987755982988 * sin((sine + 0.2) * 4),
-1.5707963267948966
- 0.3490658503988659 * sin(sine * 4),
0
)
),
deltaTime
)
LeftHip.C0 = Lerp(
LeftHip.C0,
cfMul(
cf(-1, -1 - 0.3 * sin((sine + 0.3) * 4), 0),
angles(
1.5707963267948966,
-1.5707963267948966
- 0.6981317007977318
* sin(sine * 4)
* rt,
1.5707963267948966
+ 0.6981317007977318
* sin(sine * 4)
* fw
)
),
deltaTime
)
RootJoint.C0 = Lerp(
RootJoint.C0,
cfMul(
cf(0, 0.05 + 0.2 * sin((sine + 0.15) * 8), 0),
angles(-1.5707963267948966, 0, 3.141592653589793)
),
deltaTime
)
--MW_animatorProgressSave: Fedora_Handle,8.657480066176504e-09,0,0,4,-6,0,0,4,-0.15052366256713867,0,0,4,0,0,0,4,-0.010221302509307861,0,0,4,0,0,0,4,Bandana_Handle,3.9362930692732334e-09,0,0,4,0,0,0,4,0.3000001907348633,0,0,4,0,0,0,4,-0.6002722978591919,0,0,4,0,0,0,4,Head,0,0,0,4,-90,5,-0.1,8,1,0,0,4,-0,20,-0.07,4,0,0,0,4,180,-25,-0.4,4,RightLeg,1,0,0,4,90,0,0,4,-1,0.3,0.3,4,90,40,0,4,0,0,0,4,-90,40,0,4,RightArm,1,0,0,4,0,-30,0.2,4,0.5,0,0,4,90,-20,0,4,0,0,0,4,0,0,0,4,LeftArm,-1,0,0,4,0,30,0.2,4,0.5,0,0,4,-90,-20,0,4,0,0,0,4,0,0,0,4,LeftLeg,-1,0,0,4,90,0,0,4,-1,-0.3,0.3,4,-90,-40,0,4,0,0,0,4,90,40,0,4,Torso,0,0,0,4,-90,0,0,4,0.05,0.2,0.15,8,-0,0,0,4,0,0,0,4,180,0,0,4
end,
})
end)
lbl('INTERWORLD - METAMORPHOSIS')
lbl('was listening to ^^ and animating')
btn('empty reanimate (no animations)', reanimate)
insSet(
btn('stop current script', stopreanimate),
'TextColor3',
c3(0.75, 0, 0)
)
lbl('SETTINGS (REANIMATE TO APPLY)')
local swtc = function(txt, options, onchanged)
local current = 0
local swtcbtn = nil
local btnpressed = function()
current = current + 1
if current > #options then
current = 1
end
local option = options[current]
insSet(swtcbtn, 'Text', txt .. ': ' .. option.text)
onchanged(option.value)
end
swtcbtn = btn('change', btnpressed)
btnpressed()
return swtcbtn
end
swtc('client sided placeholders', {
{ value = true, text = 'yes' },
{ value = false, text = 'no' },
}, function(v)
placeholders = v
end)
swtc('highlight fling targets', {
{ value = true, text = 'yes' },
{ value = false, text = 'no' },
}, function(v)
highlightflingtargets = v
end)
swtc('allow shiftlock', {
{ value = true, text = 'yes' },
{ value = false, text = 'no' },
}, function(v)
allowshiftlock = v
end)
swtc('ctrl click tp', {
{ value = true, text = 'yes' },
{ value = false, text = 'no' },
}, function(v)
ctrltp = v
end)
swtc('click fling', {
{ value = true, text = 'yes' },
{ value = false, text = 'no' },
}, function(v)
clickfling = v
end)
swtc('fling enhancements', {
{ value = 3, text = 'all' },
{ value = 1, text = 'changestate physics' },
{ value = 2, text = 'disable sitting' },
{ value = 0, text = 'none' },
}, function(v)
flingchangestate = v
end)
swtc('respawn tp', {
{ value = 3, text = 'hide body' },
{ value = 0, text = 'stay at spawn' },
{ value = 1, text = 'random tp close' },
{ value = 2, text = 'behind char' },
}, function(v)
respawntp = v
end)
local disguiscripts = nil
swtc('new gui scripts', {
{ value = true, text = 'disable' },
{ value = false, text = 'keep' },
}, function(v)
disguiscripts = v
end)
Connect(insGet(pg, 'DescendantAdded'), function(v)
if c and disguiscripts and IsA(v, 'Script') then --mind Enum.RunContext.Client
insSet(v, 'Disabled', true)
end
end)
swtc('new character scripts', {
{
value = function(v)
if IsA(v, 'Script') then --mind Enum.RunContext.Client
insSet(v, 'Disabled', true)
end
end,
text = 'disable',
},
{ value = false, text = 'keep' },
}, function(v)
discharscripts = v
end)
swtc('breakjoints', {
{ value = 1, text = 'breakjoints+health' },
{ value = 2, text = 'health or breakjoints' },
{ value = 3, text = 'breakjoints' },
}, function(v)
breakjointsmethod = v
end)
swtc('coregui death effect', {
{ value = true, text = 'disable' },
{ value = false, text = 'dont modify' },
}, function(v)
hidedeatheffect = v
end)
swtc('set simulation radius', {
{ value = true, text = 'yes' },
{ value = false, text = 'no' },
}, function(v)
simrad = v
end)
if replicatesignal then
local i11 = i('Frame')
local i12 = i('UIListLayout')
local i13 = i('Frame')
local i14 = i('UIListLayout')
insSet(i11, 'Name', rs())
insSet(i11, 'AnchorPoint', v2(0.5, 0.5))
insSet(i11, 'AutomaticSize', e.AutomaticSize.XY)
insSet(i11, 'BackgroundTransparency', 1)
insSet(i11, 'Position', u2(0.5, 0, 0.5, 0))
insSet(i11, 'Size', u2(1, 0, 0, 0))
insSet(i12, 'Name', rs())
insSet(i12, 'SortOrder', e.SortOrder.LayoutOrder)
insSet(i12, 'Parent', i11)
insSet(i13, 'Name', rs())
insSet(i13, 'AutomaticSize', e.AutomaticSize.Y)
insSet(i13, 'BackgroundTransparency', 1)
insSet(i13, 'Size', u2(0.5, 0, 0, 0))
insSet(i14, 'Name', rs())
insSet(i14, 'FillDirection', e.FillDirection.Horizontal)
insSet(i14, 'SortOrder', e.SortOrder.LayoutOrder)
insSet(i14, 'Parent', i13)
local s = i4
i4 = i11
lbl('Use permadeath?')
lbl('(detectable with no false positives)')
lbl('This executor supports permadeath.')
lbl('permadeath preload method')
insSet(i13, 'Parent', i11)
i4 = i13
btn('No', function()
replicatesignal = nil
Destroy(i11)
lbl('permadeath disabled')
insSet(i4, 'Parent', i3)
pdloadedtime = nil
end)
btn('Yes', function()
Destroy(i11)
lbl('permadeath enabled')
insSet(i4, 'Parent', i3)
replicatesignal(cdsb)
pdloadedtime = osclock() + rst
local lastc = nil
local hdied = function()
if not c then
replicatesignal(cdsb)
pdloadedtime = osclock() + rst
end
end
Connect(GetPropertyChangedSignal(lp, 'Character'), function()
local c = lp.Character
if c and c ~= lastc then
lastc = c
replicatesignal(cdsb)
pdloadedtime = osclock() + rst
while lastc == c do
local h = FindFirstChildOfClass(c, 'Humanoid')
if h then
Connect(insGet(h, 'Died'), hdied)
break
end
Wait(preanimation)
end
end
end)
end)
i4 = s
insSet(i11, 'Parent', i3)
insSet(i4, 'Parent', nil)
else
lbl('permadeath unsupported')
end
if
not pcall(
insSet,
i10,
'Parent',
FindFirstChildOfClass(game, 'CoreGui')
)
then
insSet(i7, 'Text', 'PLAYERGUI MODE')
insSet(i10, 'Parent', pg)
twait(3)
insSet(i7, 'Text', guiTheme.guiTitle)
end
end,
})
local Section = OtherTab:AddSection({
Name = '(OXIDE reanimations)',
})
OtherTab:AddButton({
Name = 'Oxide Reanimation',
Callback = function()
_G.HideCharacter = true
_G.FlingEnabled = true
_G.TransparentRig = true
_G.ToolFling = false -- false = holding, true = fling
_G.AntiFling = false
_G.HatCollide = false
_G.CustomHats = false -- Enable or disable custom rig feature (basically old oxide when false)
_G.CH = {
Torso = {
Name = 'Black',
TextureId = '14251599953',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(0)
),
},
LeftArm = {
Name = 'Accessory (LARM)',
TextureId = '17374768001',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
RightArm = {
Name = 'Accessory (RARM)',
TextureId = '17374768001',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
LeftLeg = {
Name = 'Accessory (LLeg)',
TextureId = '17387586304',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
RightLeg = {
Name = 'Accessory (rightleg)',
TextureId = '17387586304',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
}
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/Nitro-GT/Oxide/refs/heads/main/Loadstring'
)
)()
task.wait(0.5) -- we give it time to load properly
--Script Goes Here!
end,
})
OtherTab:AddButton({
Name = 'Oxide Reanimation Permadeath',
Callback = function()
_G.HideCharacter = true
_G.FlingEnabled = true
_G.TransparentRig = true
_G.ToolFling = false -- false = holding, true = fling
_G.AntiFling = false
_G.CustomHats = false -- Enable or disable custom rig feature (basically old oxide when false)
_G.CH = {
Torso = {
Name = 'Black',
TextureId = '14251599953',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(0)
),
},
LeftArm = {
Name = 'Accessory (LARM)',
TextureId = '17374768001',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
RightArm = {
Name = 'Accessory (RARM)',
TextureId = '17374768001',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
LeftLeg = {
Name = 'Accessory (LLeg)',
TextureId = '17387586304',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
RightLeg = {
Name = 'Accessory (rightleg)',
TextureId = '17387586304',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
}
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/Nitro-GT/Oxide/refs/heads/main/LoadstringPerma'
)
)()
task.wait(0.5) -- we give it time to load properly
--Script Goes Here!
end,
})
OtherTab:AddButton({
Name = 'Krystal Dance V3',
Callback = function()
_G.HideCharacter = true
_G.FlingEnabled = true
_G.TransparentRig = true
_G.ToolFling = false -- false = holding, true = fling
_G.AntiFling = false
_G.HatCollide = false
_G.CustomHats = false -- Enable or disable custom rig feature (basically old oxide when false)
_G.CH = {
Torso = {
Name = 'Black',
TextureId = '14251599953',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(0)
),
},
LeftArm = {
Name = 'Accessory (LARM)',
TextureId = '17374768001',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
RightArm = {
Name = 'Accessory (RARM)',
TextureId = '17374768001',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
LeftLeg = {
Name = 'Accessory (LLeg)',
TextureId = '17387586304',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
RightLeg = {
Name = 'Accessory (rightleg)',
TextureId = '17387586304',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
}
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/Nitro-GT/Oxide/refs/heads/main/Loadstring'
)
)()
task.wait(0.5) -- we give it time to load properly
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/Nitro-GT/OxideReanim/refs/heads/main/KrystalDance3'
)
)()
end,
})
OtherTab:AddButton({
Name = 'Krystal Dance V3 with perma',
Callback = function()
_G.HideCharacter = true
_G.FlingEnabled = true
_G.TransparentRig = true
_G.ToolFling = false -- false = holding, true = fling
_G.AntiFling = false
_G.HatCollide = false
_G.CustomHats = false -- Enable or disable custom rig feature (basically old oxide when false)
_G.CH = {
Torso = {
Name = 'Black',
TextureId = '14251599953',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(0)
),
},
LeftArm = {
Name = 'Accessory (LARM)',
TextureId = '17374768001',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
RightArm = {
Name = 'Accessory (RARM)',
TextureId = '17374768001',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
LeftLeg = {
Name = 'Accessory (LLeg)',
TextureId = '17387586304',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
RightLeg = {
Name = 'Accessory (rightleg)',
TextureId = '17387586304',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
}
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/Nitro-GT/Oxide/refs/heads/main/LoadstringPerma'
)
)()
task.wait(1) -- we give it time to load properly
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/Nitro-GT/OxideReanim/refs/heads/main/KrystalDance3'
)
)()
end,
})
OtherTab:AddButton({
Name = 'Oxide Reanimation Permadeath (2X Scale)',
Callback = function()
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/Nitro-GT/Oxide/refs/heads/main/2xperm'
)
)()
end,
})
OtherTab:AddButton({
Name = 'animation replicator (ONLY REPLICATES TO OTHERS)',
Callback = function()
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/Nitro-GT/Oxide/refs/heads/main/animreplicator'
)
)()
end,
})
OtherTab:AddButton({
Name = 'Ragdoll Script!',
Callback = function()
getgenv().options = { -- SCRIPT OPTIONS
RagdollGravity = 196.2, -- change to any number above 0 (196.2 is default grav)
}
_G.HideCharacter = true
_G.FlingEnabled = true
_G.TransparentRig = true
_G.ToolFling = false -- false = holding, true = fling
_G.AntiFling = false
_G.CustomHats = false -- Enable or disable custom rig feature (basically old oxide when false)
_G.CH = {
Torso = {
Name = 'Black',
TextureId = '14251599953',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(0)
),
},
LeftArm = {
Name = 'Accessory (LARM)',
TextureId = '17374768001',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
RightArm = {
Name = 'Accessory (RARM)',
TextureId = '17374768001',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
LeftLeg = {
Name = 'Accessory (LLeg)',
TextureId = '17387586304',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
RightLeg = {
Name = 'Accessory (rightleg)',
TextureId = '17387586304',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
}
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/Nitro-GT/Oxide/refs/heads/main/genericloadstring'
)
)()
task.wait(0.5) -- we give it time to load properly
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/Nitro-GT/OxideReanim/refs/heads/main/ragdoll'
)
)()
end,
})
OtherTab:AddButton({
Name = 'Oxide Hub Rework',
Callback = function()
_G.HideCharacter = true
_G.FlingEnabled = true
_G.TransparentRig = true
_G.ToolFling = true -- false = holding, true = fling
_G.AntiFling = true
_G.HatCollide = false
_G.CustomHats = false -- Enable or disable custom rig feature (basically old oxide when false)
_G.CH = {
Torso = {
Name = 'Accessory (Guest Torso)',
TextureId = '87928159560963',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(0)
),
},
LeftArm = {
Name = 'Accessory (Guest Left Arm)',
TextureId = '72193962238808',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(0)
),
},
RightArm = {
Name = 'Accessory (Guest Right Arm)',
TextureId = '86835481875891',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(0)
),
},
LeftLeg = {
Name = 'Accessory (LARM)',
TextureId = '17374768001',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
RightLeg = {
Name = 'Accessory (RARM)',
TextureId = '17374768001',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
}
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/Nitro-GT/Oxide/refs/heads/main/OxideHub'
)
)()
end,
})
local Section = OtherTab:AddSection({
Name = 'ONLY VR',
})
OtherTab:AddButton({
Name = 'Nitrous VR 3',
Callback = function()
_G.HeadScale = 3
_G.HeadHat = 'Accessory (BiggestHeadWhite)'
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/Nitro-GT/NitrousVR/main/Loadstring'
)
)()
end,
})
OtherTab:AddButton({
Name = 'CloVR',
Callback = function()
_G.LegacyFootPlant = false -- Enables the old clovr footplant where your torso would float
_G.CustomHats = false -- Enable or disable custom rig feature (basically old oxide when false)
_G.CH = {
Torso = {
Name = 'Accessory (Guest Torso)',
TextureId = '87928159560963',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(0)
),
},
LeftArm = {
Name = 'Accessory (Guest Left Arm)',
TextureId = '72193962238808',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(0)
),
},
RightArm = {
Name = 'Accessory (Guest Right Arm)',
TextureId = '86835481875891',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(0)
),
},
LeftLeg = {
Name = 'Accessory (LARM)',
TextureId = '17374768001',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
RightLeg = {
Name = 'Accessory (RARM)',
TextureId = '17374768001',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
}
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/Nitro-GT/Oxide/refs/heads/main/clovr'
)
)()
end,
})
OtherTab:AddButton({
Name = 'Permadeath CLoVR',
Callback = function()
_G.LegacyFootPlant = false
_G.CustomHats = false -- Enable or disable custom rig feature (basically old oxide when false)
_G.CH = {
Torso = {
Name = 'Accessory (hemi_torso)',
TextureId = '97453109838466',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(0)
),
},
RightArm = {
Name = 'Accessory (hemi_rightarm)',
TextureId = '85395074379680',
Orientation = CFrame.Angles(
math.rad(90),
math.rad(0),
math.rad(180)
),
},
LeftArm = {
Name = 'Accessory (hemi_leftarm)',
TextureId = '136217444573116',
Orientation = CFrame.Angles(
math.rad(90),
math.rad(0),
math.rad(180)
),
},
RightLeg = {
Name = 'Accessory (LARM)',
TextureId = '17374768001',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
LeftLeg = {
Name = 'Accessory (RARM)',
TextureId = '17374768001',
Orientation = CFrame.Angles(
math.rad(0),
math.rad(0),
math.rad(90)
),
},
}
loadstring(
game:HttpGet(
'https://raw.githubusercontent.com/Nitro-GT/Oxide/refs/heads/main/clovrpermadeath'
)
)()
end,
})
local OtherTab = Window:MakeTab({
Name = '(Premium Only)',
Icon = 'rbxassetid://4483345998',
PremiumOnly = false,
})
local Section = OtherTab:AddSection({
Name = 'you have been given Premium. have fun!',
})
-- Create a section for the music controls
local MusicSection = OtherTab:AddSection({
Name = 'SOUNDBOARD',
})
-- Create a sound object for the music player
local musicPlayer = Instance.new('Sound')
musicPlayer.Parent = game.Players.LocalPlayer:WaitForChild('PlayerGui')
-- Set the initial music volume
local musicVolume = 1
-- Define the music data
local musicData = {
['APPLESAUCE'] = '7143872248',
['EPIC'] = '5410085694',
['MISS THE RAGE'] = '9124780123',
['(new) MYSTERIOUS FUNK'] = '139477537381956',
}
-- Function to play music
local function playMusic(name)
local id = musicData[name]
if id then
-- Stop the current music if it's playing
if musicPlayer.IsPlaying then
musicPlayer:Stop()
end
-- Set the music ID and volume, then play the music
musicPlayer.SoundId = 'rbxassetid://' .. id
musicPlayer.Volume = musicVolume
musicPlayer:Play()
end
end
-- Function to stop the music
local function stopMusic()
-- Stop the music if it's playing
if musicPlayer.IsPlaying then
musicPlayer:Stop()
end
end
-- Create a dropdown for selecting music
local musicDropdown = MusicSection:AddDropdown({
Name = 'Select Music',
Default = '',
Options = {
'APPLESAUCE',
'EPIC',
'MISS THE RAGE',
'(new) MYSTERIOUS FUNK',
},
Callback = function(option)
playMusic(option)
end,
})
-- Create a dropdown for adjusting the volume
local volumeDropdown = MusicSection:AddDropdown({
Name = 'Volume',
Default = '1',
Options = { '0.5', '1', '2', '3', '4', '5', '6', '7', '8', '9', '10' },
Callback = function(option)
musicVolume = tonumber(option)
if musicPlayer.SoundId ~= '' then
musicPlayer.Volume = musicVolume
end
end,
})
-- Create a button to stop the music
MusicSection:AddButton({
Name = 'Stop Music',
Callback = stopMusic,
})
local Section = OtherTab:AddSection({
Name = '!Crazy Scripts!',
})
OtherTab:AddButton({
Name = 'sus GUI',
Callback = function()
local player = game.Players.LocalPlayer
local character = player.Character or player.CharacterAdded:Wait()
local isR6 = character:FindFirstChild('Torso') ~= nil
-- Notification Function
local function showNotification(message)
local notificationGui = Instance.new('ScreenGui')
notificationGui.Name = 'NotificationGui'
notificationGui.Parent = game.CoreGui
local notificationFrame = Instance.new('Frame')
notificationFrame.Size = UDim2.new(0, 300, 0, 50)
notificationFrame.Position = UDim2.new(0.5, -150, 1, -60)
notificationFrame.AnchorPoint = Vector2.new(0.5, 1)
notificationFrame.BackgroundColor3 = Color3.fromRGB(60, 60, 255) -- Blue color
notificationFrame.BorderSizePixel = 0
notificationFrame.Parent = notificationGui
local uicorner = Instance.new('UICorner')
uicorner.CornerRadius = UDim.new(0, 10)
uicorner.Parent = notificationFrame
local textLabel = Instance.new('TextLabel')
textLabel.Size = UDim2.new(1, -20, 1, 0)
textLabel.Position = UDim2.new(0, 10, 0, 0)
textLabel.BackgroundTransparency = 1
textLabel.Text = message .. ' | by pyst'
textLabel.TextColor3 = Color3.fromRGB(255, 255, 255)
textLabel.Font = Enum.Font.SourceSansBold
textLabel.TextSize = 18
textLabel.TextXAlignment = Enum.TextXAlignment.Left
textLabel.Parent = notificationFrame
notificationFrame.BackgroundTransparency = 1
textLabel.TextTransparency = 1
game
:GetService('TweenService')
:Create(
notificationFrame,
TweenInfo.new(
0.5,
Enum.EasingStyle.Quint,
Enum.EasingDirection.Out
),
{ BackgroundTransparency = 0 }
)
:Play()
game
:GetService('TweenService')
:Create(
textLabel,
TweenInfo.new(
0.5,
Enum.EasingStyle.Quint,
Enum.EasingDirection.Out
),
{ TextTransparency = 0 }
)
:Play()
task.delay(5, function()
game
:GetService('TweenService')
:Create(
notificationFrame,
TweenInfo.new(
0.5,
Enum.EasingStyle.Quint,
Enum.EasingDirection.In
),
{ BackgroundTransparency = 1 }
)
:Play()
game
:GetService('TweenService')
:Create(
textLabel,
TweenInfo.new(
0.5,
Enum.EasingStyle.Quint,
Enum.EasingDirection.In
),
{ TextTransparency = 1 }
)
:Play()
task.delay(0.5, function()
notificationGui:Destroy()
end)
end)
end
-- Show notification based on rig type
if isR6 then
showNotification('🌟 R6 detected!')
else
showNotification('✨ R15 detected!')
end
-- Create Screen GUI
local gui = Instance.new('ScreenGui')
gui.Name = 'BangGui'
gui.Parent = game.CoreGui
-- Main Frame
local mainFrame = Instance.new('Frame')
mainFrame.Size = UDim2.new(0, 300, 0, 300)
mainFrame.AnchorPoint = Vector2.new(0.5, 0.5)
mainFrame.Position = UDim2.new(0.5, 0, 0.5, 0)
mainFrame.BackgroundColor3 = Color3.fromRGB(80, 80, 255) -- Deep Blue
mainFrame.BorderSizePixel = 0
mainFrame.Parent = gui
local uicorner = Instance.new('UICorner')
uicorner.CornerRadius = UDim.new(0, 20)
uicorner.Parent = mainFrame
-- Title
local title = Instance.new('TextLabel')
title.Size = UDim2.new(1, -60, 0, 30)
title.Position = UDim2.new(0, 10, 0, 0)
title.BackgroundTransparency = 1
title.Text = '🎨 Choose a Script'
title.TextColor3 = Color3.fromRGB(255, 255, 255)
title.Font = Enum.Font.SourceSansBold
title.TextSize = 24
title.TextXAlignment = Enum.TextXAlignment.Left
title.Parent = mainFrame
-- Close Button
local closeButton = Instance.new('TextButton')
closeButton.Size = UDim2.new(0, 30, 0, 30)
closeButton.Position = UDim2.new(1, -40, 0, 0)
closeButton.BackgroundColor3 = Color3.fromRGB(255, 100, 100) -- Red
closeButton.Text = 'X'
closeButton.Font = Enum.Font.SourceSansBold
closeButton.TextSize = 20
closeButton.TextColor3 = Color3.fromRGB(255, 255, 255)
closeButton.Parent = mainFrame
local closeCorner = Instance.new('UICorner')
closeCorner.CornerRadius = UDim.new(0, 10)
closeCorner.Parent = closeButton
closeButton.MouseButton1Click:Connect(function()
gui:Destroy()
end)
-- Minimize Button
local minimizeButton = Instance.new('TextButton')
minimizeButton.Size = UDim2.new(0, 30, 0, 30)
minimizeButton.Position = UDim2.new(1, -80, 0, 0)
minimizeButton.BackgroundColor3 = Color3.fromRGB(255, 200, 0) -- Orange
minimizeButton.Text = '-'
minimizeButton.Font = Enum.Font.SourceSansBold
minimizeButton.TextSize = 20
minimizeButton.TextColor3 = Color3.fromRGB(255, 255, 255)
minimizeButton.Parent = mainFrame
local minimizeCorner = Instance.new('UICorner')
minimizeCorner.CornerRadius = UDim.new(0, 10)
minimizeCorner.Parent = minimizeButton
local minimized = false
minimizeButton.MouseButton1Click:Connect(function()
minimized = not minimized
if minimized then
mainFrame:TweenSize(
UDim2.new(0, 300, 0, 30),
Enum.EasingDirection.In,
Enum.EasingStyle.Quint,
0.5
)
else
mainFrame:TweenSize(
UDim2.new(0, 300, 0, 300),
Enum.EasingDirection.Out,
Enum.EasingStyle.Quint,
0.5
)
end
end)
-- Scrolling Frame
local scrollingFrame = Instance.new('ScrollingFrame')
scrollingFrame.Size = UDim2.new(1, -20, 1, -50)
scrollingFrame.Position = UDim2.new(0, 10, 0, 40)
scrollingFrame.BackgroundTransparency = 1
scrollingFrame.CanvasSize = UDim2.new(0, 0, 0, 300)
scrollingFrame.ScrollBarThickness = 6
scrollingFrame.Parent = mainFrame
local layout = Instance.new('UIListLayout')
layout.Padding = UDim.new(0, 10)
layout.HorizontalAlignment = Enum.HorizontalAlignment.Center
layout.Parent = scrollingFrame
-- Buttons Data
local buttons = {
{
name = '🎯 Bang V2',
r6 = 'https://pastebin.com/raw/aPSHMV6K',
r15 = 'https://pastebin.com/raw/1ePMTt9n',
},
{
name = '🎉 Get Banged',
r6 = 'https://pastebin.com/raw/zHbw7ND1',
r15 = 'https://pastebin.com/raw/7hvcjDnW',
},
{
name = '💥 Suck',
r6 = 'https://pastebin.com/raw/SymCfnAW',
r15 = 'https://pastebin.com/raw/p8yxRfr4',
},
{
name = '🔥 Get Suc',
r6 = 'https://pastebin.com/raw/FPu4e2Qh',
r15 = 'https://pastebin.com/raw/DyPP2tAF',
},
{
name = '⚡ Jerk',
r6 = 'https://pastefy.app/wa3v2Vgm/raw',
r15 = 'https://pastefy.app/YZoglOyJ/raw',
},
}
for _, buttonData in ipairs(buttons) do
local button = Instance.new('TextButton')
button.Size = UDim2.new(0.8, 0, 0, 40)
button.BackgroundColor3 = Color3.fromRGB(
math.random(100, 255),
math.random(100, 255),
math.random(100, 255)
) -- Random colors
button.Text = buttonData.name
button.Font = Enum.Font.SourceSansBold
button.TextSize = 20
button.TextColor3 = Color3.fromRGB(255, 255, 255)
button.Parent = scrollingFrame
local uicorner = Instance.new('UICorner')
uicorner.CornerRadius = UDim.new(0, 10)
uicorner.Parent = button
button.MouseButton1Click:Connect(function()
if isR6 then
loadstring(game:HttpGet(buttonData.r6))()
else
loadstring(game:HttpGet(buttonData.r15))()
end
end)
end
end,
})
OtherTab:AddButton({
Name = 'fly GUI',
Callback = function()
loadstring(
'\108\111\97\100\115\116\114\105\110\103\40\103\97\109\101\58\72\116\116\112\71\101\116\40\40\39\104\116\116\112\115\58\47\47\103\105\115\116\46\103\105\116\104\117\98\117\115\101\114\99\111\110\116\101\110\116\46\99\111\109\47\109\101\111\122\111\110\101\89\84\47\98\102\48\51\55\100\102\102\57\102\48\97\55\48\48\49\55\51\48\52\100\100\100\54\55\102\100\99\100\51\55\48\47\114\97\119\47\101\49\52\101\55\52\102\52\50\53\98\48\54\48\100\102\53\50\51\51\52\51\99\102\51\48\98\55\56\55\48\55\52\101\98\51\99\53\100\50\47\97\114\99\101\117\115\37\50\53\50\48\120\37\50\53\50\48\102\108\121\37\50\53\50\48\50\37\50\53\50\48\111\98\102\108\117\99\97\116\111\114\39\41\44\116\114\117\101\41\41\40\41\10\10'
)()
end,
})
OtherTab:AddButton({
Name = 'Gravity 5',
Callback = function()
game.Workspace.Gravity = 5
end,
})
OtherTab:AddButton({
Name = 'Gravity 10',
Callback = function()
game.Workspace.Gravity = 10
end,
})
OtherTab:AddButton({
Name = 'Gravity 15',
Callback = function()
game.Workspace.Gravity = 15
end,
})
OtherTab:AddButton({
Name = 'Gravity 20',
Callback = function()
game.Workspace.Gravity = 20
end,
})
OtherTab:AddButton({
Name = 'Gravity 25',
Callback = function()
game.Workspace.Gravity = 25
end,
})
OtherTab:AddButton({
Name = 'Gravity 40',
Callback = function()
game.Workspace.Gravity = 45
end,
})
OtherTab:AddButton({
Name = 'Gravity 50',
Callback = function()
game.Workspace.Gravity = 50
end,
})
local Section = OtherTab:AddSection({
Name = 'console typer',
})
OtherTab:AddButton({
Name = 'N- word',
Callback = function()
print('NIGGA')
end,
})
OtherTab:AddButton({
Name = 'sex',
Callback = function()
print('SEX')
end,
})
OtherTab:AddButton({
Name = 'fuck you',
Callback = function()
print('FUCK YOU')
end,
})
OtherTab:AddButton({
Name = 'fuck',
Callback = function()
print('FUCK')
end,
})
OtherTab:AddButton({
Name = 'fuck off',
Callback = function()
print('FUCK OFF')
end,
})
OtherTab:AddButton({
Name = 'what the fuck',
Callback = function()
print('WHAT THE FUCK')
end,
})
OtherTab:AddButton({
Name = 'jerk off',
Callback = function()
print('JERK OFF')
end,
})
OtherTab:AddButton({
Name = 'cum',
Callback = function()
print('CUM')
end,
})
OtherTab:AddButton({
Name = 'im cumming!!!',
Callback = function()
print('IM CUMMING!!!')
end,
})
OtherTab:AddButton({
Name = 'test',
Callback = function()
print('TEST')
end,
})
OtherTab:AddButton({
Name = 'secret mesage',
Callback = function()
print(
'join our discord server (https://discord.gg/jHcEsfEqQa) and subscribe to our channel (https://www.youtube.com/@Franc1xx_Plays)!!!'
)
end,
})
Tab:AddColorpicker({
Name = 'Colorpicker',
Default = Color3.fromRGB(255, 0, 0),
Callback = function(Value)
print(Value)
end,
})No comments yet for this script.